
DOGM128 with Arduino Hardware
#arduino
#DOGM128
#graphics module
#SPI
#3.3V supply
#hardware interface
#display
#microcontroller
#embedded systems
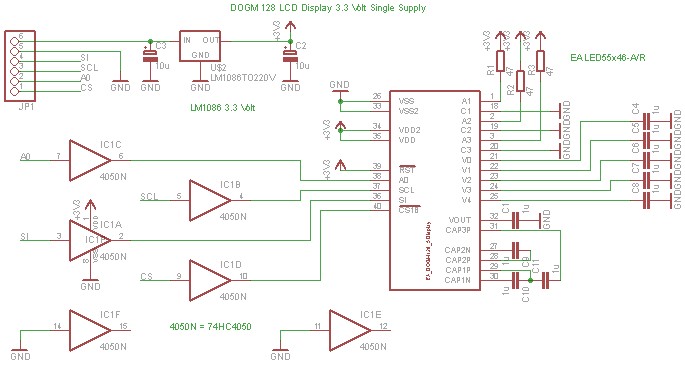
Description: The DOGM graphics module should be connected to the Arduino board as illustrated. Pin 12 (MISO) of the Arduino board must remain unused. Furthermore, the DOGM graphics module requires an address line (A0), which can be connected to any output port. The schematic provided demonstrates the usage of the DOGM graphics module with a 3.3-volt supply. Level translation from 5 volts to 3.3 volts is accomplished using the HC4050 integrated circuit.
The DOGM graphics module is a versatile display component that facilitates the visualization of data and graphics in embedded systems. It operates at a supply voltage of 3.3 volts, which is essential for compatibility with various microcontroller platforms, including the Arduino. The connection configuration is crucial for ensuring proper communication between the module and the Arduino.
In the provided schematic, the DOGM graphics module is interfaced with the Arduino board. It is important to note that Pin 12 (MISO) on the Arduino should not be utilized for this connection, as it is designated for the Master In Slave Out function in SPI communication, which may interfere with the operation of the graphics module. Instead, the module requires an address line (A0) that can be connected to any available output pin on the Arduino. This flexibility allows for customization of the pin configuration based on the specific requirements of the project.
To facilitate the operation of the DOGM graphics module, the schematic also includes an HC4050 integrated circuit. This component serves as a level shifter, enabling the safe translation of voltage levels from 5 volts, which is commonly used in Arduino systems, down to 3.3 volts, suitable for the DOGM module. The HC4050 is a hex buffer/driver that can convert high logic levels (5V) to low logic levels (3.3V) without signal degradation, ensuring reliable communication between the Arduino and the graphics module.
In summary, the proper configuration and connection of the DOGM graphics module with the Arduino, alongside the implementation of the HC4050 for level shifting, are essential for achieving optimal performance and functionality in embedded applications. The schematic serves as a useful guide for engineers and hobbyists alike, enabling them to effectively integrate the DOGM graphics module into their projects.The Dogm-graphics-module should be connected to the Arduino board as shown below. Pin 12 (MISO) of the Arduino board must not be used. Additionally the Dogm-graphics-module requires an addess line (A0) which can be connected to any output port. The following schematic shows the use of the dogm-graphics-module with a 3. 3 volt supply. The level tran slation (5 volt to 3. 3 volt) is done by the HC4050 integrated circuit.
The DOGM graphics module is a versatile display component that facilitates the visualization of data and graphics in embedded systems. It operates at a supply voltage of 3.3 volts, which is essential for compatibility with various microcontroller platforms, including the Arduino. The connection configuration is crucial for ensuring proper communication between the module and the Arduino.
In the provided schematic, the DOGM graphics module is interfaced with the Arduino board. It is important to note that Pin 12 (MISO) on the Arduino should not be utilized for this connection, as it is designated for the Master In Slave Out function in SPI communication, which may interfere with the operation of the graphics module. Instead, the module requires an address line (A0) that can be connected to any available output pin on the Arduino. This flexibility allows for customization of the pin configuration based on the specific requirements of the project.
To facilitate the operation of the DOGM graphics module, the schematic also includes an HC4050 integrated circuit. This component serves as a level shifter, enabling the safe translation of voltage levels from 5 volts, which is commonly used in Arduino systems, down to 3.3 volts, suitable for the DOGM module. The HC4050 is a hex buffer/driver that can convert high logic levels (5V) to low logic levels (3.3V) without signal degradation, ensuring reliable communication between the Arduino and the graphics module.
In summary, the proper configuration and connection of the DOGM graphics module with the Arduino, alongside the implementation of the HC4050 for level shifting, are essential for achieving optimal performance and functionality in embedded applications. The schematic serves as a useful guide for engineers and hobbyists alike, enabling them to effectively integrate the DOGM graphics module into their projects.The Dogm-graphics-module should be connected to the Arduino board as shown below. Pin 12 (MISO) of the Arduino board must not be used. Additionally the Dogm-graphics-module requires an addess line (A0) which can be connected to any output port. The following schematic shows the use of the dogm-graphics-module with a 3. 3 volt supply. The level tran slation (5 volt to 3. 3 volt) is done by the HC4050 integrated circuit.
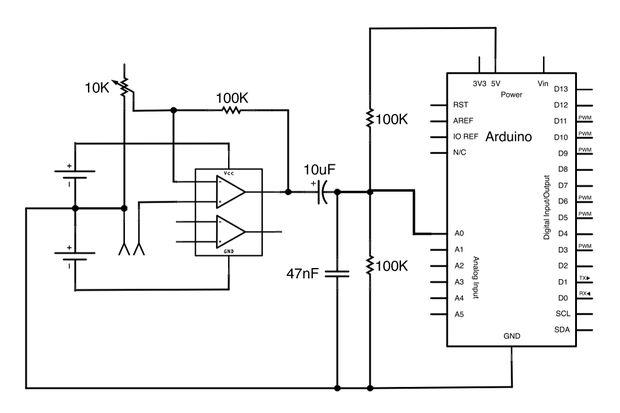
Arduino Vocal Effects Box
This Arduino-powered vocal effects box pitch shifts and distorts incoming audio signals to produce a wide variety of vocal effects. This project serves as an experiment with real-time digital signal processing using Arduino. It samples an incoming microphone signal at...
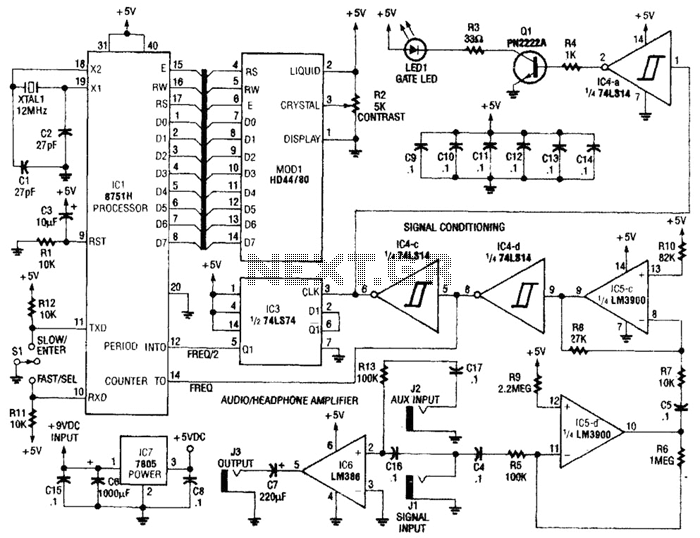
Perfect Pitch Circuit
Perfect Pitch, which is based on the 8751 microprocessor, is an affordable and straightforward instrument tuner and frequency counter that features a built-in headphone amplifier and a visual metronome. Perfect Pitch converts the audio signal from an instrument into a...
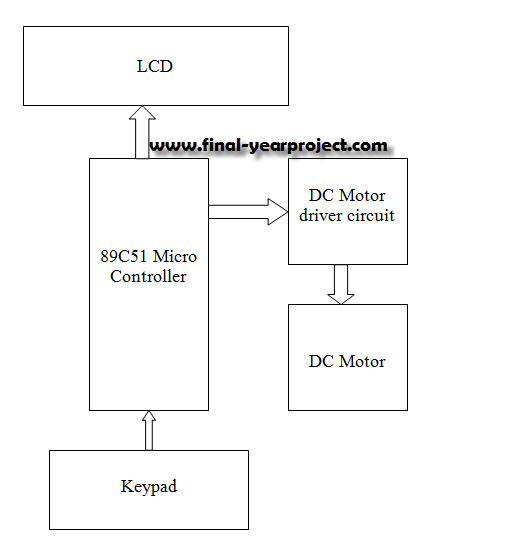
Speed Control of DC Motor using Microcontroller by using PWM ECE Project
This report details an electronic project focused on the speed control of a DC motor using a microcontroller and PWM (Pulse Width Modulation). The system integrates a microcontroller with an LCD, keypad, and a DC motor driver. The microcontroller generates...
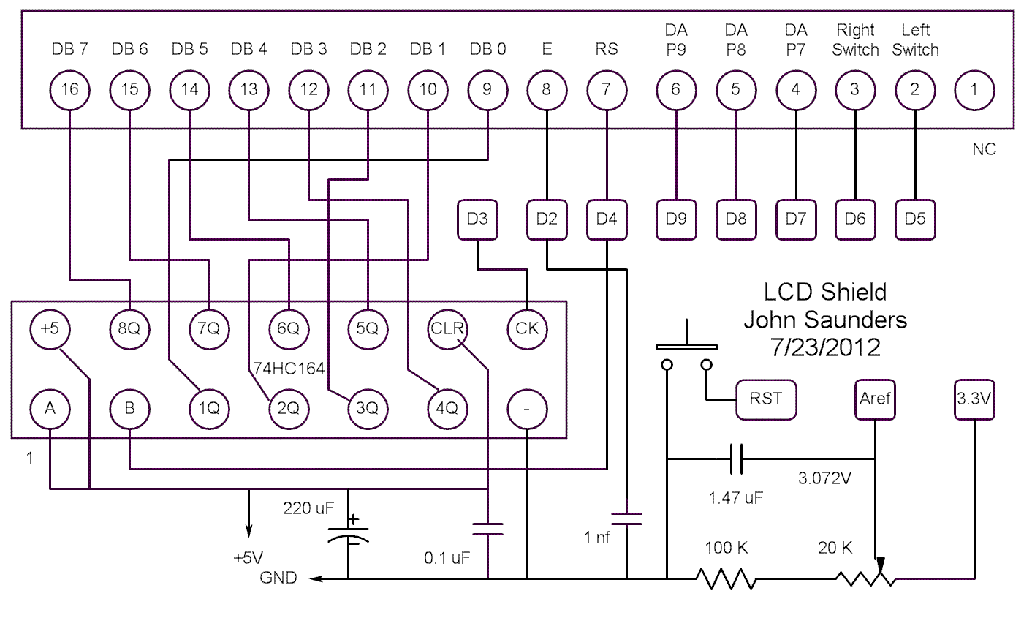
Ardurino Logger
The switches and LEDs are mounted on the same front panel as the display, while the "D" connector is located at the rear. The two switches are momentary switches that activate downwards but latch upwards. Assorted components, such as single...
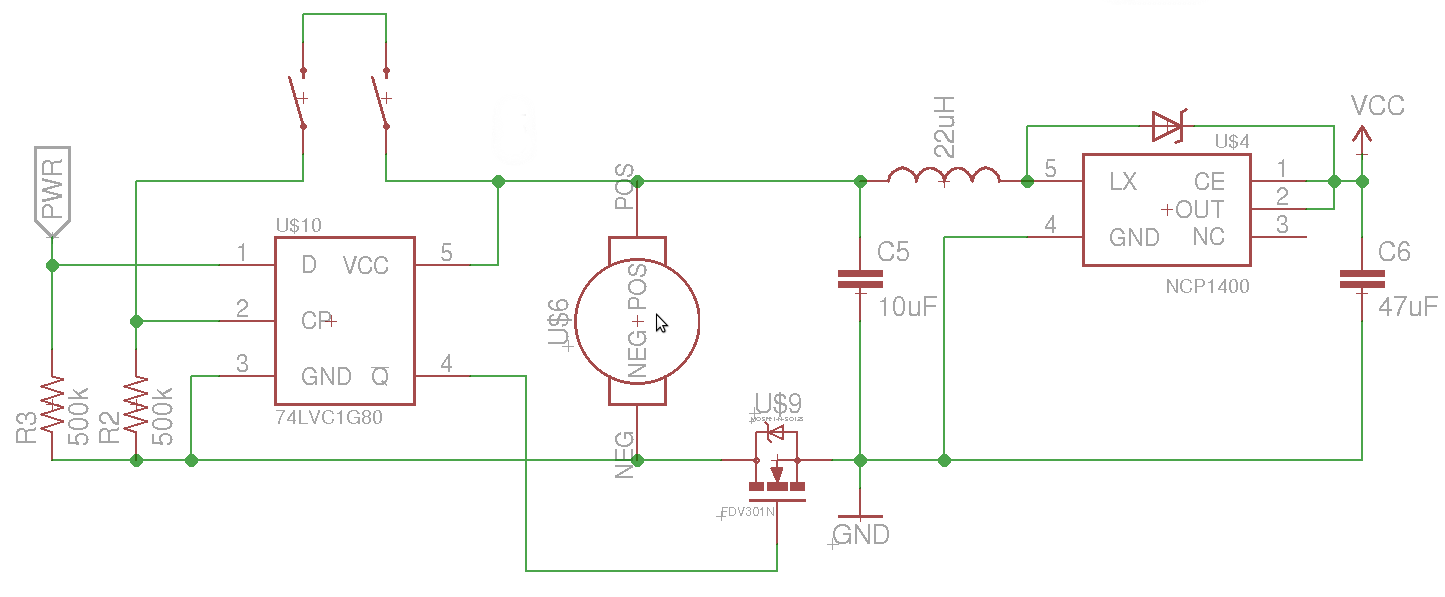
mosfet Turning a microcontroller on with a flip flop
The objective is to control the power to a load, specifically an 8051-based microcontroller (uC), using two switches. When the uC is powered on, it sets the PWR pin high. Upon pressing the switches again, pin 4 of the flip-flop...
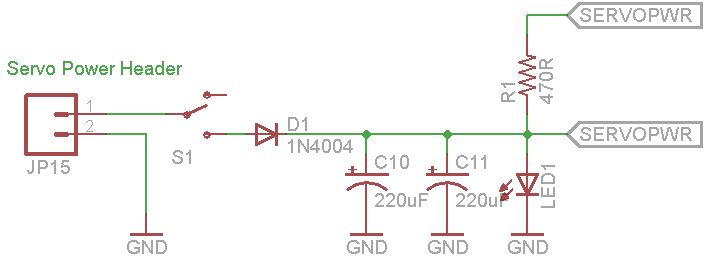
Serial Servo Controller with Arduino
This document explains how to utilize an Arduino to control up to 12 servos simultaneously with minimal jitter. A straightforward serial interface allows for the control of the position of these 12 servo channels. Additionally, it is possible to save...
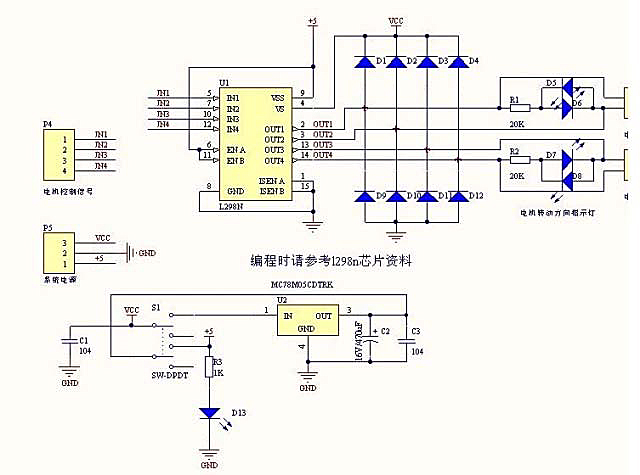
Motor Drivers
Arduino can drive various types of motors. However, the low-power signals from Arduino must control high-power circuits to operate the motors effectively. This document will provide examples of how Arduino can control different motor types and sizes. A motor driver...
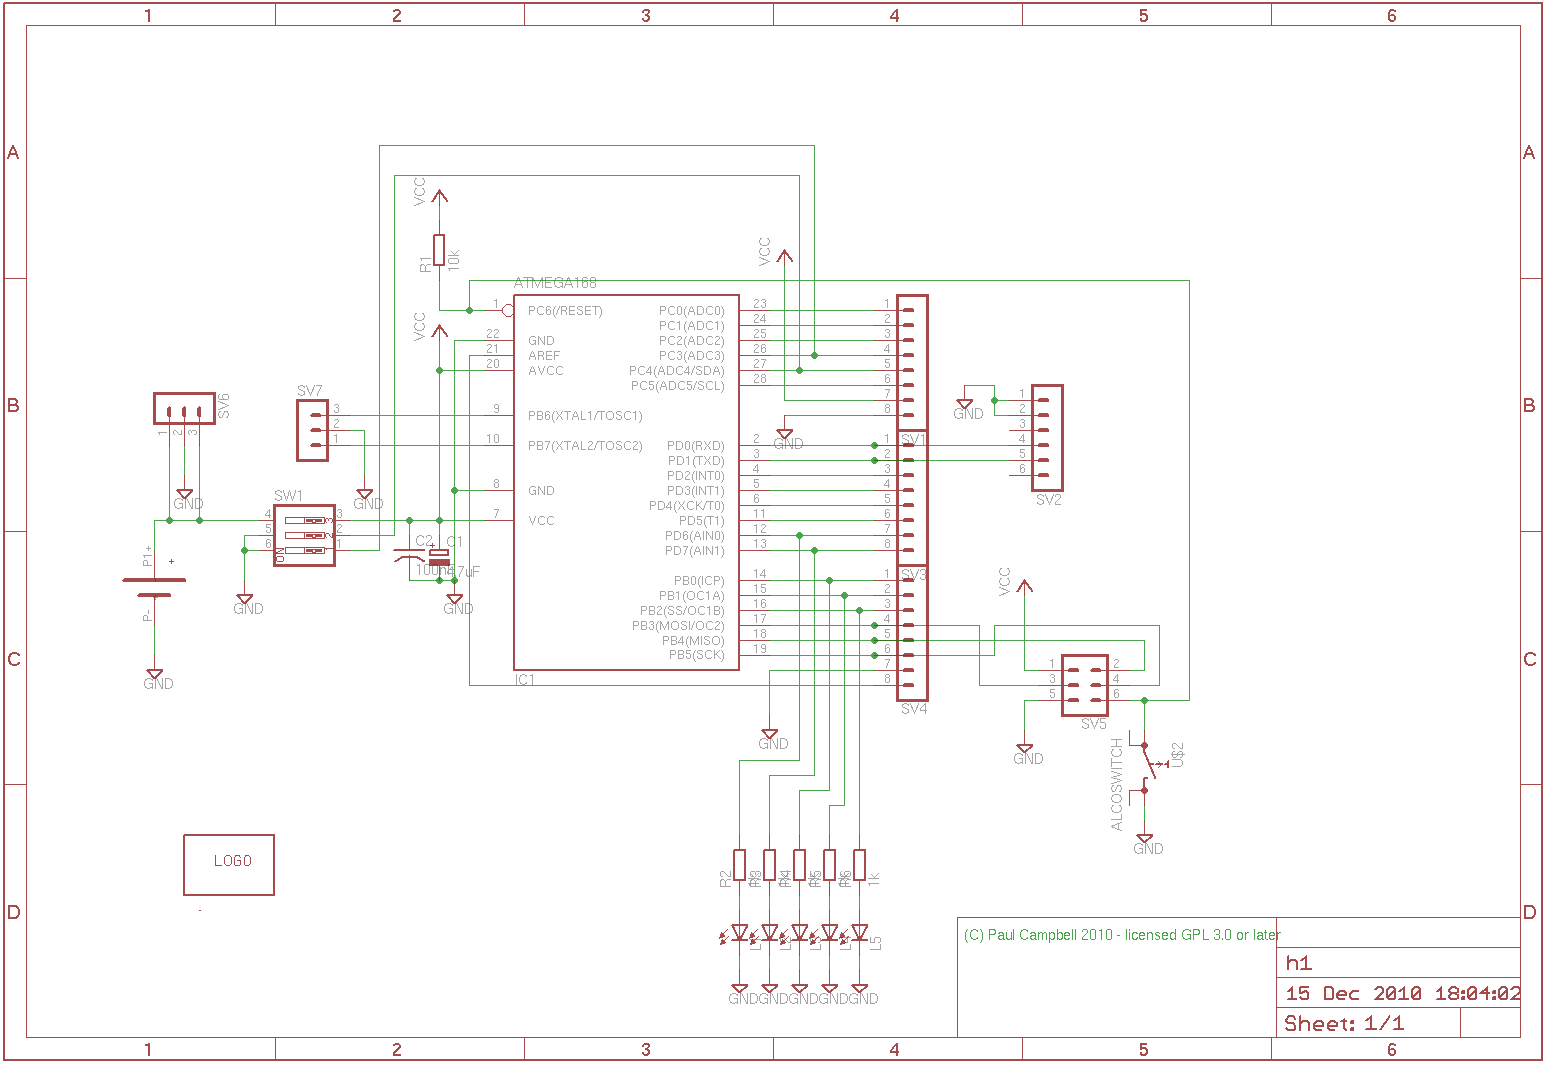
DSpace badge board build Instructions
This project is designed to assist in a basic course where students create a simple AVR/Arduino-based badge. It serves as a beginner's soldering project, resulting in a small object with blinking lights that can be worn around the neck using...
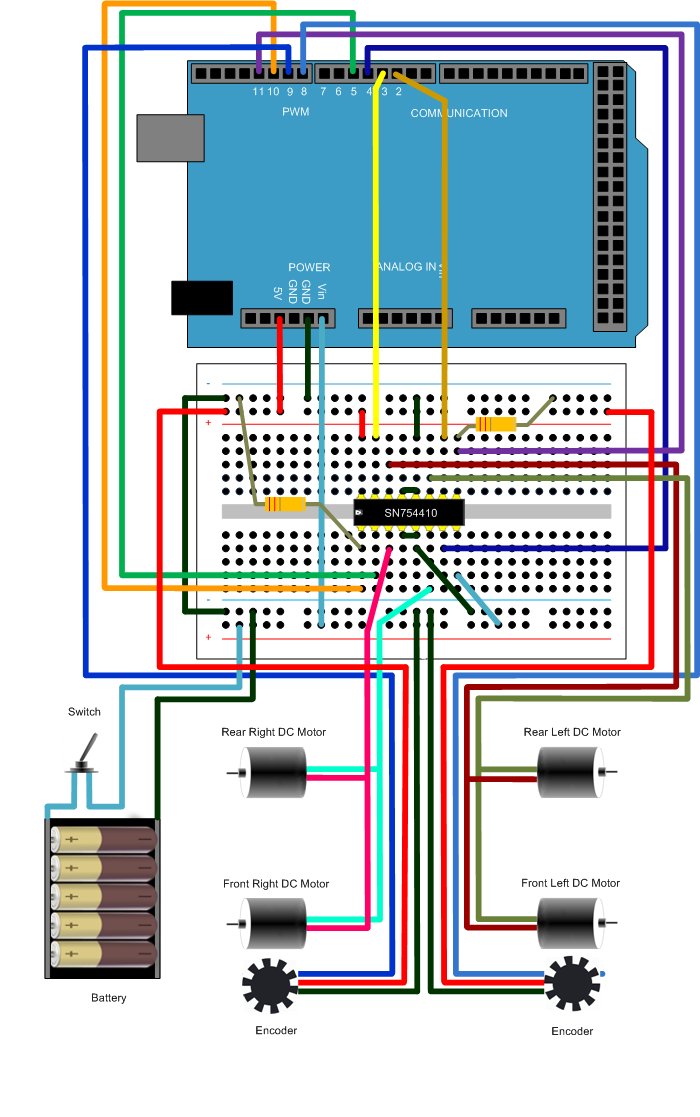
Arduino Drive with PID Control
File exchange, MATLAB Answers, newsgroup access, links, and blogs for the MATLAB and Simulink user community.
The MATLAB and Simulink user community is supported through various platforms that facilitate knowledge sharing and collaboration among users. The File Exchange feature allows users...