
Accident Prevention and Security System for Automobiles
#remote control
#GSM
#CDMA
#land rover
#cell phone
#security system
#accident prevention
#military application
#wireless control
#automobile
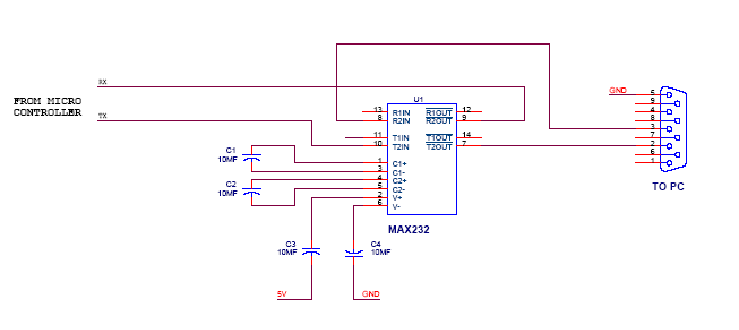
Description: This is a remote-controlled land rover that can be operated using a cell phone. This allows the user to move the land rover by sending various commands from their device. The rover can be controlled from virtually anywhere in the world, provided there is GSM or CDMA network coverage. The concept is inspired by military applications where such land rovers operate as Unmanned Guided Vehicles (UGVs) for tasks such as surveillance, mine detection, and bomb disposal. In these applications, the movements of the land rover can be managed from a safe distance, as there is effectively no limit on the operational range. A simple application has been developed in which the land rover can move forward, backward, and turn left or right based on commands received from any cell phone. However, this platform can be expanded to create more complex applications. The land rover is equipped with four wheels attached to a chassis made of metal, such as iron. The shafts of two DC motors (with a speed of around 150 RPM or higher) are directly linked to the rear wheels. When both motors rotate clockwise, the land rover moves forward; when they rotate counterclockwise, it moves backward. To turn left or right, one of the DC motors is activated to rotate in the appropriate direction. The rover can also execute forward-left, forward-right, backward-left, and backward-right turns by controlling the rotation of either motor accordingly. For instance, if the left motor rotates clockwise, the rover will turn forward-right, while a counterclockwise rotation will result in a backward-right turn, and the same logic applies to the right motor.
The remote-controlled land rover utilizes a mobile application interface that communicates with the rover via a GSM or CDMA network. The mobile app sends control signals to a microcontroller embedded within the rover, which interprets the commands and drives the motors accordingly. The microcontroller could be an Arduino, Raspberry Pi, or any suitable embedded system capable of handling the communication and motor control tasks.
The chassis design is critical for stability and durability, especially when navigating various terrains. The choice of materials for the chassis should consider weight, strength, and resistance to environmental factors. The four-wheel drive system ensures better traction, allowing the rover to maneuver over obstacles with ease.
In terms of power supply, the land rover typically operates on a rechargeable battery pack, providing sufficient voltage and current to the DC motors and the onboard electronics. A power management circuit may be implemented to monitor battery levels and optimize power usage, ensuring extended operational time.
Safety features can also be integrated into the design, such as an emergency stop mechanism that can be activated through the mobile application. This feature is essential for preventing accidents or damage to the rover in case of communication loss or unexpected behavior.
Overall, this remote-controlled land rover represents a versatile platform that can be adapted for various applications beyond its initial design, including educational projects, hobbyist experiments, and even more advanced military or industrial uses, depending on the specific requirements of the task at hand.This is also remote controlled land rover but as a remote control one can use his cell phone. That means he can move the land rover by sending different commands from his cell phone. Not only that, he can control it from anywhere in the world (of course where GSM / CDMA network is available). This concept is taken from military application where such land rover works as Unmanned Guided vehicle (UGV) for spy operations, mine diffuser, bomb detector etc. in such application the movements of land rover can be controlled from very far remote and safe place (as there is practically no limitation on operating range) Here I have develop very simple application in which the land rover moves forward, backward and takes left or right turn as per commands given from any cell phone but one can develop any interesting application over this platform like given above.
As shown in above figure four wheels are attached with chassis made up of any metal (like iron). Shaft of two DC motors (around 150 RPM or more)are directly coupled with real wheels. So as both motors rotate CW, the land rover moves forward. And as both motors rotateCCW, it will move backward. to turn it left right DC motor rotates and to turn it right left DC motor rotates. Also it will take forward-left & forward-right turn as well as backward-left & backward-right turn if required. For that, either of the motors (left or right) is rotated CW or CCW. For example if left motor rotates CW, land rover will take forward-right turn and if it rotates CCW then backward-right turn.
Similarly for right DC motor.
The remote-controlled land rover utilizes a mobile application interface that communicates with the rover via a GSM or CDMA network. The mobile app sends control signals to a microcontroller embedded within the rover, which interprets the commands and drives the motors accordingly. The microcontroller could be an Arduino, Raspberry Pi, or any suitable embedded system capable of handling the communication and motor control tasks.
The chassis design is critical for stability and durability, especially when navigating various terrains. The choice of materials for the chassis should consider weight, strength, and resistance to environmental factors. The four-wheel drive system ensures better traction, allowing the rover to maneuver over obstacles with ease.
In terms of power supply, the land rover typically operates on a rechargeable battery pack, providing sufficient voltage and current to the DC motors and the onboard electronics. A power management circuit may be implemented to monitor battery levels and optimize power usage, ensuring extended operational time.
Safety features can also be integrated into the design, such as an emergency stop mechanism that can be activated through the mobile application. This feature is essential for preventing accidents or damage to the rover in case of communication loss or unexpected behavior.
Overall, this remote-controlled land rover represents a versatile platform that can be adapted for various applications beyond its initial design, including educational projects, hobbyist experiments, and even more advanced military or industrial uses, depending on the specific requirements of the task at hand.This is also remote controlled land rover but as a remote control one can use his cell phone. That means he can move the land rover by sending different commands from his cell phone. Not only that, he can control it from anywhere in the world (of course where GSM / CDMA network is available). This concept is taken from military application where such land rover works as Unmanned Guided vehicle (UGV) for spy operations, mine diffuser, bomb detector etc. in such application the movements of land rover can be controlled from very far remote and safe place (as there is practically no limitation on operating range) Here I have develop very simple application in which the land rover moves forward, backward and takes left or right turn as per commands given from any cell phone but one can develop any interesting application over this platform like given above.
As shown in above figure four wheels are attached with chassis made up of any metal (like iron). Shaft of two DC motors (around 150 RPM or more)are directly coupled with real wheels. So as both motors rotate CW, the land rover moves forward. And as both motors rotateCCW, it will move backward. to turn it left right DC motor rotates and to turn it right left DC motor rotates. Also it will take forward-left & forward-right turn as well as backward-left & backward-right turn if required. For that, either of the motors (left or right) is rotated CW or CCW. For example if left motor rotates CW, land rover will take forward-right turn and if it rotates CCW then backward-right turn.
Similarly for right DC motor.
Inexpensive Remote Watering System
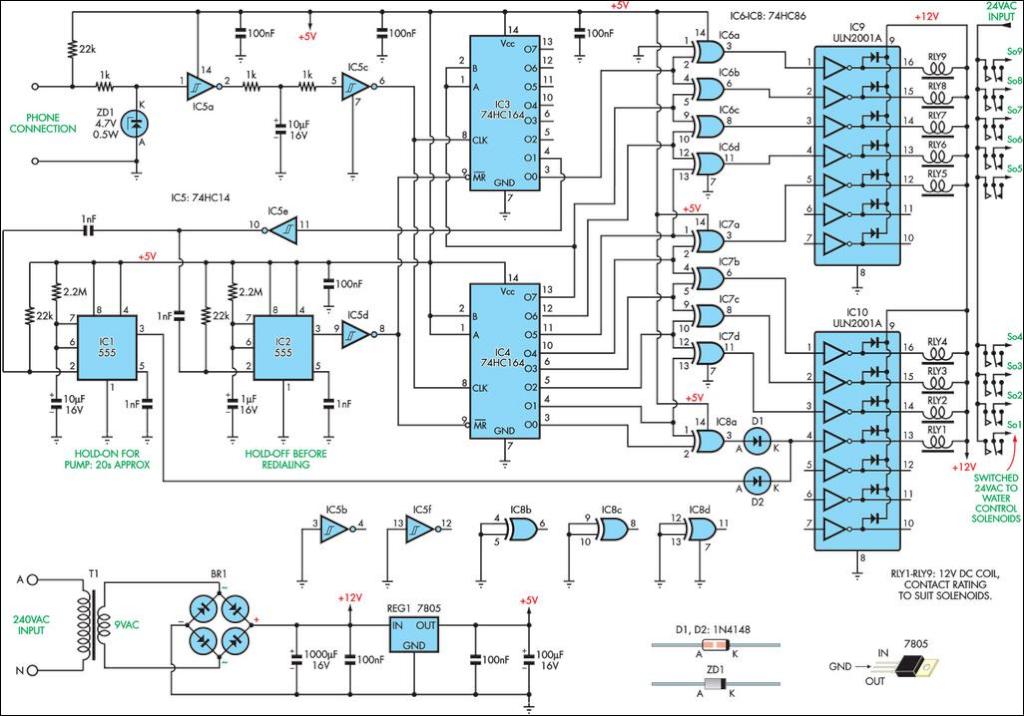
This remotely controlled watering system is both inexpensive and easy to expand. It is designed to operate in conjunction with a conventional watering timer.
The remotely controlled watering system is an innovative solution for automated irrigation, allowing users to manage watering...
gsm gps based vehicle theft control
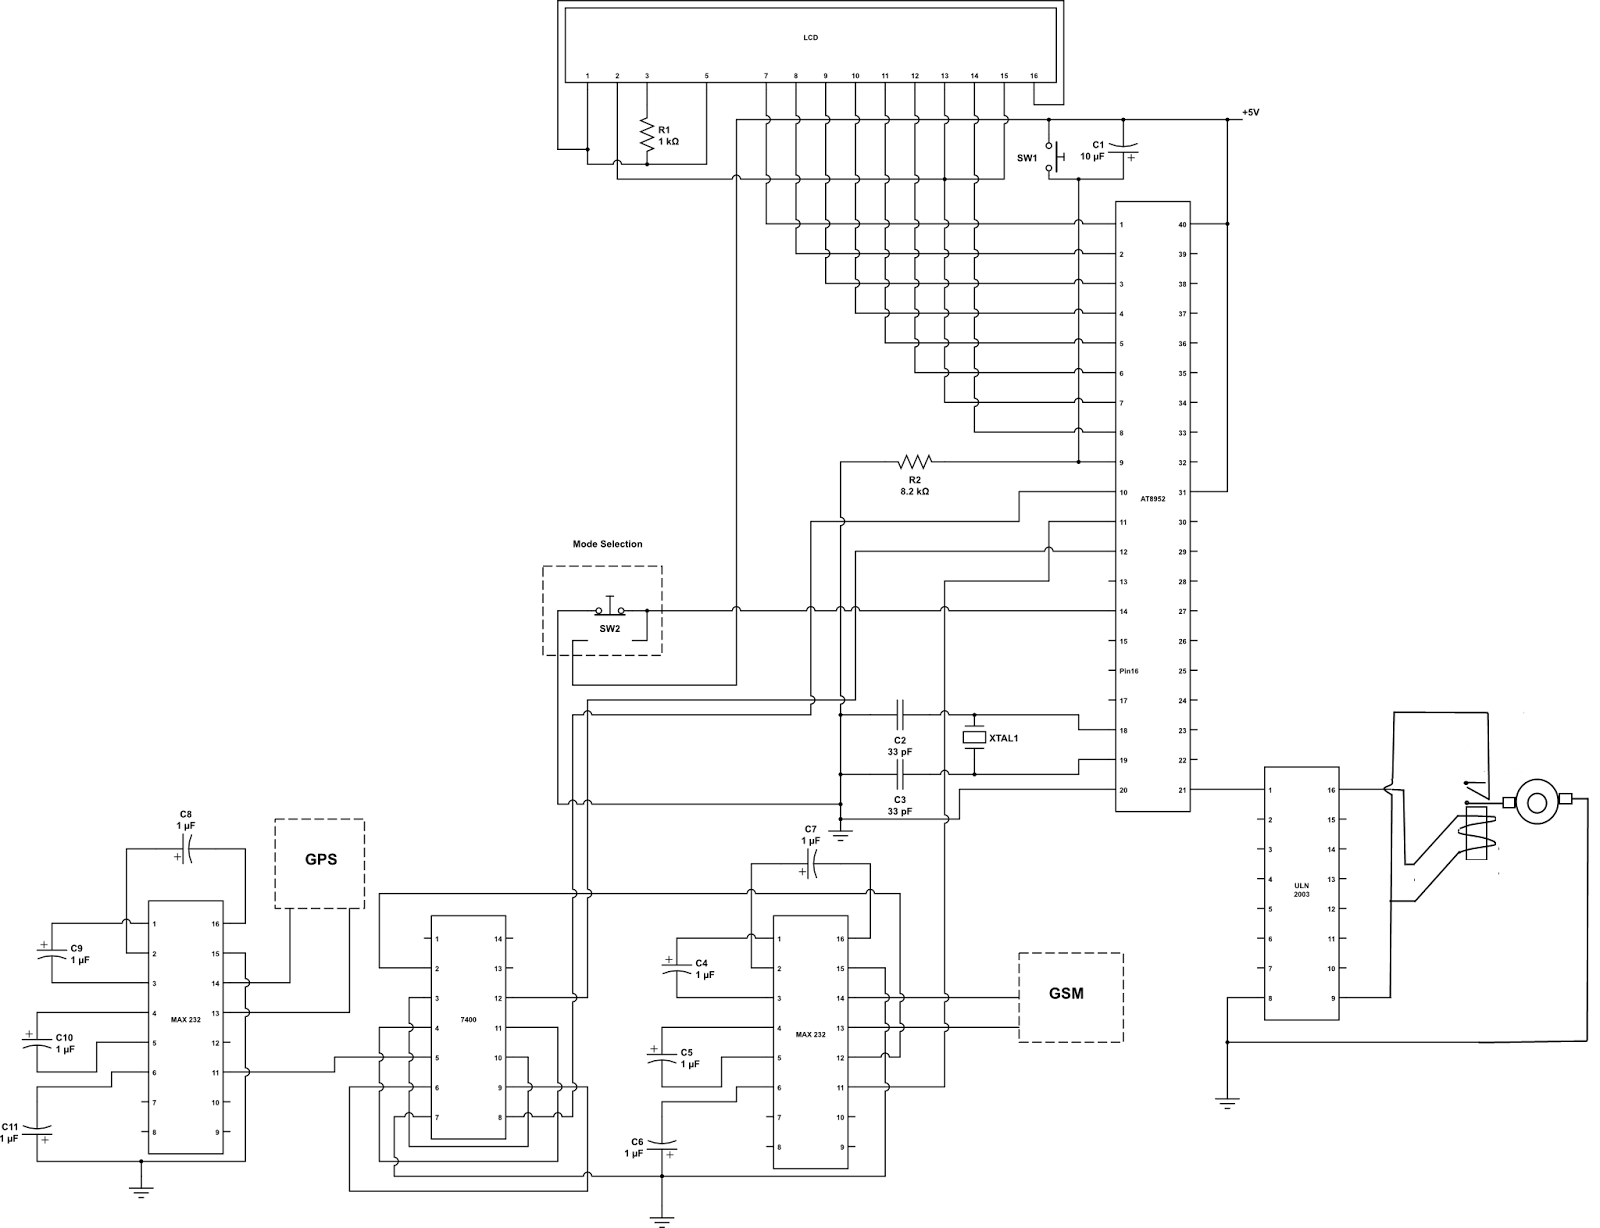
This project focuses on the design and development of a theft control system for automobiles, aimed at preventing and controlling vehicle theft. The system utilizes an embedded design based on GSM and GPS technology. It is installed within the vehicle...
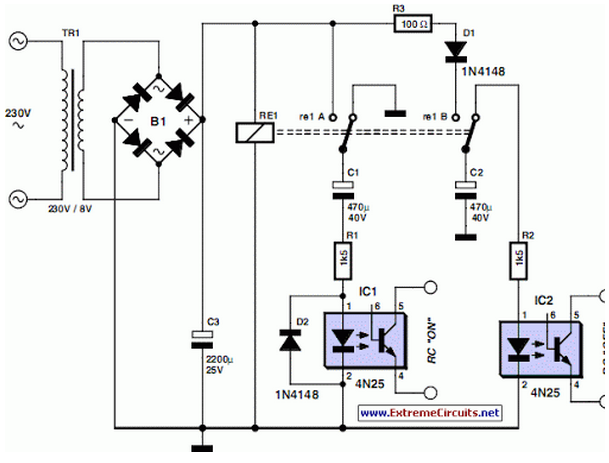
Remote Control Mains Switch
Remote Control Mains Switch
The remote control mains switch is a device designed to control the power supply to electrical appliances from a distance, typically utilizing a wireless remote control. This switch can be integrated into various applications where remote operation...
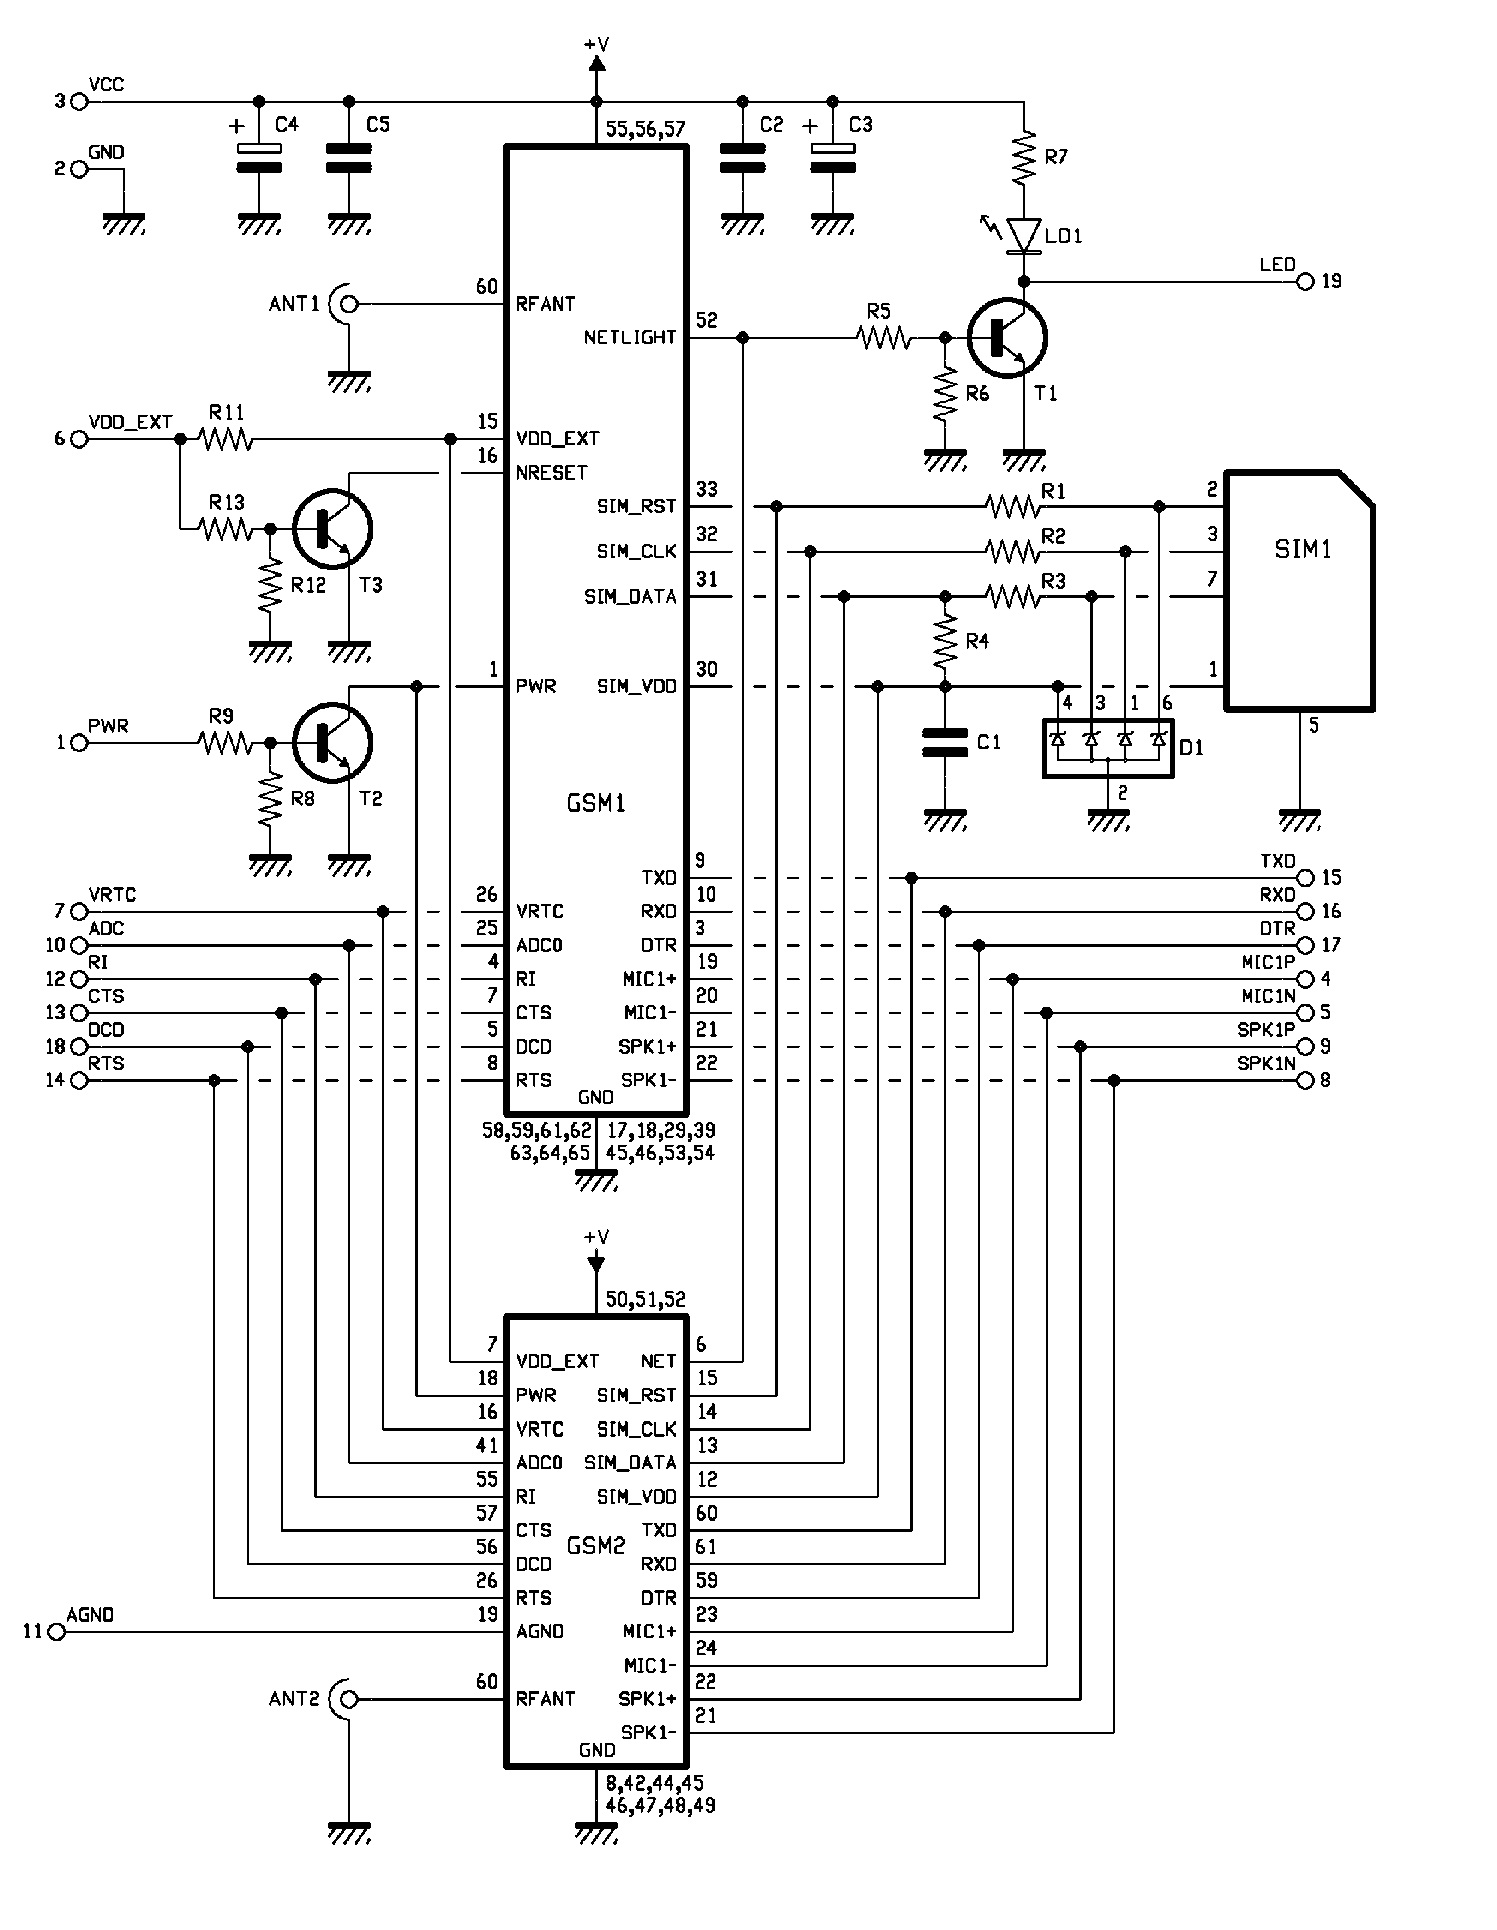
GSM Remote Control Module
This GSM mobile is utilized for remote control applications, such as gate control and temperature management. The term "module" is used because, unlike previous remote control projects, the mobile phone is not directly mounted on a printed circuit board (PCB)....
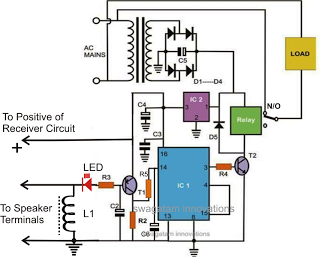
how to make remote control circuit from
The proposed remote control circuit can be utilized to control any electrical device within a range of 100 meters. This concept involves modifying an existing remote bell unit circuit, making the process straightforward. However, the construction aspect necessitates electronic assembly...
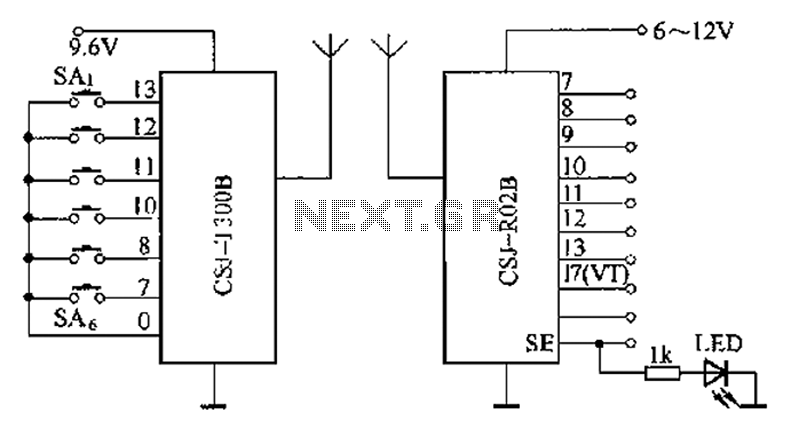
Remote schematic CSJ-T300B with CSJ-R02B composition
The CSJ-T300B/CSJ-R02B is an enhanced digital encoding and decoding circuit developed based on the CSJ-T300A/CSJ-R02A. It forms a remote control circuit that includes the CSJ-T300B and CSJ-R02B components, as illustrated below.
The CSJ-T300B/CSJ-R02B circuit architecture is designed to facilitate improved digital...

Atari Joystick Wired Remote Control for Robots
The simplest solution for implementing joystick control for a robot is to program the actions in software on a microcontroller. However, many users prefer off-the-shelf components, thus this circuit is designed using diodes, resistors, transistors, and a FAN8200 motor driver...
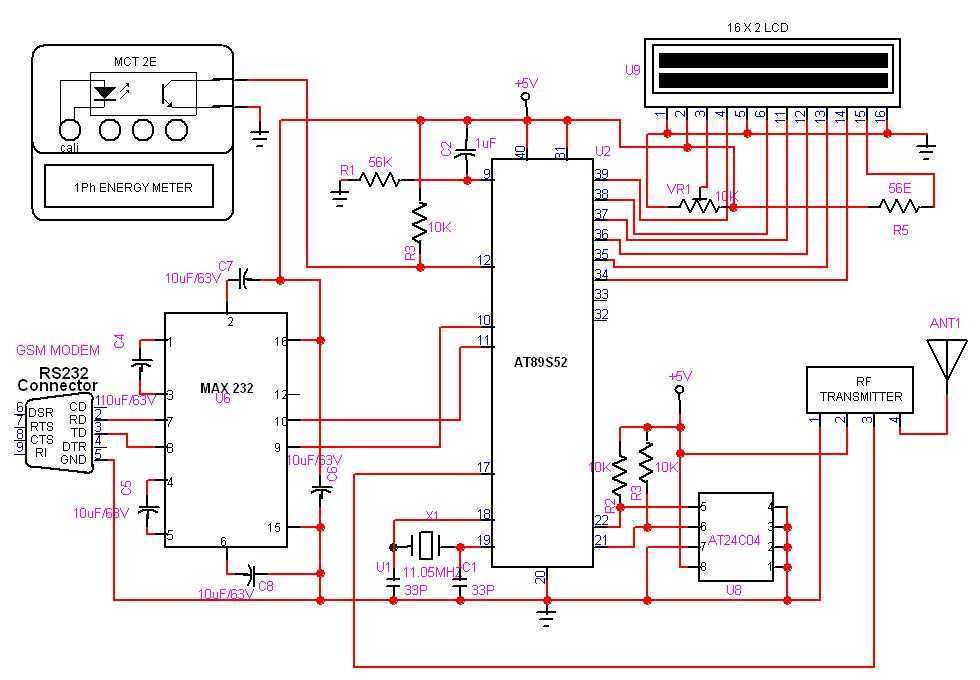
GSM Automatic Meter Reading
GSM based Automatic meter reading, or AMR, is the technology of automatically collecting data from energy meter and transferring that data to a central database for billing and/or analyzing. The Transmitter is connected to the meter and it counts the...
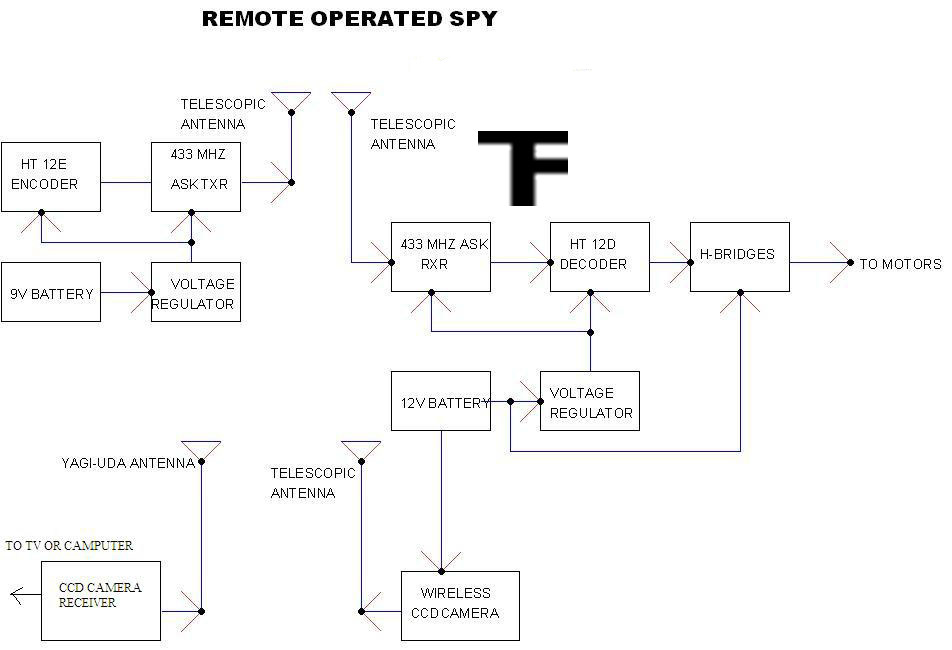
remote operated spy robot circuit
A robot that operates when you send messages through your phone. Your mobile device serves as the remote controller for the robot. This means that if the robot is in London and you are in Mumbai, you can still control...