
Distance measurement system using PING Ultrasonic Range Finder
#ultrasonic
#distance measurement
#sensor
#LCD display
#PING
#Parallax
#digital measurement
#range finder
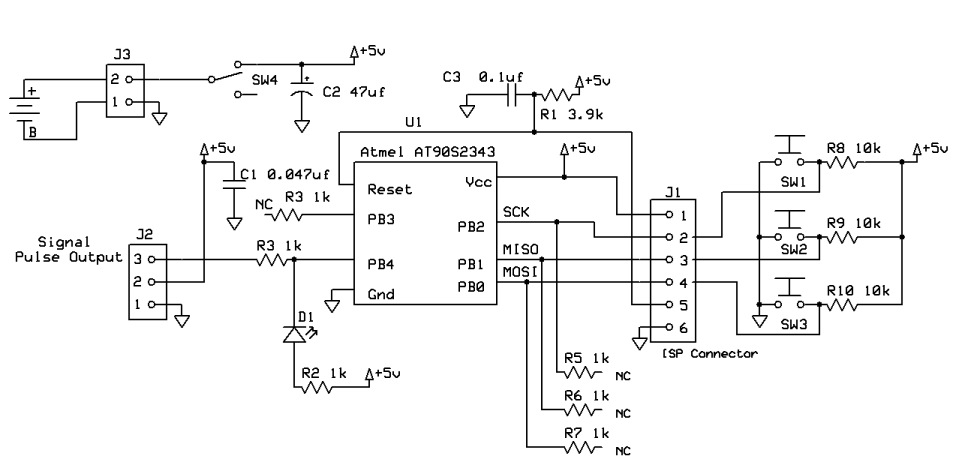
Description: A PING Ultrasonic Range Finder is designed to create a system capable of detecting and measuring the distance (in millimeters) to the nearest object in front of the sensor. It functions similarly to a digital measuring tape; the user points the sensor at an object, presses a read button, and the LCD displays the distance to that object in millimeters. The PING ultrasonic range finder is an easy-to-use sensor from Parallax. It can effectively detect objects at distances ranging from 2 cm to 3 m. The PING sensor operates by transmitting an ultrasonic burst and generating an output pulse that corresponds to the time taken for the echo of the burst to return to the sensor. By measuring the width of the echo pulse, the distance to the target can be calculated easily. The circuit for this system is relatively simple. A PIC16F876A microcontroller serves as the main controller. To operate the entire system, a power section is required, which includes an on/off switch, a power regulator, a diode for reverse polarity protection, and several capacitors. Additionally, basic components are necessary to support the microcontroller's operation, such as a crystal oscillator to generate the clock signal, an active low push button for the master reset, a programming port, and additional capacitors. For this project, a push button is needed to initiate the read command, and an LCD is used to display the output, which is the measured distance. The connections for the PING Ultrasonic sensor are straightforward: the ground pin connects to the common ground of the circuit, the 5V pin connects to the circuit's VDD, and the signal pin connects to one of the I/O pins of the microcontroller.
The PING Ultrasonic Range Finder circuit can be broken down into several key components and their interconnections. The PIC16F876A microcontroller serves as the central processing unit, executing the necessary algorithms to control the ultrasonic sensor and process the distance measurements. The microcontroller requires a stable power supply, which is provided by a voltage regulator that steps down the input voltage to the required 5V. The reverse polarity protection diode is essential to prevent damage to the circuit in case of incorrect power supply connections.
The ultrasonic sensor emits a high-frequency sound wave and listens for the echo that returns after bouncing off an object. The time taken for the echo to return is measured by the microcontroller, which calculates the distance based on the speed of sound. The formula used for calculating distance is Distance = (Time × Speed of Sound) / 2, where the speed of sound in air is approximately 343 meters per second.
The microcontroller is connected to an LCD display, which presents the calculated distance in a user-friendly format. The LCD is interfaced using a suitable communication protocol (often 4-bit or 8-bit mode), allowing the microcontroller to send commands and data to the display. A push button is included to initiate the measurement process, providing an interactive user experience. When pressed, the microcontroller triggers the ultrasonic sensor to emit a burst, waits for the echo, and subsequently processes the data to update the LCD with the distance measurement.
Overall, the PING Ultrasonic Range Finder circuit is a practical and efficient solution for distance measurement applications, combining simplicity and effectiveness in its design.A PING Ultrasonic Range Finder to build up a system which is capable of detect and measure the distance (in mm unit) of the closest object in front of the sensor. It is like a digital measuring tape where you point the sensor to an object, press the read button and the LCD will display the distance of the object in millimeter unit.
The PING) ultrasonic range finder is an easy to used sensor from Parallax. It can nicely detect the object in front with the distance from 2cm to 3m. The PING) sensor works by transmitting an ultrasonic burst and providing an output pulse that corresponds to the time required for the burst echo to return to the sensor. By measuring the echo pulse width, the distance to target can easily be calculated. The circuit for the system is quite simple. I am using PIC16F876A as the main controller. As usual, to operate the whole system, you need the power part which consist of on/off switch, power regulator, diode for wrong polarity protection and some capacitors.
You also need the basic components to support the operation of microcontroller like the crystal to generate clock, an active low push button for the master reset, programming port and some capacitors. For this project, I need to have a push button to input start read command and a LCD to display the output which is the distance value.
The connection for the Ping Ultrasonic sensor is also simple, the ground pin connect to the common ground of the circuit, the 5v connect to the circuit`s vdd and at last the signal pin connect to one of the I/O pin of the microcontroller.
The PING Ultrasonic Range Finder circuit can be broken down into several key components and their interconnections. The PIC16F876A microcontroller serves as the central processing unit, executing the necessary algorithms to control the ultrasonic sensor and process the distance measurements. The microcontroller requires a stable power supply, which is provided by a voltage regulator that steps down the input voltage to the required 5V. The reverse polarity protection diode is essential to prevent damage to the circuit in case of incorrect power supply connections.
The ultrasonic sensor emits a high-frequency sound wave and listens for the echo that returns after bouncing off an object. The time taken for the echo to return is measured by the microcontroller, which calculates the distance based on the speed of sound. The formula used for calculating distance is Distance = (Time × Speed of Sound) / 2, where the speed of sound in air is approximately 343 meters per second.
The microcontroller is connected to an LCD display, which presents the calculated distance in a user-friendly format. The LCD is interfaced using a suitable communication protocol (often 4-bit or 8-bit mode), allowing the microcontroller to send commands and data to the display. A push button is included to initiate the measurement process, providing an interactive user experience. When pressed, the microcontroller triggers the ultrasonic sensor to emit a burst, waits for the echo, and subsequently processes the data to update the LCD with the distance measurement.
Overall, the PING Ultrasonic Range Finder circuit is a practical and efficient solution for distance measurement applications, combining simplicity and effectiveness in its design.A PING Ultrasonic Range Finder to build up a system which is capable of detect and measure the distance (in mm unit) of the closest object in front of the sensor. It is like a digital measuring tape where you point the sensor to an object, press the read button and the LCD will display the distance of the object in millimeter unit.
The PING) ultrasonic range finder is an easy to used sensor from Parallax. It can nicely detect the object in front with the distance from 2cm to 3m. The PING) sensor works by transmitting an ultrasonic burst and providing an output pulse that corresponds to the time required for the burst echo to return to the sensor. By measuring the echo pulse width, the distance to target can easily be calculated. The circuit for the system is quite simple. I am using PIC16F876A as the main controller. As usual, to operate the whole system, you need the power part which consist of on/off switch, power regulator, diode for wrong polarity protection and some capacitors.
You also need the basic components to support the operation of microcontroller like the crystal to generate clock, an active low push button for the master reset, programming port and some capacitors. For this project, I need to have a push button to input start read command and a LCD to display the output which is the distance value.
The connection for the Ping Ultrasonic sensor is also simple, the ground pin connect to the common ground of the circuit, the 5v connect to the circuit`s vdd and at last the signal pin connect to one of the I/O pin of the microcontroller.
digital step km counter circuit schematic
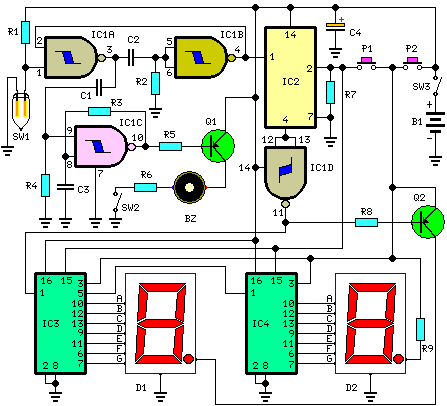
This circuit measures the distance covered during a walk. The hardware is housed in a compact box that can be conveniently placed in a pants pocket. The display is designed as follows: the leftmost display, D2 (the most significant digit),...
Simple Ultrasonic Wave Generator
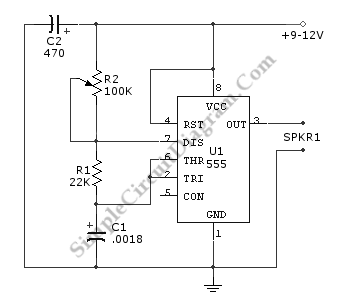
An ultrasonic sound wave can be generated using an electronic circuit. This simple electronic circuit can generate an ultrasonic wave with a frequency range of 12 kHz and above.
The electronic circuit designed for generating ultrasonic sound waves typically utilizes an...
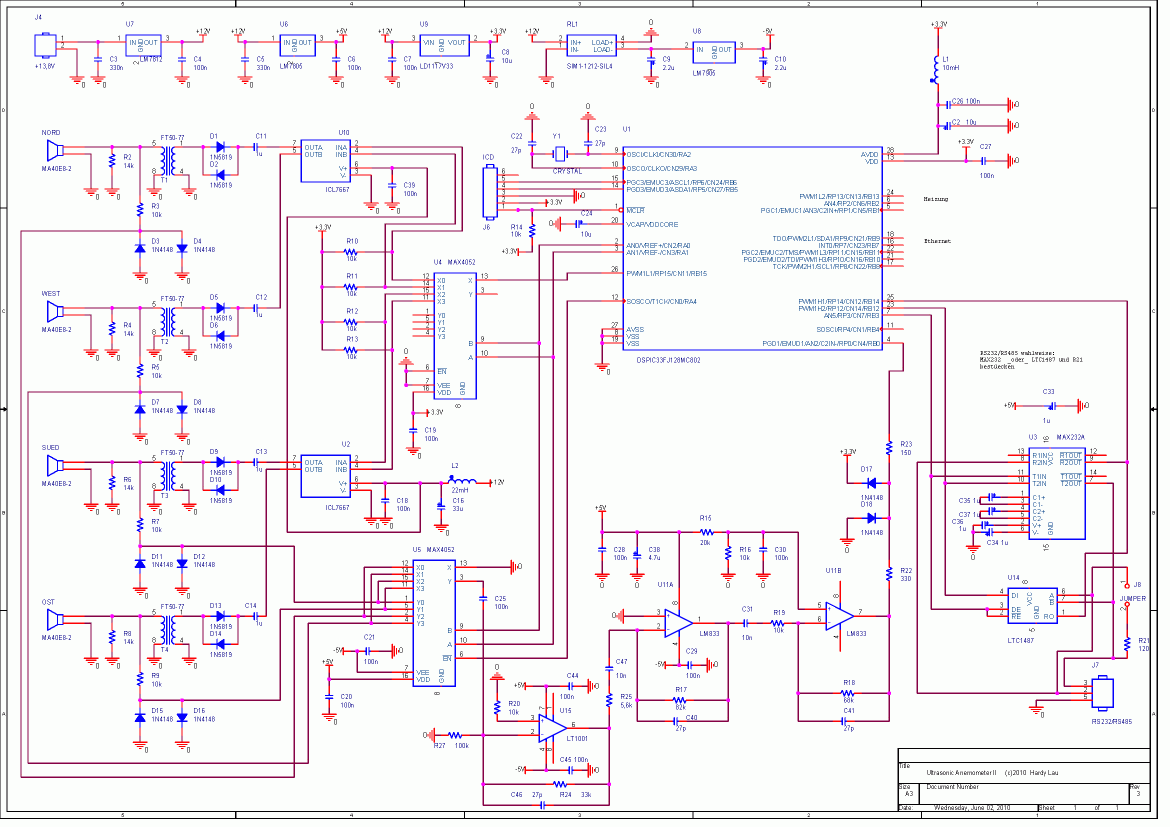
Ultrasonic anemometer Ultrasonic wind sensor
This ultrasonic anemometer is designed for the two-dimensional measurement of horizontal wind speed components and wind direction, as well as virtual temperature. Due to its high measurement rate, the device effectively captures gusts and peak values without delay. The accuracy...
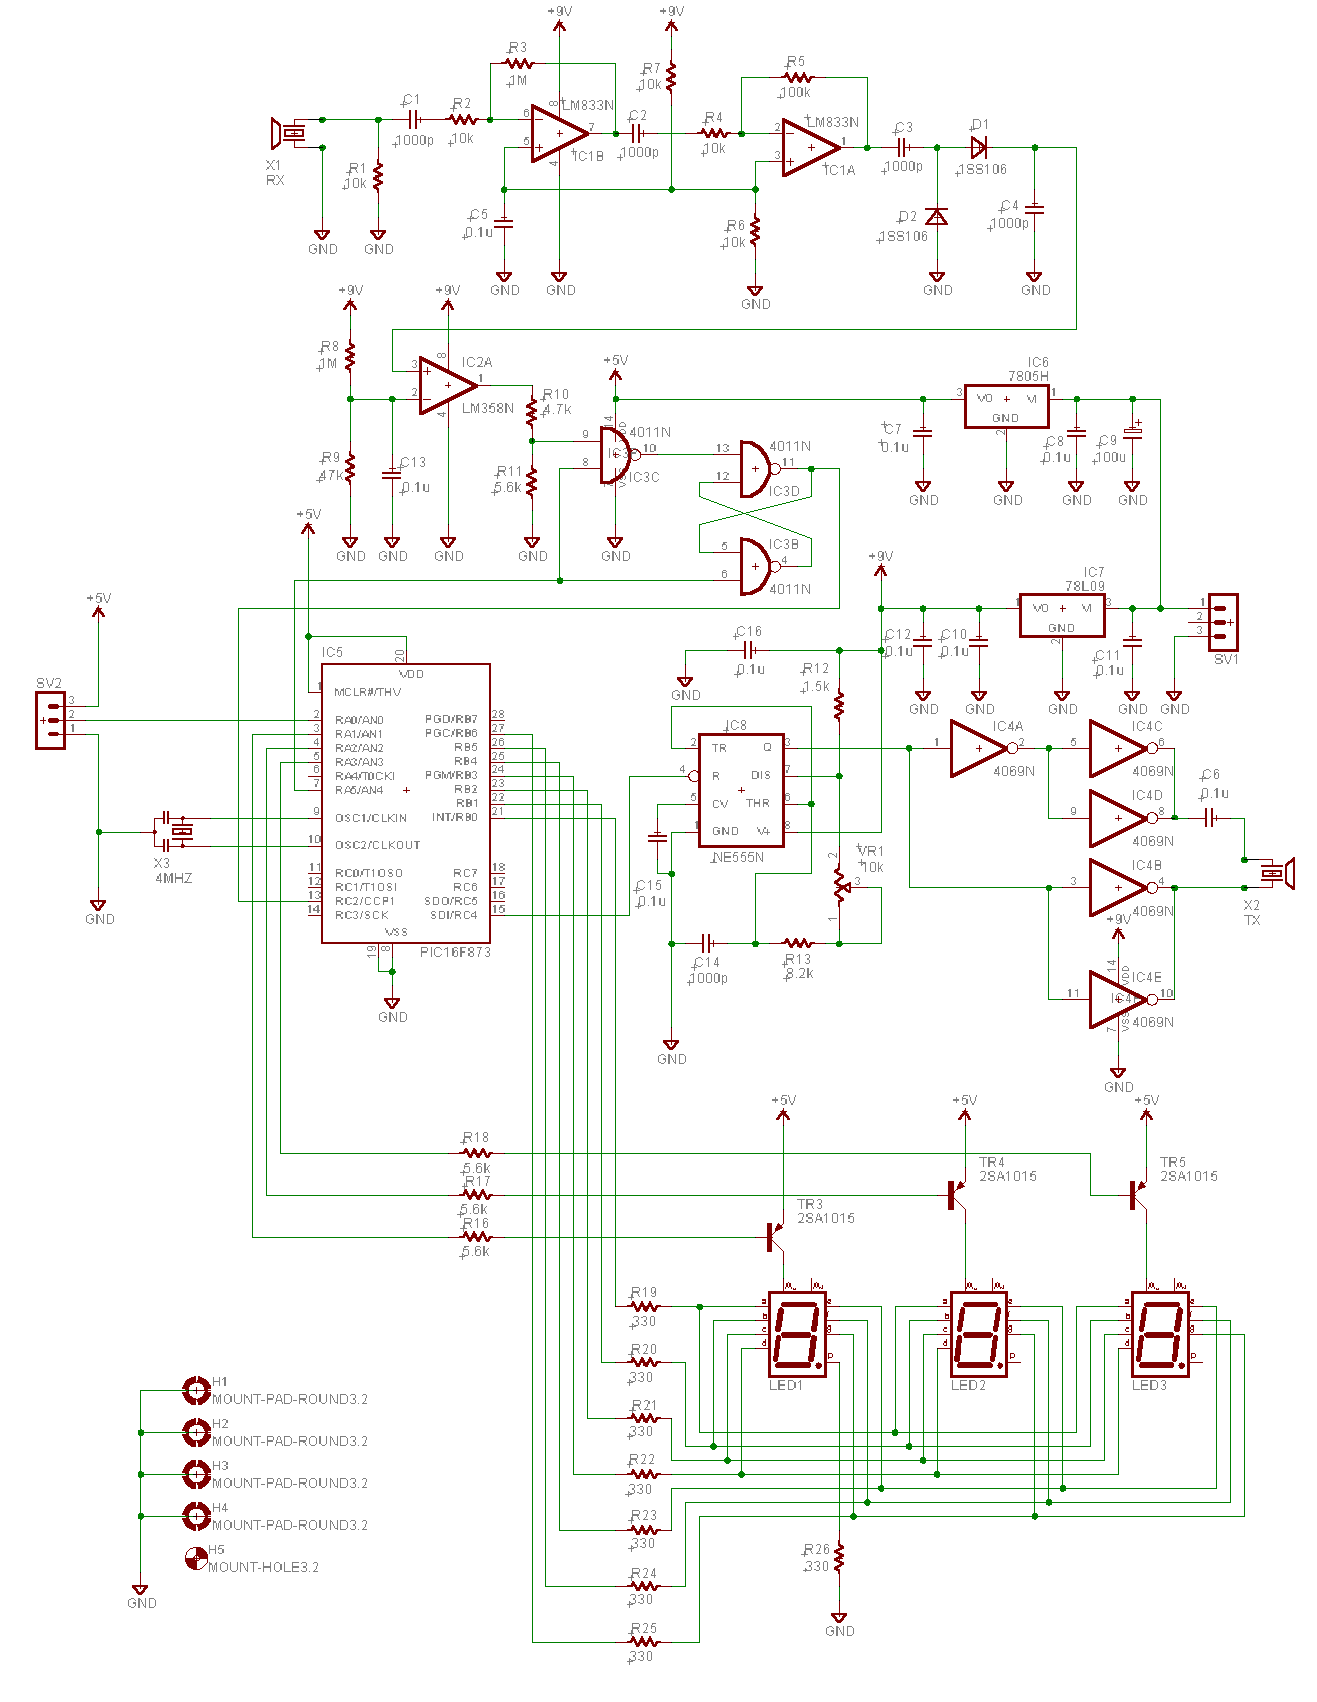
EAGLE Ultrasonic Range Meter
The oscillation circuit of the transmitter was added. An oscillation circuit using a 555 IC is implemented for a modified circuit. This allows for easy adjustment of the oscillation frequency, necessitating changes to the software.
The described circuit employs the 555...
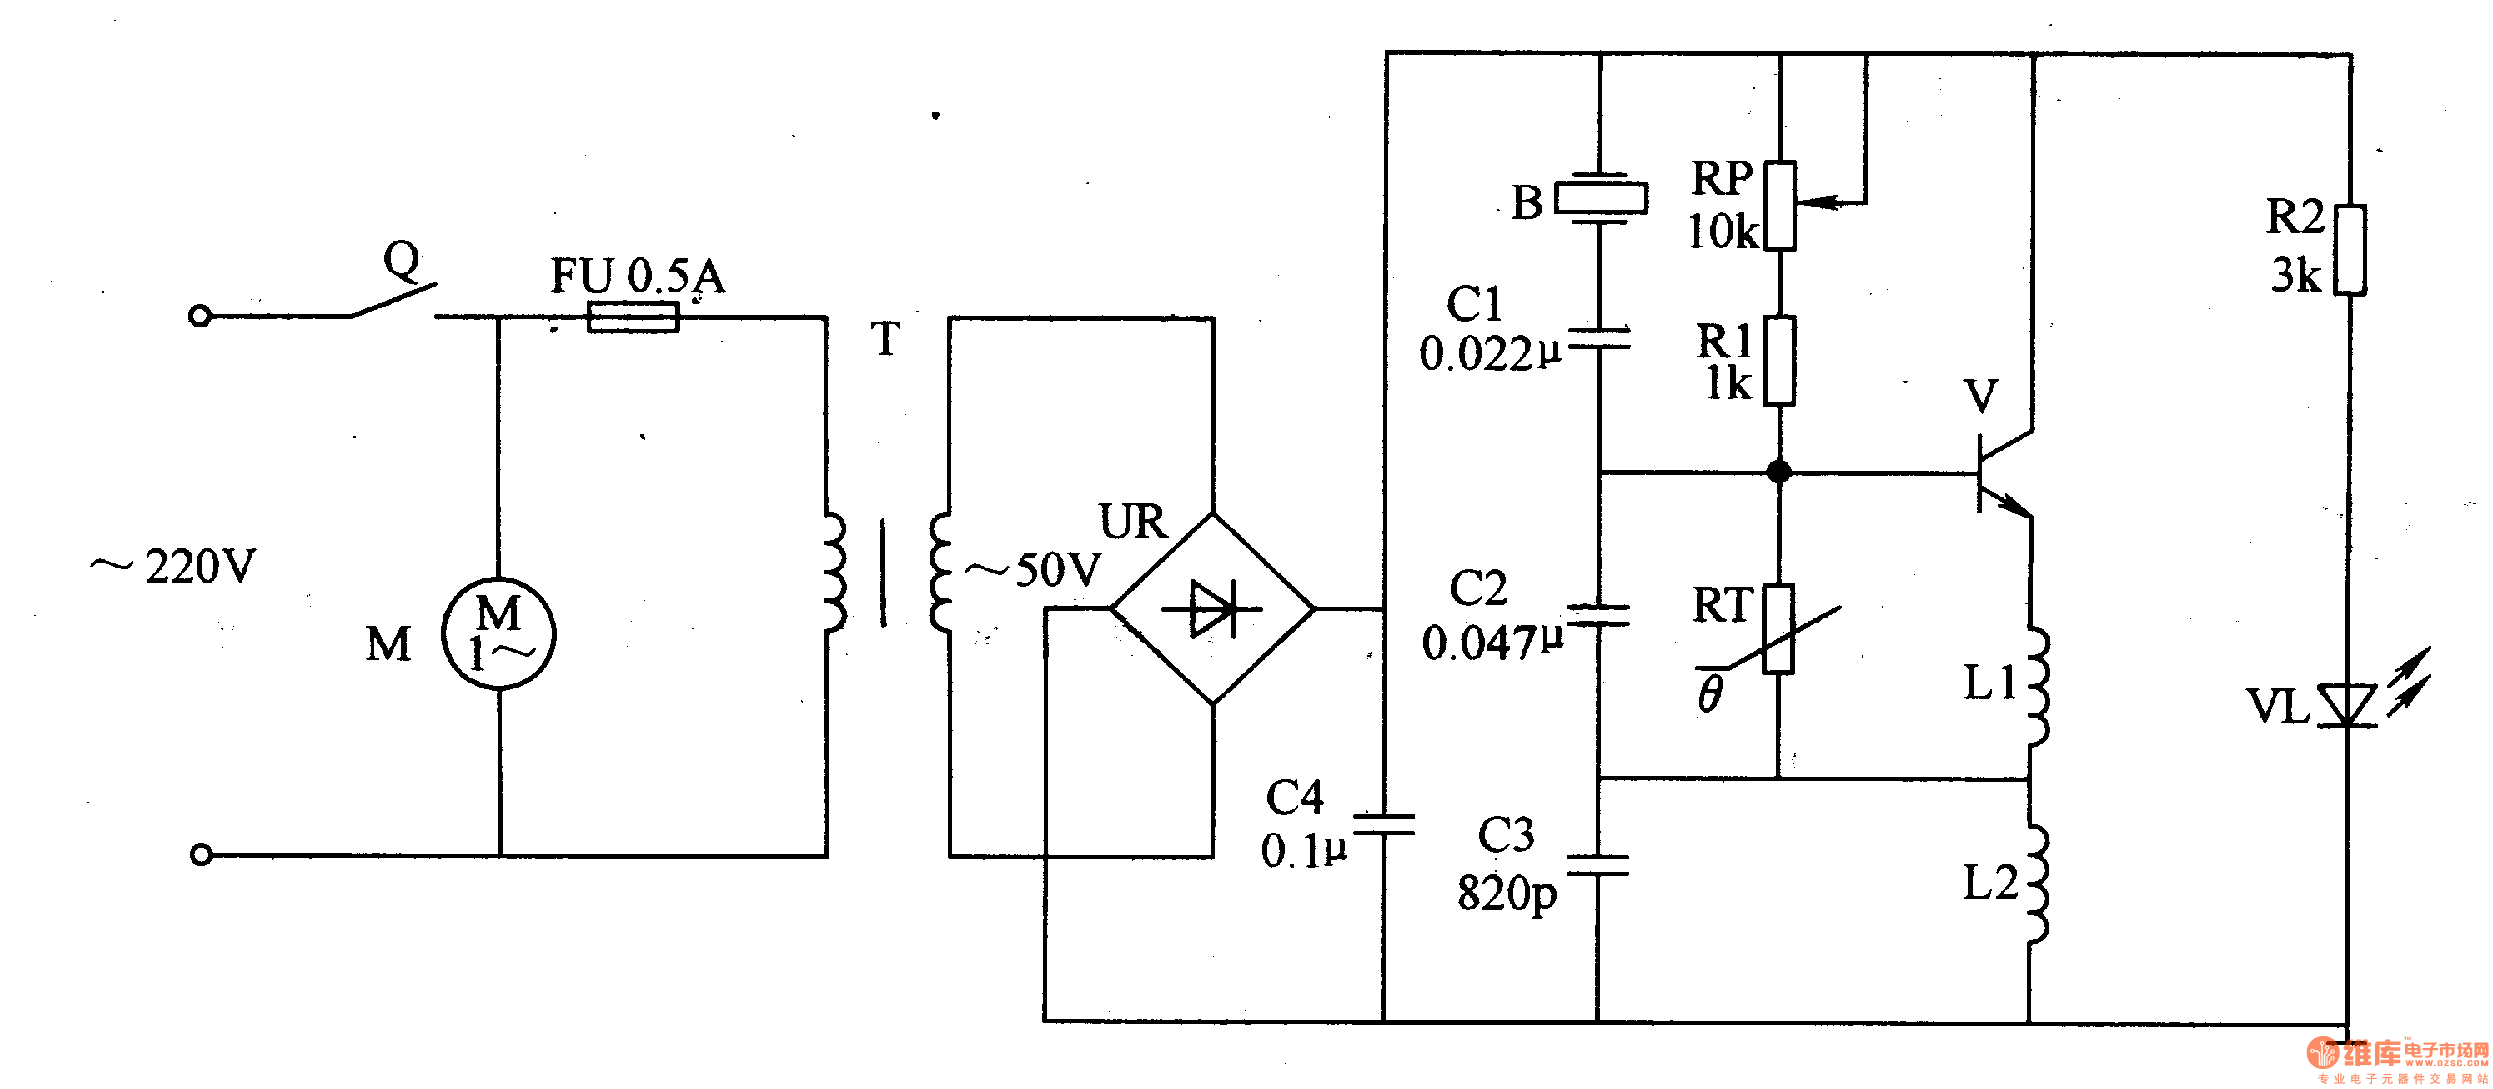
Medical ultrasonic atomizer 1
The medical ultrasonic atomizer circuit consists of a power supply circuit, an ultrasonic oscillator, and an atomizer circuit, as illustrated in figure 9-110. The power supply circuit includes a timer (Q), a fuse (FU), a current transformer (T), bridge rectifiers...
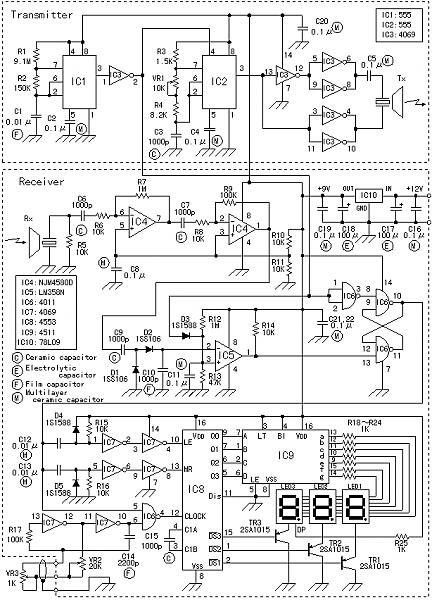
circuit for ultrasonic parking sensor
A USBI2C can be utilized with each sensor, allowing for a configuration of four sensors at a cost of £120. The SRF02 operates on the I2C bus, which should not be extended beyond approximately 2 meters. The proposed solution involves...
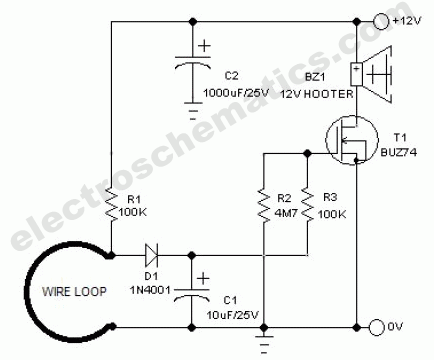
Wire Break Sensor Alarm Circuit Schematic
The circuit of a loop sensor-based simple security alarm is described here. The sensor loop consists of a short length of thin enamelled copper wire.
The loop sensor security alarm operates on the principle of detecting interruptions in the circuit formed...
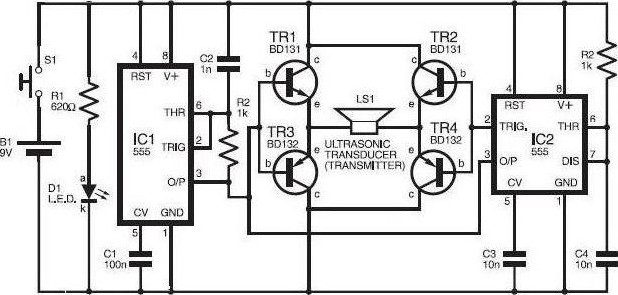
cat and dog repellent
The electronic dog repellent circuit diagram presented is a high-output ultrasonic transmitter designed primarily to repel dogs and cats. It serves as a deterrent for certain animals but should not be relied upon for defense against aggressive dogs. While it...
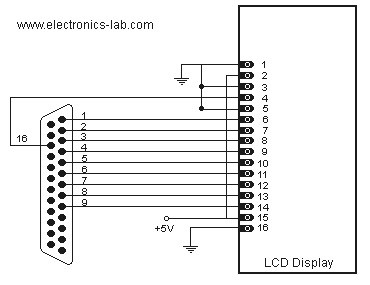
LCD Display printer cable with HD44780
Connecting a LCD display to your personal computer is an easy job. Displaying data from your PC to a LCD can be proven very exciting, so give it a try and build your own today! In this article, we will...