
C-52EVB Robot Controller
#robot controller
#Motorola 68HC11
#C-52EVB
#robotics
#competition
#black tape tracking
#student project
#embedded systems
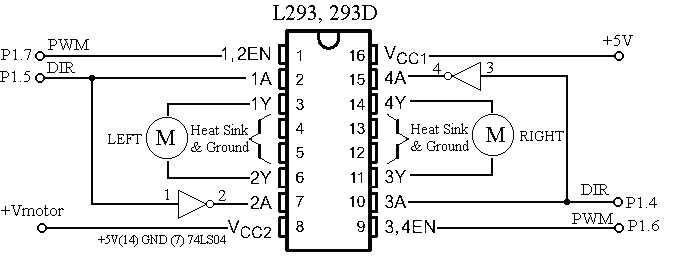
Description: The MiniBoard, a Motorola 68HC11 Robot Controller board designed by Fred G. Martin, also uses this driver. The day after, I then decided to prepare the page describing how to use C-52 EVB as a robot controller board. I asked my student for competition, build yourselves robot that can track the black tape. Prize for the winner is 100 US$, with a bit condition that the winner must pay for a big party at Soi Jinda`s Somtum (Papaya Salad) shop. And one of the competitor is me. I thought the rule should be conceived roughly by students and technically by me. The picture on that day will put here soon.
The MiniBoard is an embedded system based on the Motorola 68HC11 microcontroller, which is widely recognized for its versatility in robotics applications. This board is equipped with various input/output interfaces, allowing it to interact with sensors and actuators effectively. The design includes a robust driver circuit that facilitates the control of motors, essential for the movement of robotic systems.
The C-52 Evaluation Board (EVB) serves as an additional platform for developing robotic applications. It is equipped with features that support the integration of various sensors, particularly for line-following tasks, such as tracking black tape. This functionality is crucial for competitions where robots must autonomously navigate predefined paths.
In a competitive setting, participants are encouraged to build robots capable of following a line, utilizing the capabilities of the MiniBoard and C-52 EVB. The challenge not only promotes technical skills but also fosters creativity among students. The incentive structure, including a monetary prize and a social gathering, enhances engagement and motivation.
The circuitry of the MiniBoard typically includes power management components, signal conditioning circuits for sensor inputs, and H-bridge configurations to drive DC motors. The inclusion of these elements allows for precise control over the robot's movements and responses to environmental stimuli.
Overall, the MiniBoard and C-52 EVB represent a significant step in educational robotics, providing hands-on experience in circuit design, programming, and system integration for aspiring engineers and hobbyists.The MiniBoard, a Motorola 68HC11 Robot Controller board designed by Fred G. Martin, also uses this driver. The day after, I then decided to prepare the page describing how to use C-52 EVB as a robot controller board. I asked my student for competition, build yourselves robot that can track the black tape. Prize for the winner is 100 US$, with a bit condition that the winner must pay for a big party at Soi Jinda`s Somtum (Papaya Salad) shop.
And one of the competitor is me. I thought the rule should be conceived roughly by students and technically by me. The picture on that day will put here soon.
The MiniBoard is an embedded system based on the Motorola 68HC11 microcontroller, which is widely recognized for its versatility in robotics applications. This board is equipped with various input/output interfaces, allowing it to interact with sensors and actuators effectively. The design includes a robust driver circuit that facilitates the control of motors, essential for the movement of robotic systems.
The C-52 Evaluation Board (EVB) serves as an additional platform for developing robotic applications. It is equipped with features that support the integration of various sensors, particularly for line-following tasks, such as tracking black tape. This functionality is crucial for competitions where robots must autonomously navigate predefined paths.
In a competitive setting, participants are encouraged to build robots capable of following a line, utilizing the capabilities of the MiniBoard and C-52 EVB. The challenge not only promotes technical skills but also fosters creativity among students. The incentive structure, including a monetary prize and a social gathering, enhances engagement and motivation.
The circuitry of the MiniBoard typically includes power management components, signal conditioning circuits for sensor inputs, and H-bridge configurations to drive DC motors. The inclusion of these elements allows for precise control over the robot's movements and responses to environmental stimuli.
Overall, the MiniBoard and C-52 EVB represent a significant step in educational robotics, providing hands-on experience in circuit design, programming, and system integration for aspiring engineers and hobbyists.The MiniBoard, a Motorola 68HC11 Robot Controller board designed by Fred G. Martin, also uses this driver. The day after, I then decided to prepare the page describing how to use C-52 EVB as a robot controller board. I asked my student for competition, build yourselves robot that can track the black tape. Prize for the winner is 100 US$, with a bit condition that the winner must pay for a big party at Soi Jinda`s Somtum (Papaya Salad) shop.
And one of the competitor is me. I thought the rule should be conceived roughly by students and technically by me. The picture on that day will put here soon.
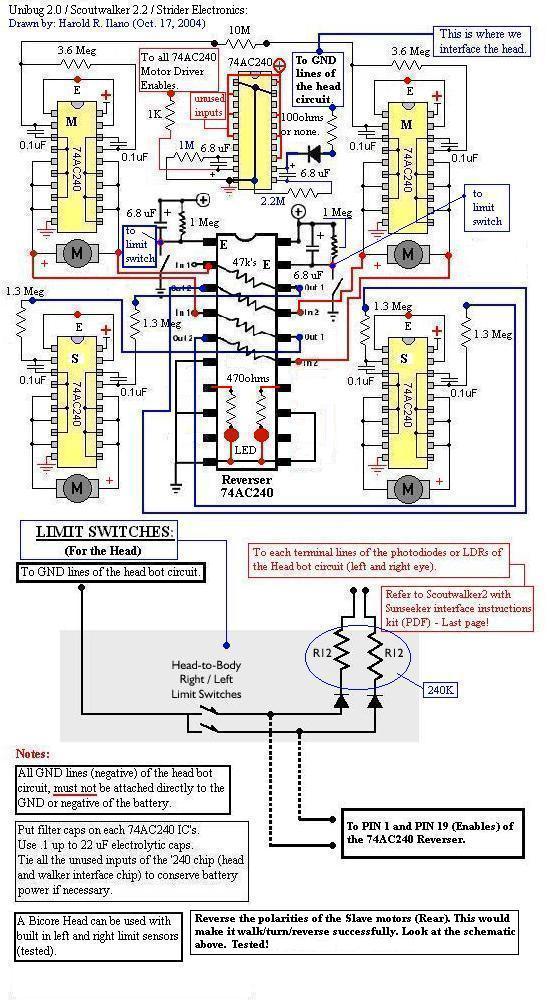
Robotics Page
This is an attempt to create a simple and compact photovore. Although it may not be visually appealing, it serves as a good starting point for beginners. It is a personal version of the Dozer photovore. The latest robot built...
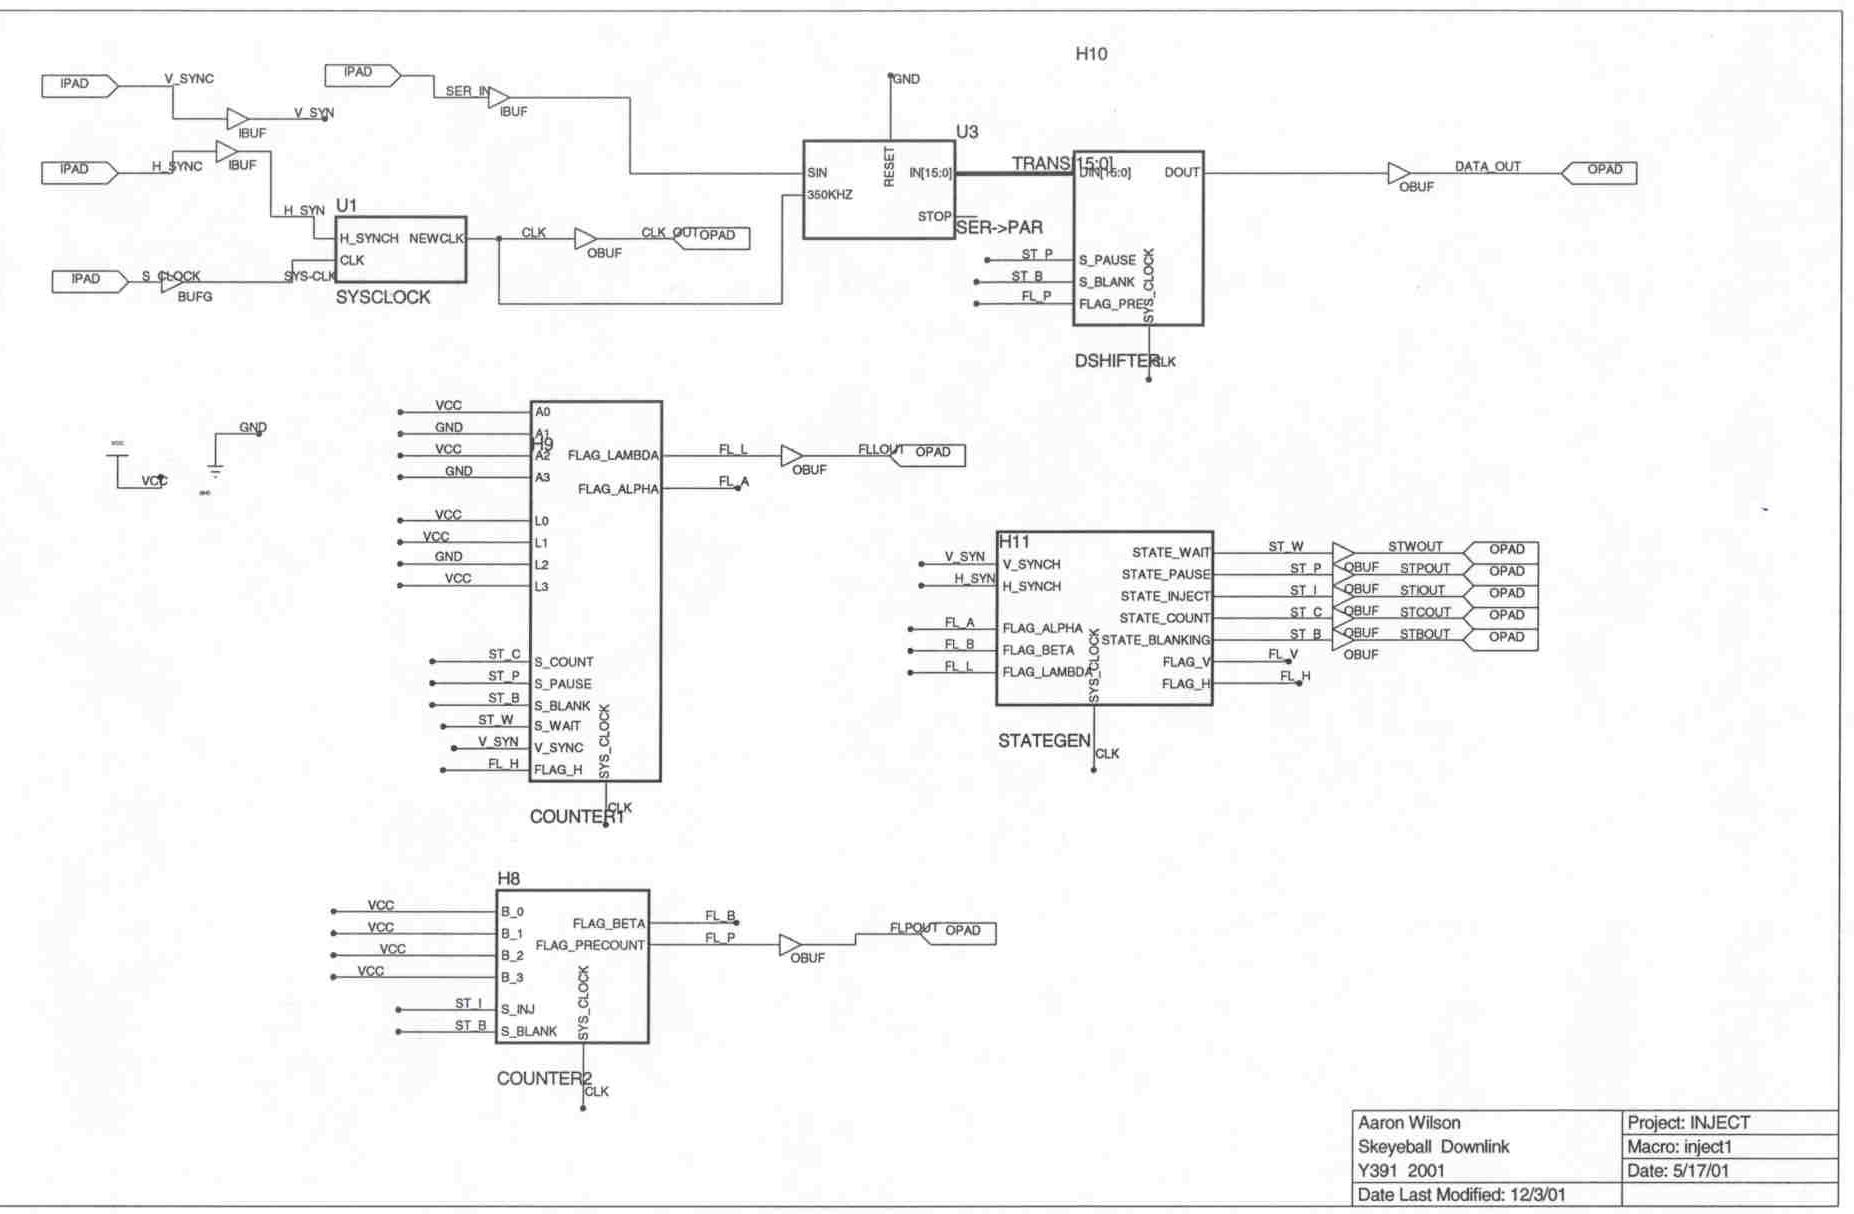
Downlink Project Description
The Skeyeball project is an ongoing initiative within the Indiana University System Design Methods Laboratory, aimed at providing graduate and undergraduate students with opportunities to engage in embedded system design and implement various projects. The downlink segment of the project...
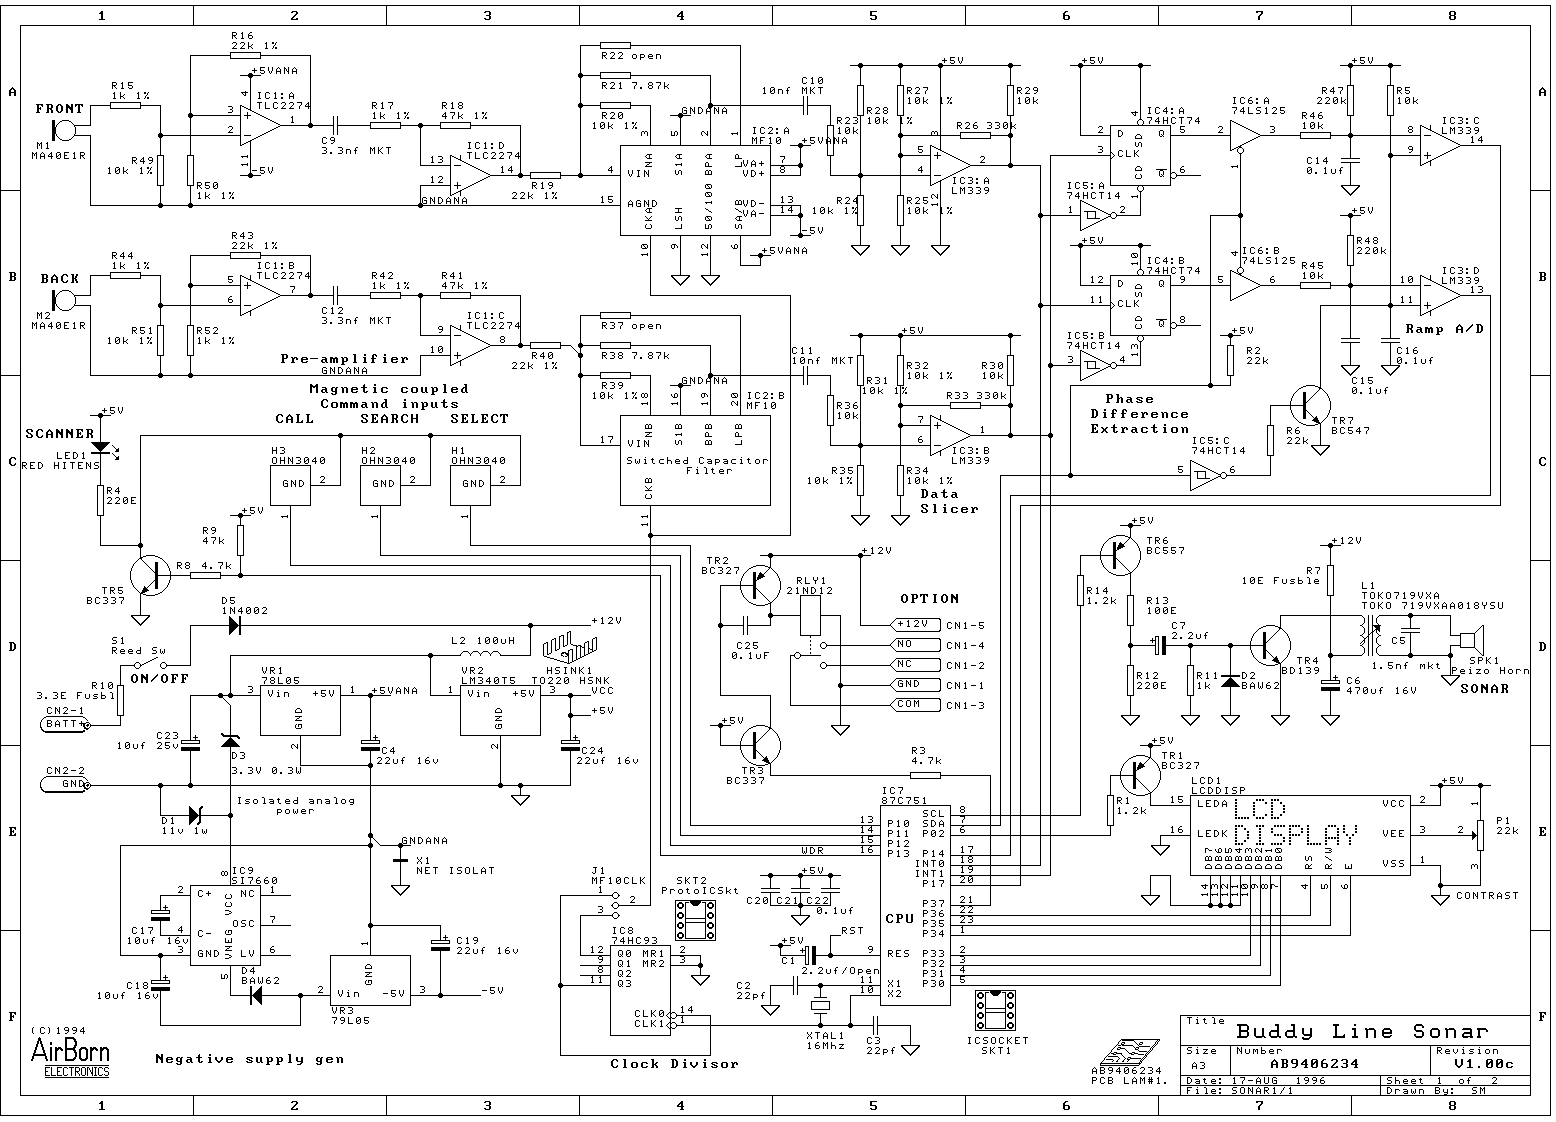
AirBorn Electronics project
Embedded system design engineers create examples of their work from the 1990s era.
Embedded systems have evolved significantly since the 1990s, and the design work from that period reflects the technological limitations and innovations of the time. Engineers in this field...
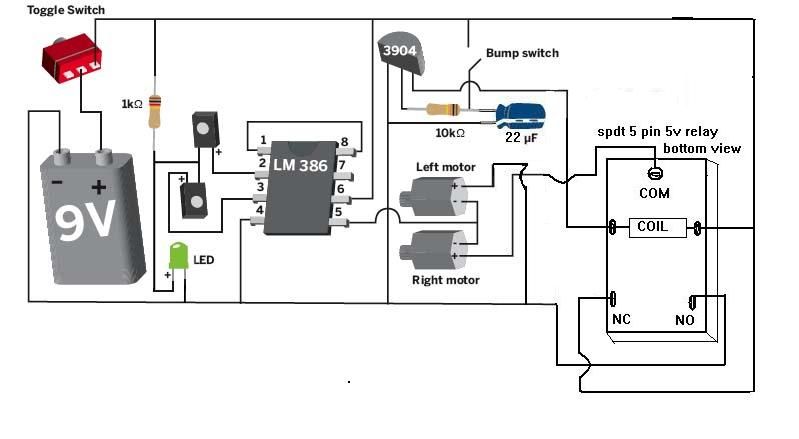
Mousebot Revisited
Mousebot from Make vol 2 is a fun introduction to robotics. This documentation provides an expanded overview of a Mousey build from start to finish.
The Mousebot project serves as an engaging entry point into the world of robotics, particularly suitable...
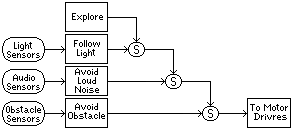
Subsumption Architecture
This term refers to a robotic control concept developed by Rodney Brooks, closely associated with behavior-based robotics, which incorporates modular behavior-based artificial intelligence. Unlike traditional artificial intelligence that relies on a centralized, top-down planning, execution, and monitoring structure, subsumption architecture...
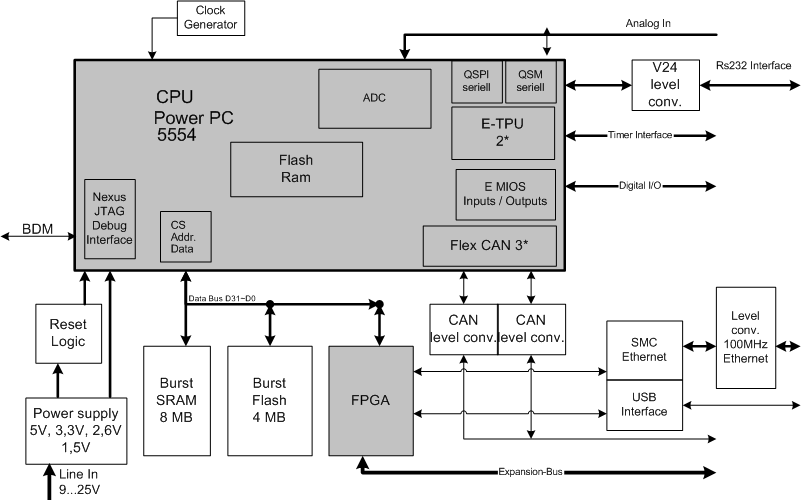
Electronics Engineering Herald - online magazine of electronics -home
Embedded systems serve as the core of most electronics-based systems, enabling data access, processing, storage, and control. While some simple electronic circuits can be designed without a microprocessor or microcontroller, this approach is often economically impractical, except for basic passive...
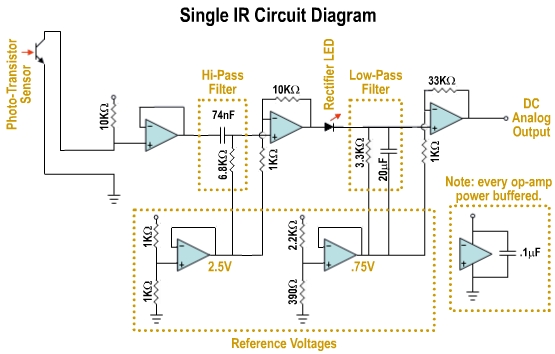
mechatronics Design
The robot was controlled using a Motorola 68HC11 on a special MC11 input/output board provided by the Stanford Smart Product Design Lab (SPDL). The SPDL also supplied motor controller boards, each consisting of a DS3658 stepper controller, an SN754410 h-bridge,...
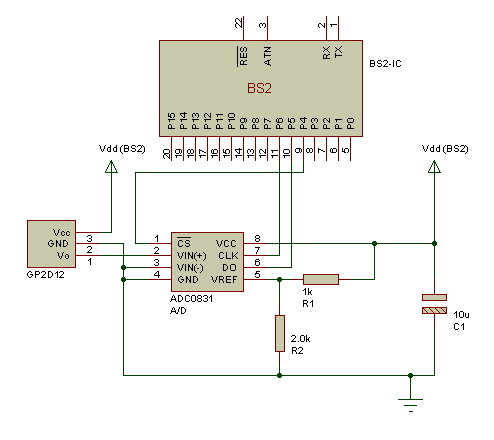
Code Collection
CrustCrawler develops and manufactures advanced walking robots and robotic accessories.
CrustCrawler specializes in the design and production of innovative walking robots, which incorporate advanced technologies and engineering principles to achieve improved mobility and functionality. These robots are typically characterized by their...
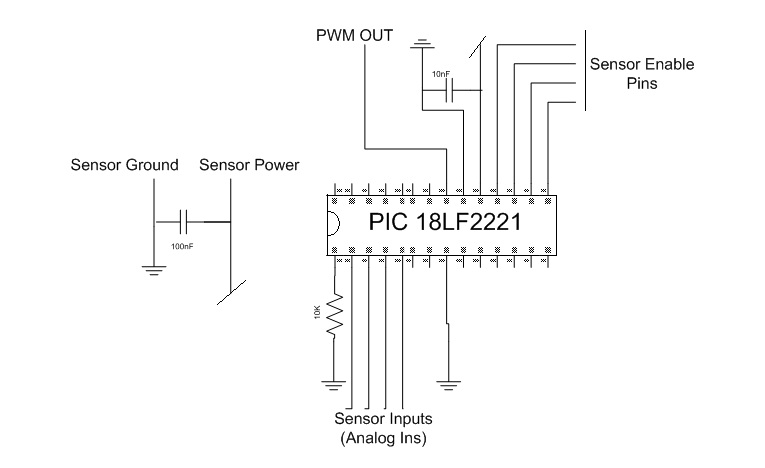
maze robot sensor integration
This project was completed during a robotics course taught by Prof. Dave Barret at Olin College. The final project aimed to navigate a maze using a Surveyor robotic platform. Additional sensors were incorporated into the robot, with a focus on...