
Easy Debugging Terminal
#LCD terminal
#PIC16F84
#serial data
#debugging
#hexadecimal display
#ASCII display
#9V power
#jumper selection
#serial port
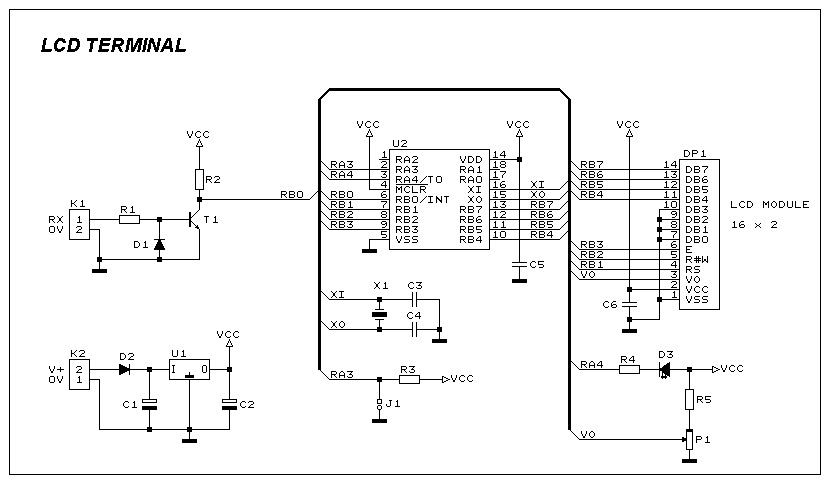
Description: This LCD terminal provides two modes of operation by selecting jumper J1. When J1 is open, the terminal operates as a normal ASCII display terminal; when J1 is closed, the terminal displays the input serial data in hexadecimal format. This mode is useful for viewing raw data from the serial port output. IC U2, a PIC16F84 microcontroller, is used to control the operation of the terminal. Input signal is applied to connector K1. The circuit can be powered either by a 9V DC adapter or by using a 9V battery. Jumper J1 selects the operating mode of the terminal: J1 open for ASCII terminal mode, closed for hexadecimal display mode.
The LCD terminal circuit is designed to facilitate two distinct modes of operation for data display, controlled by jumper J1. In the ASCII mode, with J1 open, the terminal interprets and displays incoming serial data as standard ASCII characters, making it suitable for general-purpose text output. This mode is particularly useful for applications that require human-readable data representation.
Conversely, when J1 is closed, the terminal switches to hexadecimal mode, allowing for the visualization of raw binary data in a more compact hexadecimal format. This capability is essential for debugging and analyzing data streams from various serial devices, as it provides a clear representation of the underlying data values without the need for conversion.
The heart of the terminal's functionality is the PIC16F84 microcontroller (IC U2), which handles the processing of incoming serial data and manages the display output. The microcontroller is programmed to interpret the data format based on the selected mode and drive the LCD display accordingly.
Input signals are received through connector K1, which is designed to interface with standard serial communication lines. The terminal can be powered using either a 9V DC adapter or a 9V battery, providing flexibility for both stationary and portable applications. This dual power option ensures that the terminal can be utilized in various environments without being tethered to a fixed power source.
The implementation of jumper J1 allows for easy switching between the two modes, making the terminal versatile for different tasks. The simplicity of the design, combined with the functionality offered by the PIC16F84 microcontroller, makes this LCD terminal a valuable tool for developers and engineers working with serial data communication.This LCD terminal provide two modes of operation by selecting jumper J1. When J1 is open the terminal operate as a normal ascii display terminal, when J1 is closed the terminal displays the input serial data in hexadecimal format. This mode is useful for viewing raw data from the serial port output. IC U2 a PIC16F84 micro controller is used to control the operation of the terminal. Input signal is applied to connector K1. The circuit can be powered either by 9V dc adapter or by using a 9V battery. Jumper J1 select the operating mode of the terminal, J1 open for ascii terminal mode, closed for hexdecimal display mode.
The LCD terminal circuit is designed to facilitate two distinct modes of operation for data display, controlled by jumper J1. In the ASCII mode, with J1 open, the terminal interprets and displays incoming serial data as standard ASCII characters, making it suitable for general-purpose text output. This mode is particularly useful for applications that require human-readable data representation.
Conversely, when J1 is closed, the terminal switches to hexadecimal mode, allowing for the visualization of raw binary data in a more compact hexadecimal format. This capability is essential for debugging and analyzing data streams from various serial devices, as it provides a clear representation of the underlying data values without the need for conversion.
The heart of the terminal's functionality is the PIC16F84 microcontroller (IC U2), which handles the processing of incoming serial data and manages the display output. The microcontroller is programmed to interpret the data format based on the selected mode and drive the LCD display accordingly.
Input signals are received through connector K1, which is designed to interface with standard serial communication lines. The terminal can be powered using either a 9V DC adapter or a 9V battery, providing flexibility for both stationary and portable applications. This dual power option ensures that the terminal can be utilized in various environments without being tethered to a fixed power source.
The implementation of jumper J1 allows for easy switching between the two modes, making the terminal versatile for different tasks. The simplicity of the design, combined with the functionality offered by the PIC16F84 microcontroller, makes this LCD terminal a valuable tool for developers and engineers working with serial data communication.This LCD terminal provide two modes of operation by selecting jumper J1. When J1 is open the terminal operate as a normal ascii display terminal, when J1 is closed the terminal displays the input serial data in hexadecimal format. This mode is useful for viewing raw data from the serial port output. IC U2 a PIC16F84 micro controller is used to control the operation of the terminal. Input signal is applied to connector K1. The circuit can be powered either by 9V dc adapter or by using a 9V battery. Jumper J1 select the operating mode of the terminal, J1 open for ascii terminal mode, closed for hexdecimal display mode.
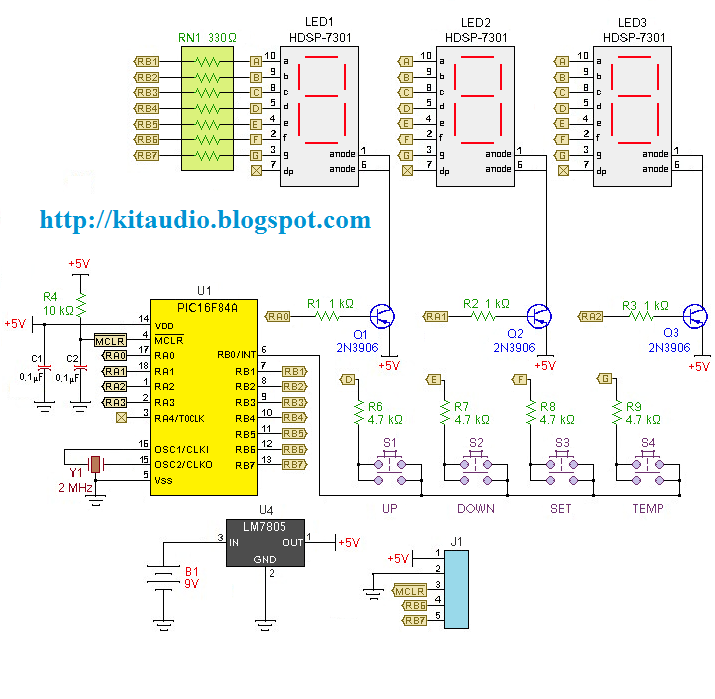
digital thermometer with pic16f84
Redesign a complex solution using minimal external components, resulting in a low-cost application that provides high-precision measurements. This digital thermometer microcontroller project utilizes a watchdog timer function to measure temperature. The watchdog timer (WDT) on all PIC microcontrollers has a...
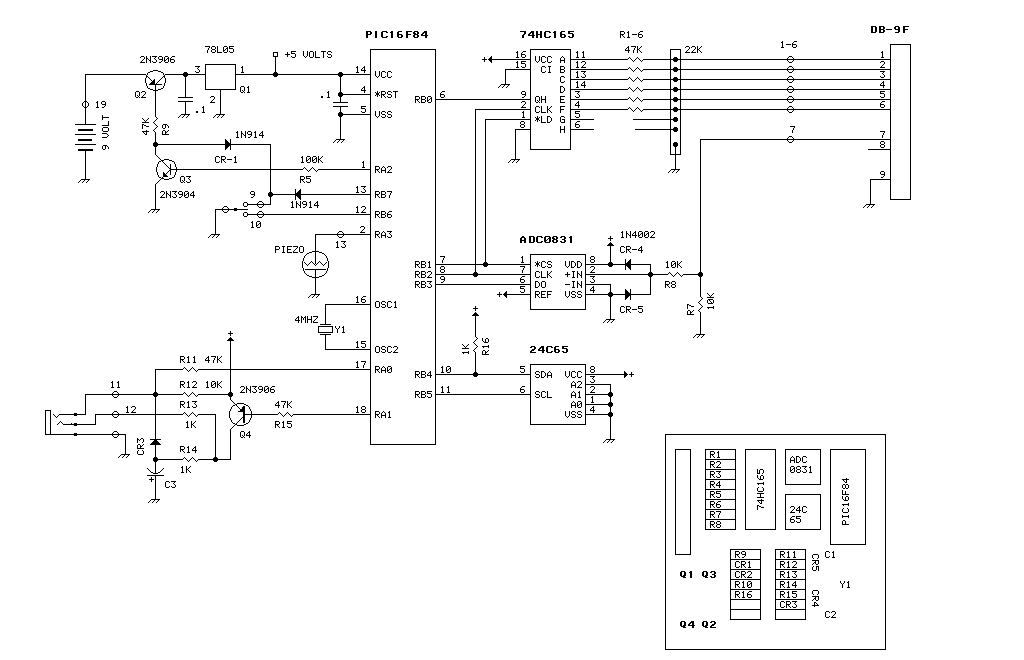
Analogue / Digital Logger I
Intermittent failures in electronic systems are some of the most difficult to diagnose. This device is designed to run for days at a time looking for a failure and logging the event. The unit is based on a PIC16F84. Six...
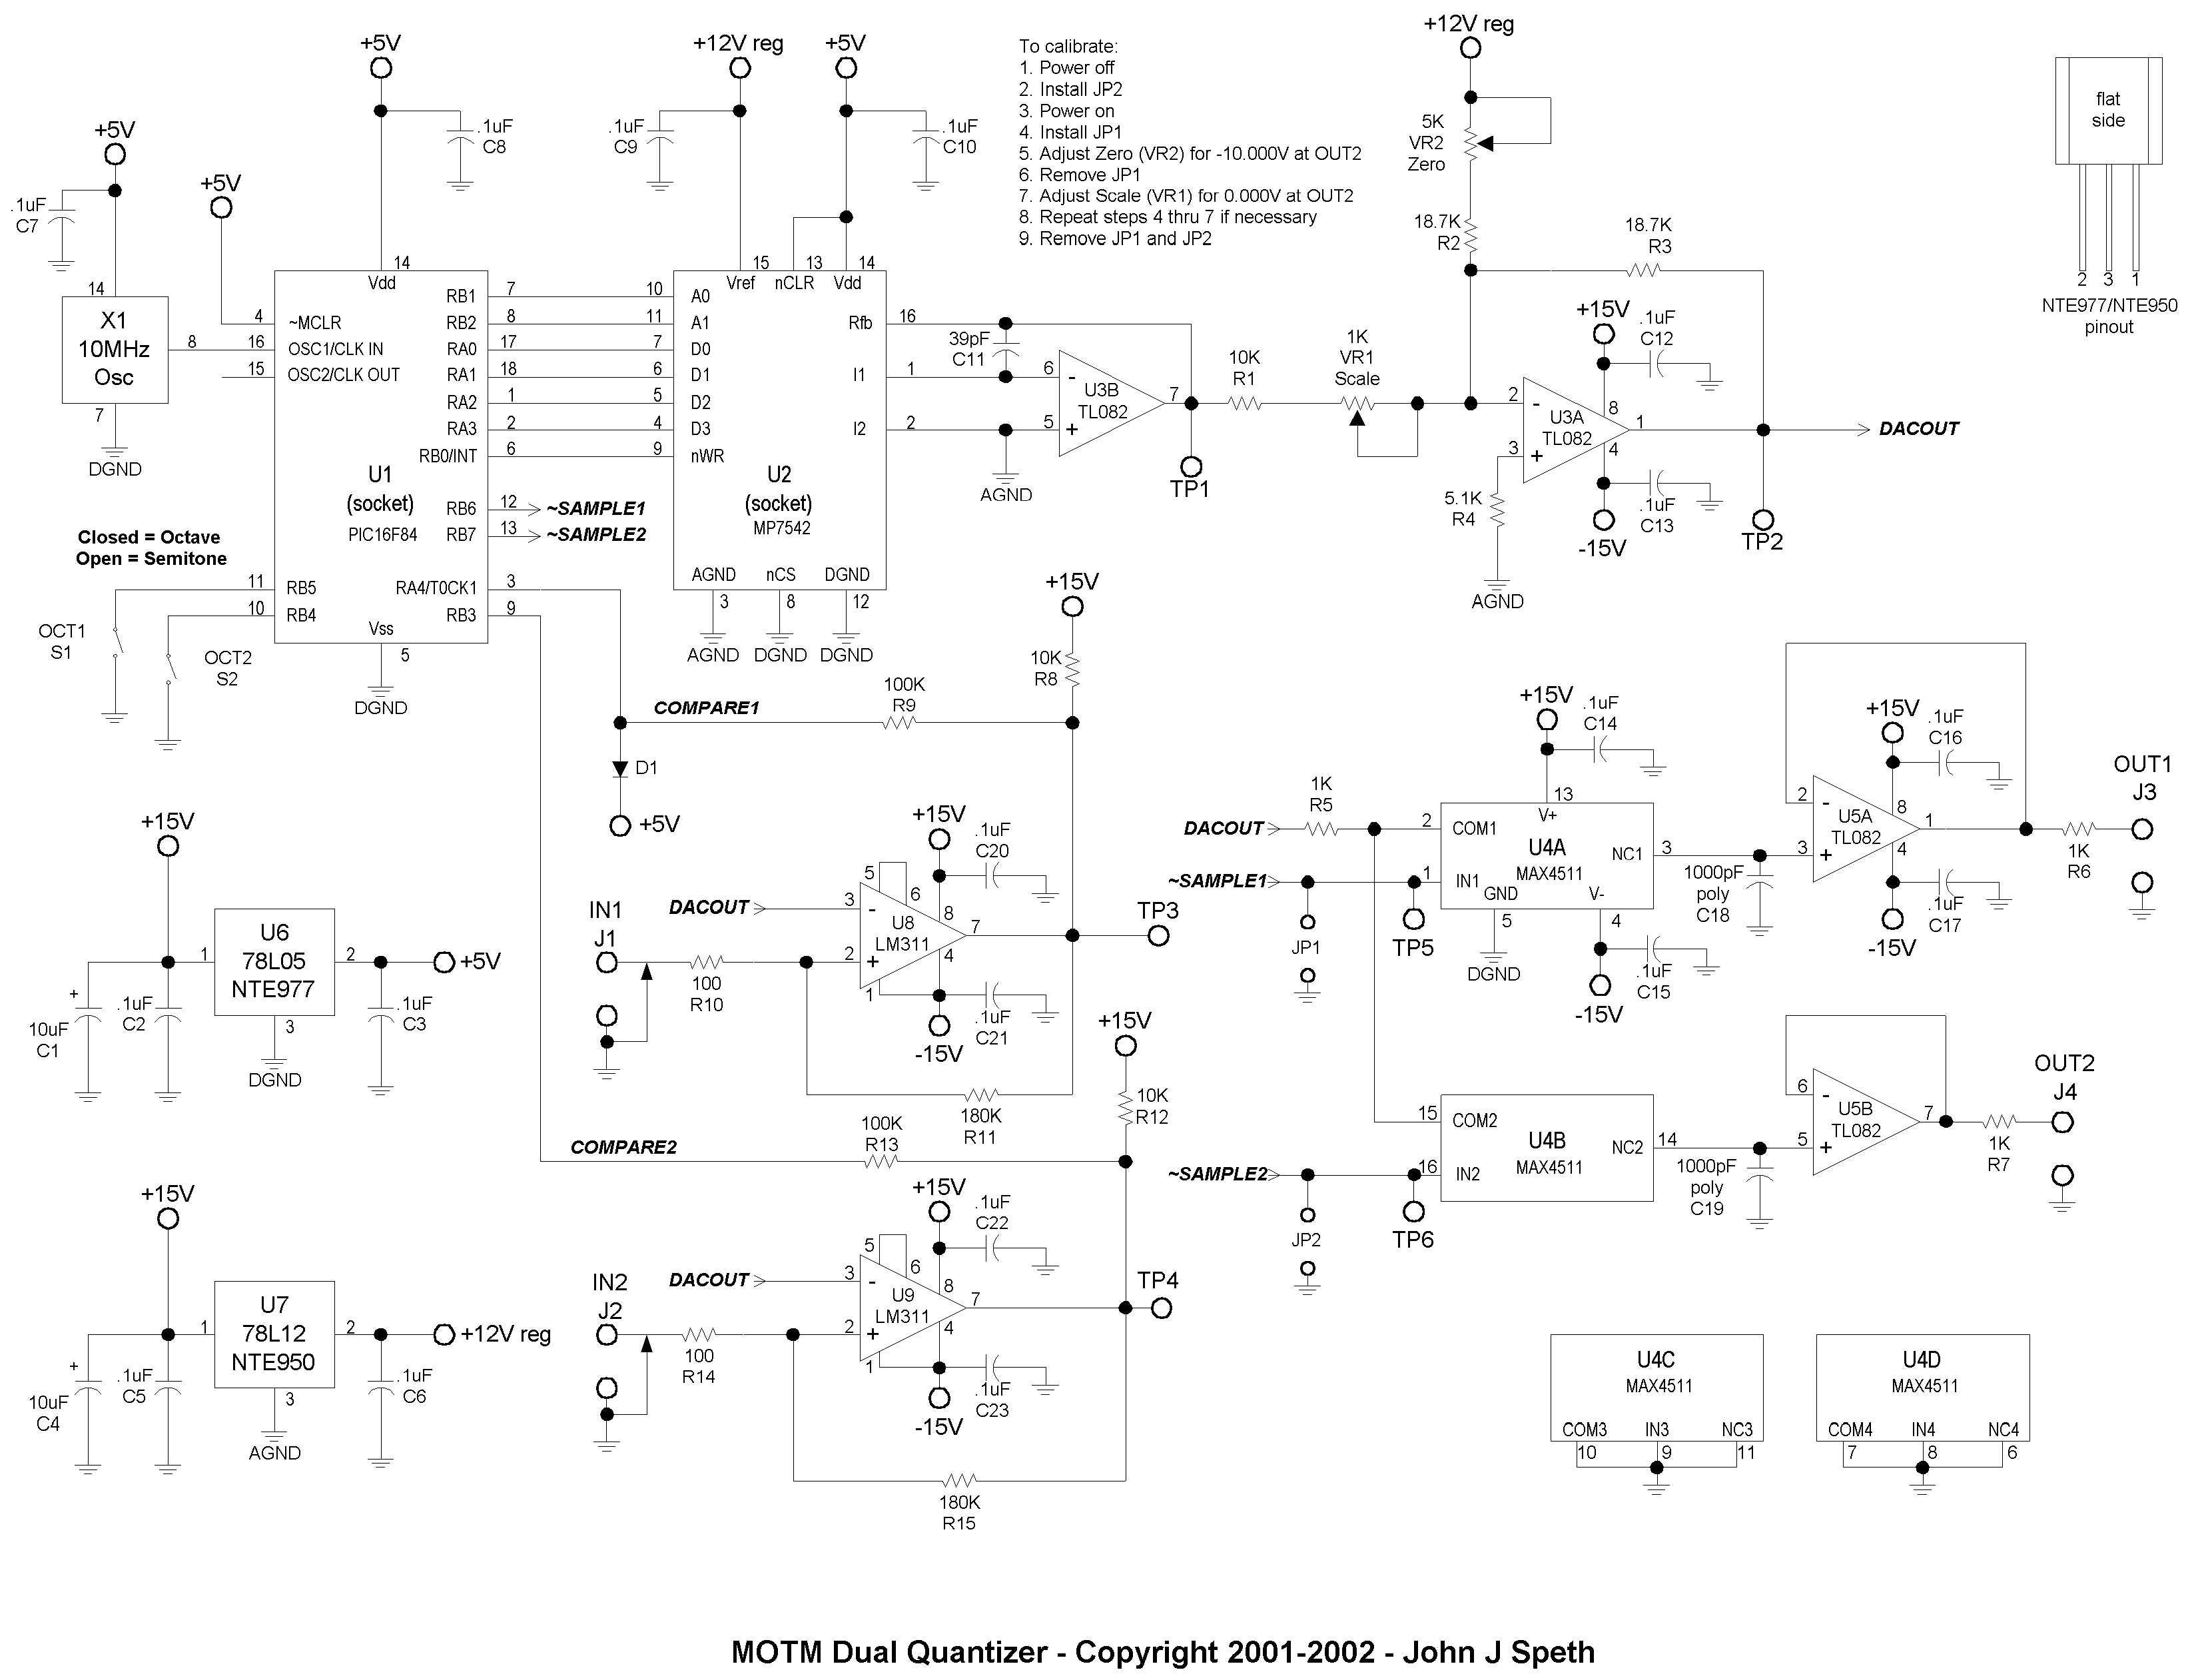
Quantizer
This document outlines a dual-channel quantizer design inspired by Chris List's ARP Style CV Quantizer. The implementation utilizes a Microchip PIC16F84 microcontroller, which enables programmable quantization of voltages in 1/12 volt (semitone) or 1 volt (octave) steps within a range...
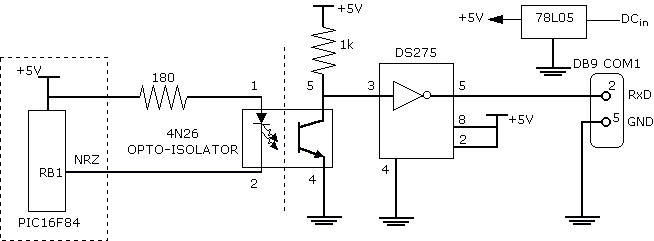
Isolated RS232C for PIC16F84
Another method that helps program development besides a dot LED as the output device is a serial bit. With a serial transmission to a terminal emulator program, developer may then test program running easier than a dot LED. One of...
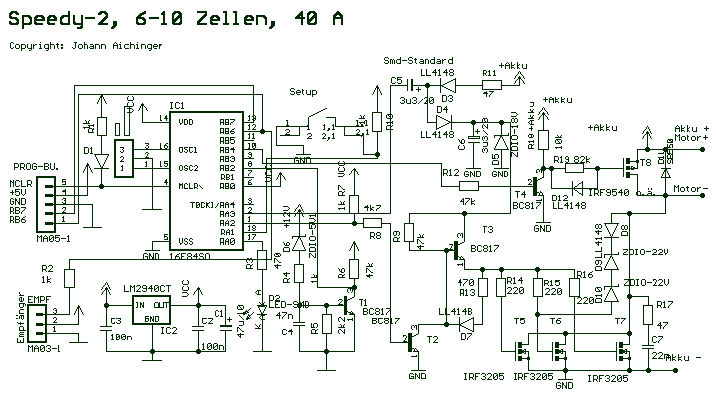
Speed Controller with PIC16F84-04/SO
The controller is a prototype and works well in my plane with 7 cells and a Graupner-Speed 600.
The described controller is a prototype designed for use in a model aircraft, specifically optimized to operate with a battery pack consisting of...
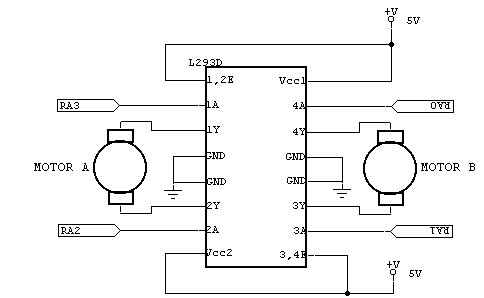
499 Robot
The robot consists of modules controlled by a main controller. The main microcontroller is an 18-pin, 8-bit PIC16F84 Flash microcontroller operating at 4MHz. The microcontroller is programmed in assembly language. The controller is connected via I/O pins to the communication...
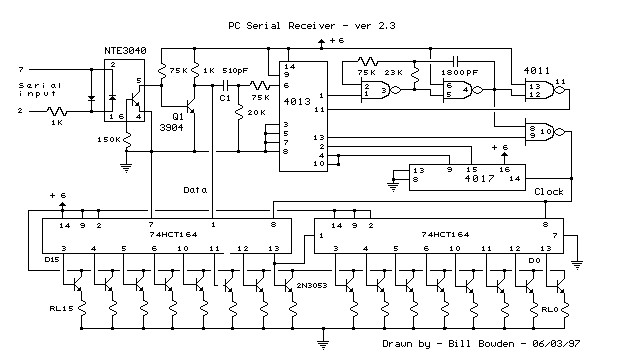
The PC Serial Port Receiver circuit
This circuit requires physical connections to be made to the computer's serial port (COM1 or COM2). It is generally considered difficult to cause harm to oneself or the computer through improper connections to this port; however, there is no assurance...
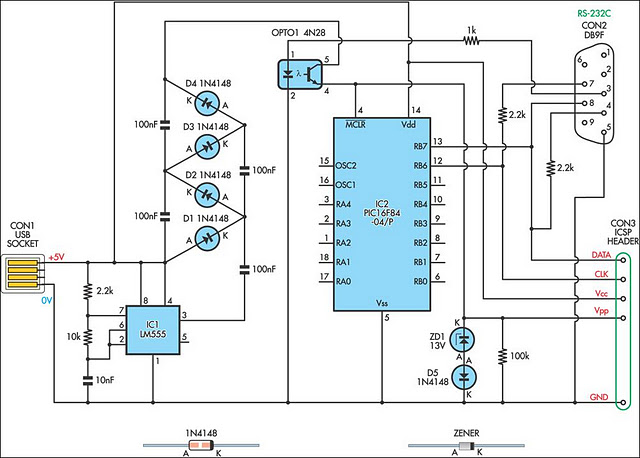
Pic Circuits
A small biped walker constructed from 2mm plywood, powered by two RC servos. It utilizes the widely available and programmable flash microcontroller PIC16F84. This simple circuit is designed to program the PIC16F84 and similar flash memory components. The project includes...
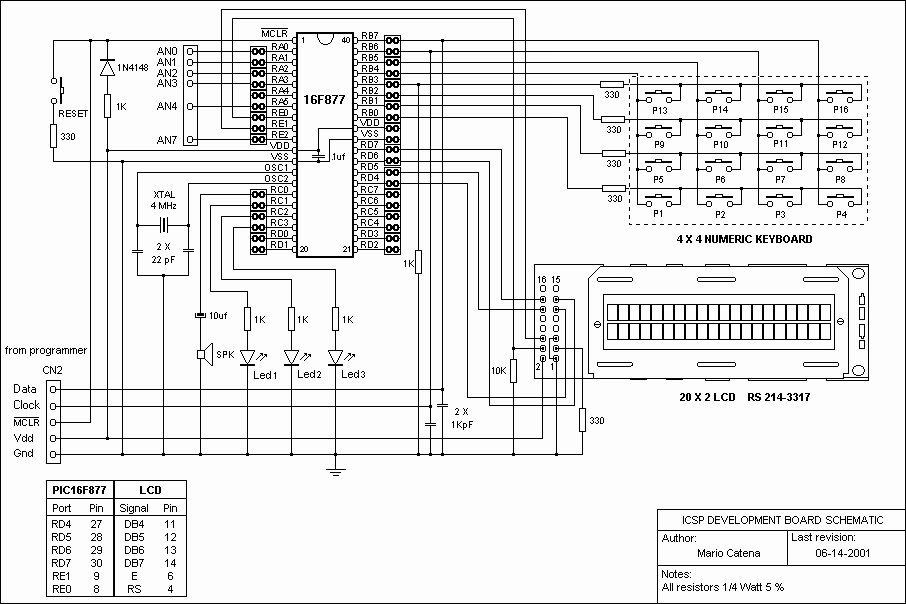
USB PICKit2 programmer
A schematic of a board featuring the PIC16F84 microcontroller, along with other compatible PIC microcontrollers that can be connected to the USB PICKit2 programmer. Additionally, there are concerns regarding the potential damage to the programmer when experimenting with oscillator frequencies...