
Incect Robot circuit (PIC16F818)
#PIC16F818
#servo control
#A/D conversion
#battery monitoring
#light sensing
#robot
#motor control
#embedded systems
#sensor integration
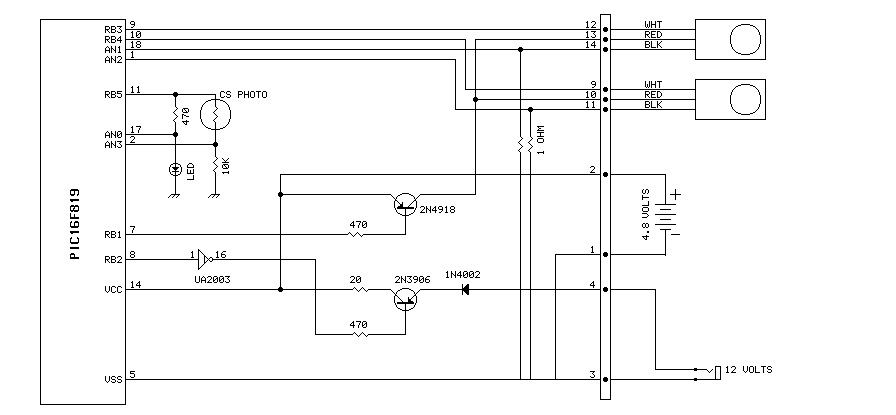
Description: Very little extra circuitry is needed to do both forward and backward walking sequences along with a few other tricks. The PIC16F818 has a lot of features that work well in this situation. As you can see from the schematic and source listing, position pulses for the 2 servos are generated directly from the PIC. Also, the room light level, battery condition, and servo power draw (indicating mechanical loading) can be measured with the internal A/D. The battery condition (although not yet in the software) can be determined by reading voltage across the LED. Since this voltage is (somewhat) constant, reading it actually measures the VCC to the PIC, which is where it gets its reference voltage. A higher reading on the LED means the battery voltage is lower. In its present state, this device powers up and measures the room light level then goes into low power mode (no power to servos, LED, or photo sensor) at 32 kHz internal clock. About once a second, it 'wakes up' and checks the light level. If it finds a significant change, it cycles five steps forward, five steps back, and then shuts back down.
The described circuit utilizes the PIC16F818 microcontroller, which is pivotal for controlling the operation of the device. The microcontroller is programmed to generate position pulses for two servos that facilitate both forward and backward walking sequences. The simplicity of the circuit design minimizes the need for additional components, leveraging the integrated features of the PIC16F818.
The internal Analog-to-Digital (A/D) converter of the microcontroller plays a crucial role in monitoring environmental parameters. It measures the room light level, providing feedback for the device's operational states. Additionally, it can assess battery condition and servo power draw, which indicates the mechanical loading on the servos. Although the software implementation for battery condition monitoring is not yet completed, the voltage across an LED serves as a proxy for the supply voltage (VCC) to the PIC. This method is effective due to the relatively constant voltage drop across the LED, allowing for an indirect measurement of the battery status—lower battery voltage results in a higher reading across the LED.
The operational cycle of the device is designed for energy efficiency. Upon powering up, the system measures the ambient light level and subsequently enters a low-power mode, where power is cut off to the servos, LED, and photo sensor. The microcontroller operates at a reduced clock frequency of 32 kHz during this low-power state. Approximately once every second, the microcontroller 'wakes up' to check the ambient light level. If a significant change is detected, the device executes a sequence of movements—advancing five steps forward and then five steps backward—before returning to its low-power state. This operational strategy balances responsiveness to environmental changes with energy conservation, making the device suitable for prolonged use.Very little extra circuitry is needed to do both forword and backword walking sequences along with a few other tricks. The PIC16F818 has a lot of features that work well in this situation. As you can see from the Schematic and Source Listing, position pulses for the 2 servos are generated dirctly from the PIC.
Also, the room light level, battery condition, and servo power draw (indicating mechanical loading) can be measured with the internal A/D. The battery condition (although not yet in the software) can be determined by reading voltage accross the LED.
Since this voltage is (somewhat) constant, reading it actually measures the VCC to the PIC, which is where it gets its reference voltage. A higher reading on the LED means the battery voltage is lower. In its present state, this device powers up and measures the room light level then goes into low power mode (no power to servos, LED, or photo sensor) at 32 khz internal clock. About once a second, it 'wakes up' and checks the light level. If it finds a significant change, it cycles five steps forward, five steps back, and then shuts back down.
The described circuit utilizes the PIC16F818 microcontroller, which is pivotal for controlling the operation of the device. The microcontroller is programmed to generate position pulses for two servos that facilitate both forward and backward walking sequences. The simplicity of the circuit design minimizes the need for additional components, leveraging the integrated features of the PIC16F818.
The internal Analog-to-Digital (A/D) converter of the microcontroller plays a crucial role in monitoring environmental parameters. It measures the room light level, providing feedback for the device's operational states. Additionally, it can assess battery condition and servo power draw, which indicates the mechanical loading on the servos. Although the software implementation for battery condition monitoring is not yet completed, the voltage across an LED serves as a proxy for the supply voltage (VCC) to the PIC. This method is effective due to the relatively constant voltage drop across the LED, allowing for an indirect measurement of the battery status—lower battery voltage results in a higher reading across the LED.
The operational cycle of the device is designed for energy efficiency. Upon powering up, the system measures the ambient light level and subsequently enters a low-power mode, where power is cut off to the servos, LED, and photo sensor. The microcontroller operates at a reduced clock frequency of 32 kHz during this low-power state. Approximately once every second, the microcontroller 'wakes up' to check the ambient light level. If a significant change is detected, the device executes a sequence of movements—advancing five steps forward and then five steps backward—before returning to its low-power state. This operational strategy balances responsiveness to environmental changes with energy conservation, making the device suitable for prolonged use.Very little extra circuitry is needed to do both forword and backword walking sequences along with a few other tricks. The PIC16F818 has a lot of features that work well in this situation. As you can see from the Schematic and Source Listing, position pulses for the 2 servos are generated dirctly from the PIC.
Also, the room light level, battery condition, and servo power draw (indicating mechanical loading) can be measured with the internal A/D. The battery condition (although not yet in the software) can be determined by reading voltage accross the LED.
Since this voltage is (somewhat) constant, reading it actually measures the VCC to the PIC, which is where it gets its reference voltage. A higher reading on the LED means the battery voltage is lower. In its present state, this device powers up and measures the room light level then goes into low power mode (no power to servos, LED, or photo sensor) at 32 khz internal clock. About once a second, it 'wakes up' and checks the light level. If it finds a significant change, it cycles five steps forward, five steps back, and then shuts back down.
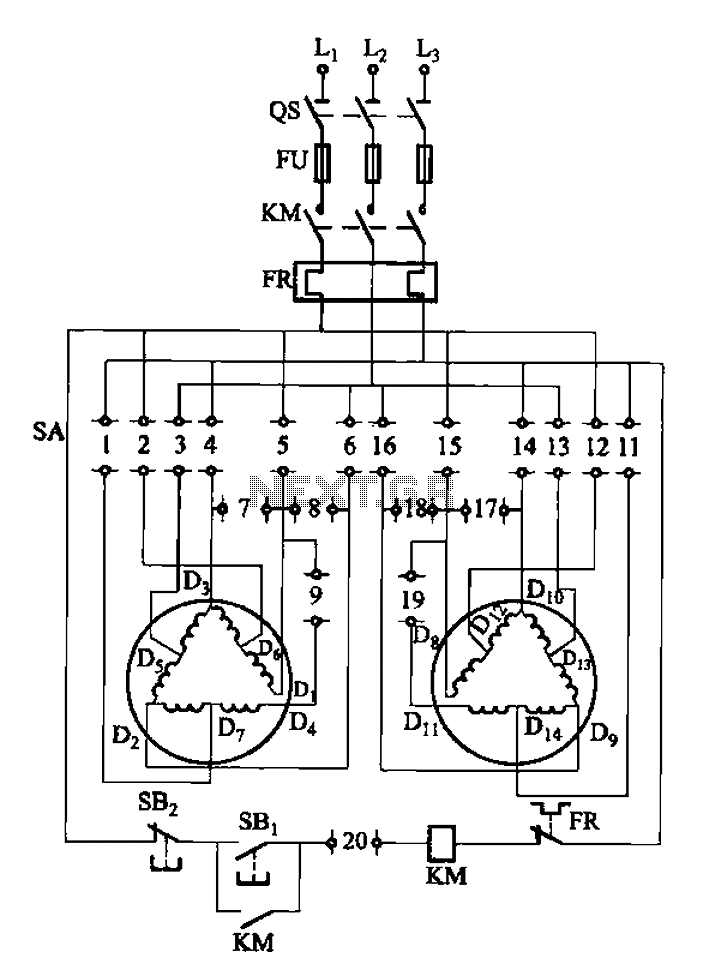
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
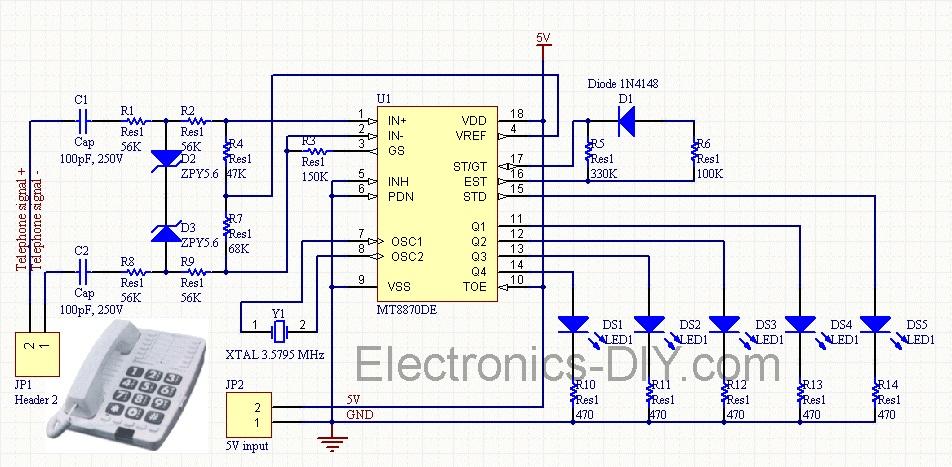
Cellphone Operated Land Rover (Mobile Phone Controlled Robot)
Cellphone Operated Land Rover (Mobile Phone Operated Robot). In this project, the robot is controlled by a mobile phone that makes a call to the mobile phone attached to the robot.
The cellphone operated Land Rover project involves the design and...
JavaBot1
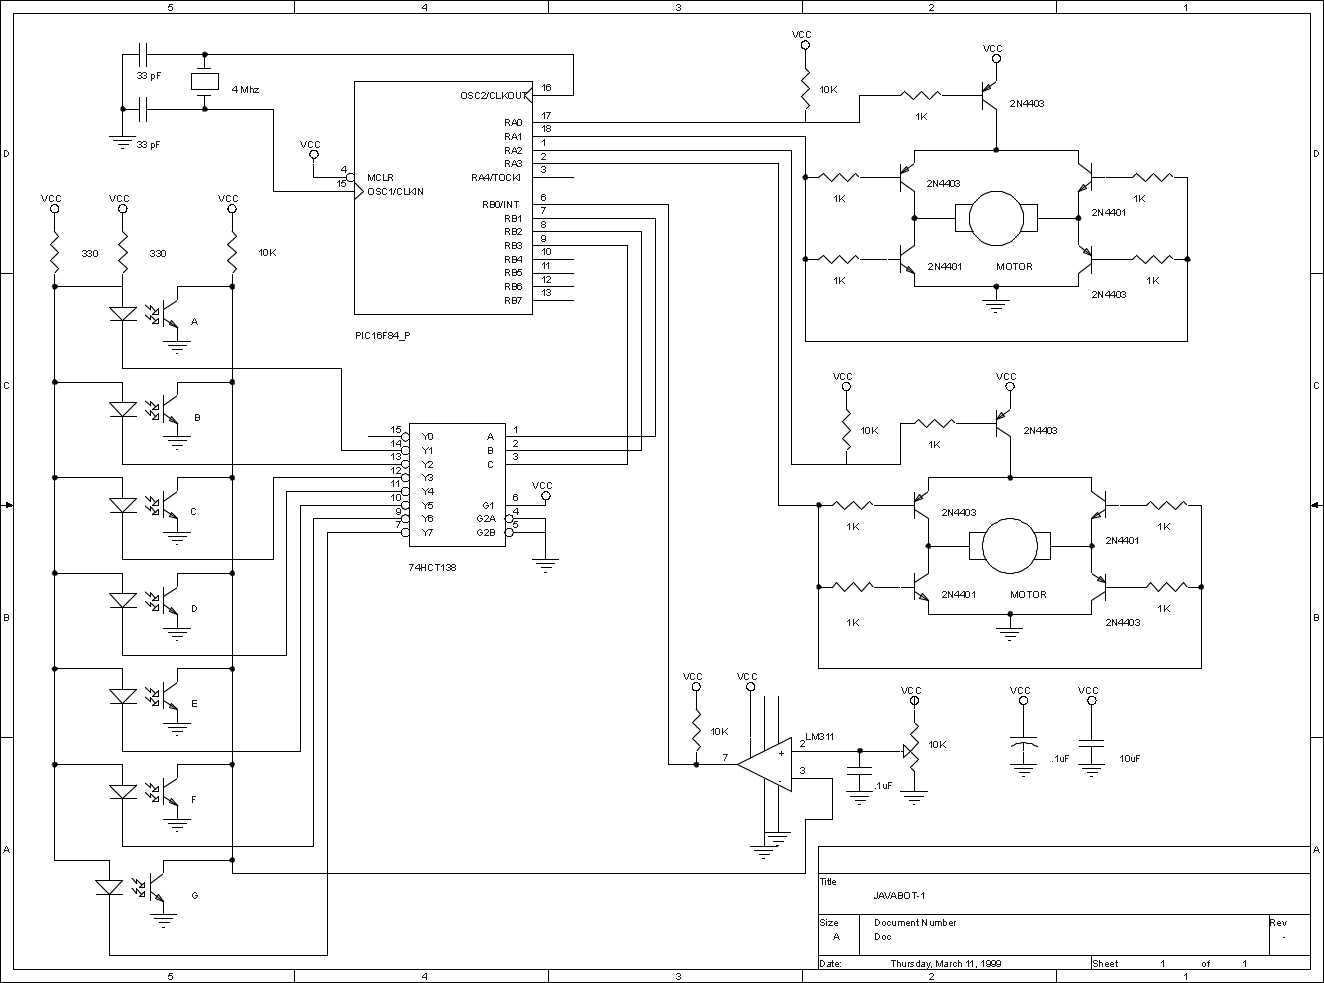
The JavaBot1 is a small line following robot designed to follow a black line drawn on a dry erase board. It is designed to follow very tight curves. The software still has lots of room for improvement but works well...
Direction and speed control
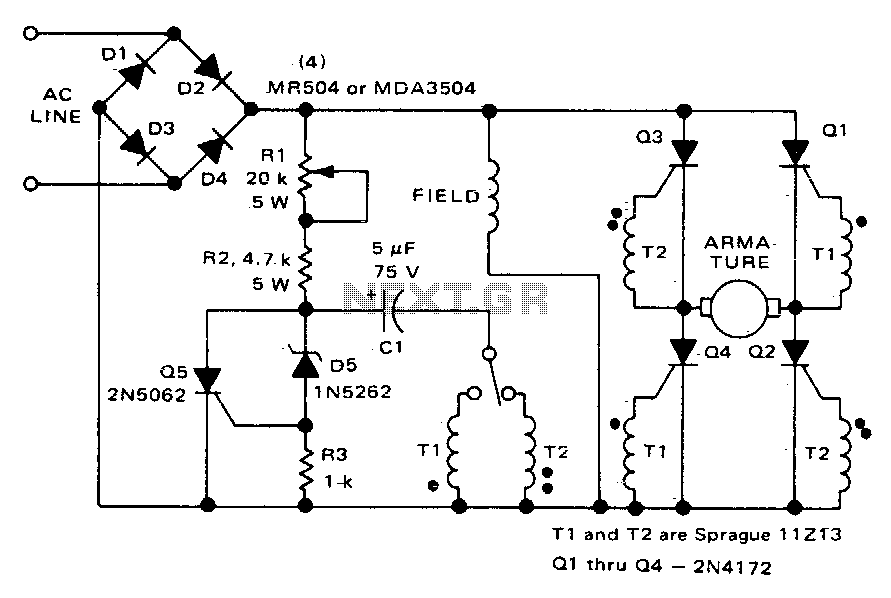
This circuit functions similarly to the one depicted in Fig. 57-4. The key differences include the placement of the field across the rectified supply and the armature being positioned within the SCR bridge. Therefore, the field current is unidirectional while...
fun robot line followers
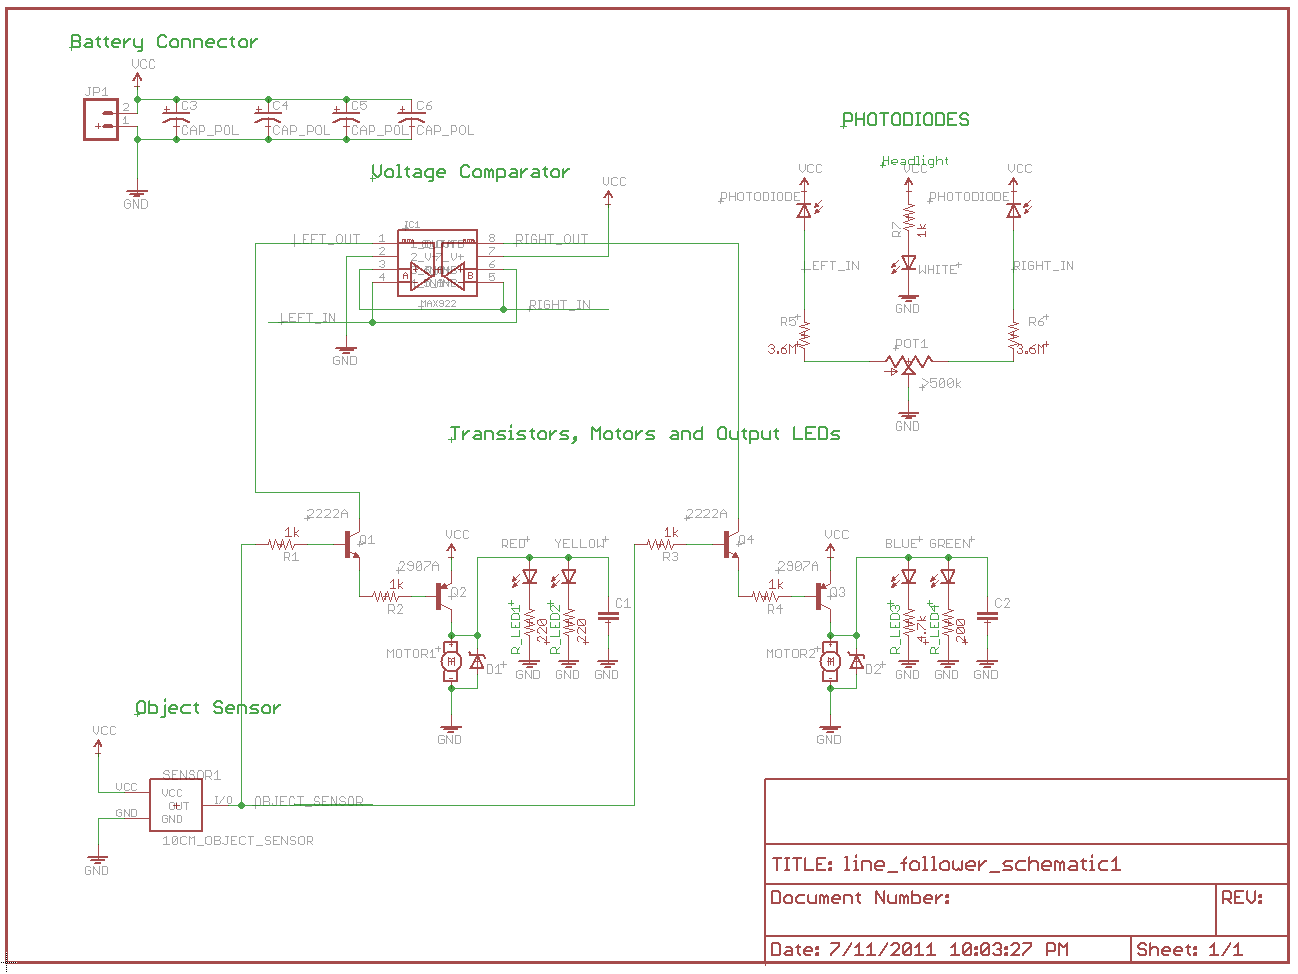
When new to electronics and lacking experience or direction, one book provided guidance on building interesting projects: "Robot Building for Beginners" by David Cook. In this book, Cook outlines the fundamental components and design considerations essential for constructing a simple...
Electronics Engineering Herald - online magazine of electronics -home
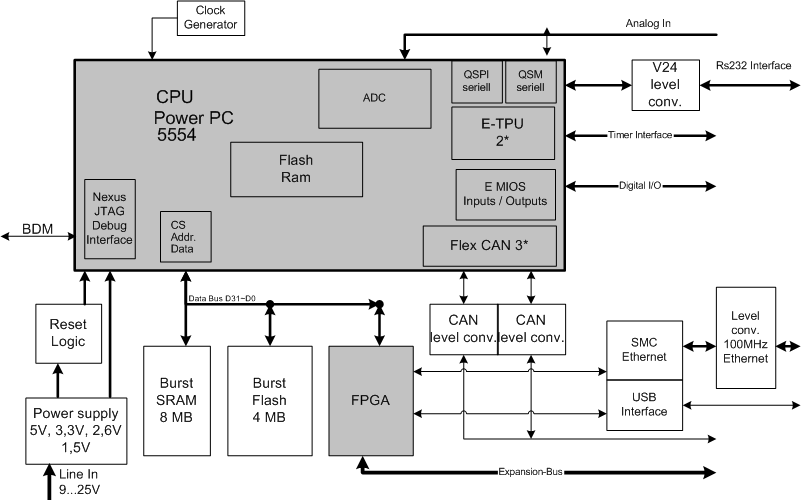
Embedded systems serve as the core of most electronics-based systems, enabling data access, processing, storage, and control. While some simple electronic circuits can be designed without a microprocessor or microcontroller, this approach is often economically impractical, except for basic passive...
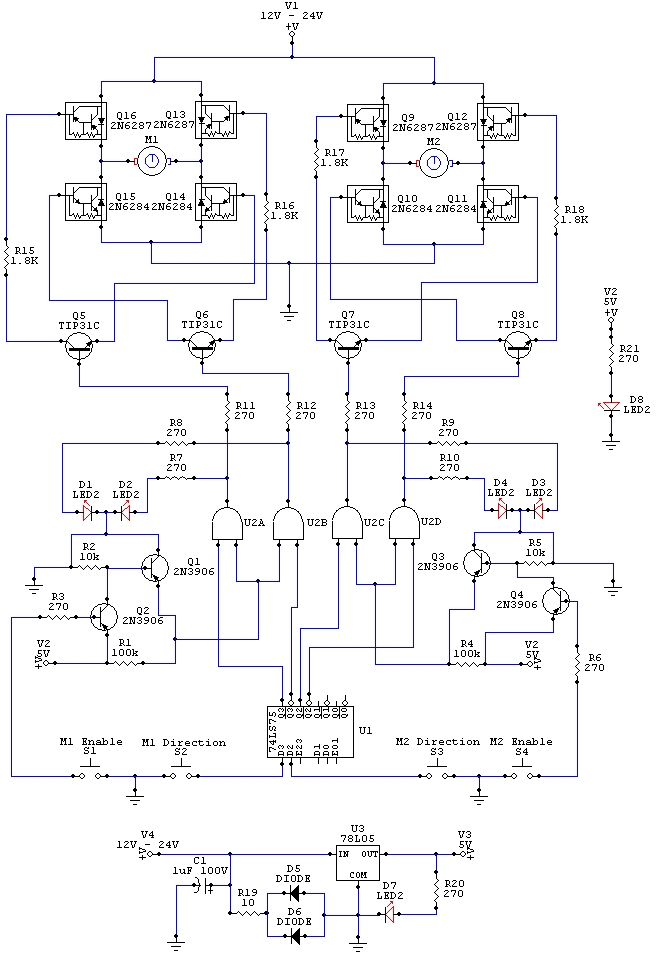
Electronic robot wiring schematic
The wiring schematic played a significant role in the robot. This diagram is used to graphically display all the wiring of the motor-controlling micro-components that enabled the robot to physically move forward, backward, left, right, and stop. This diagram was...
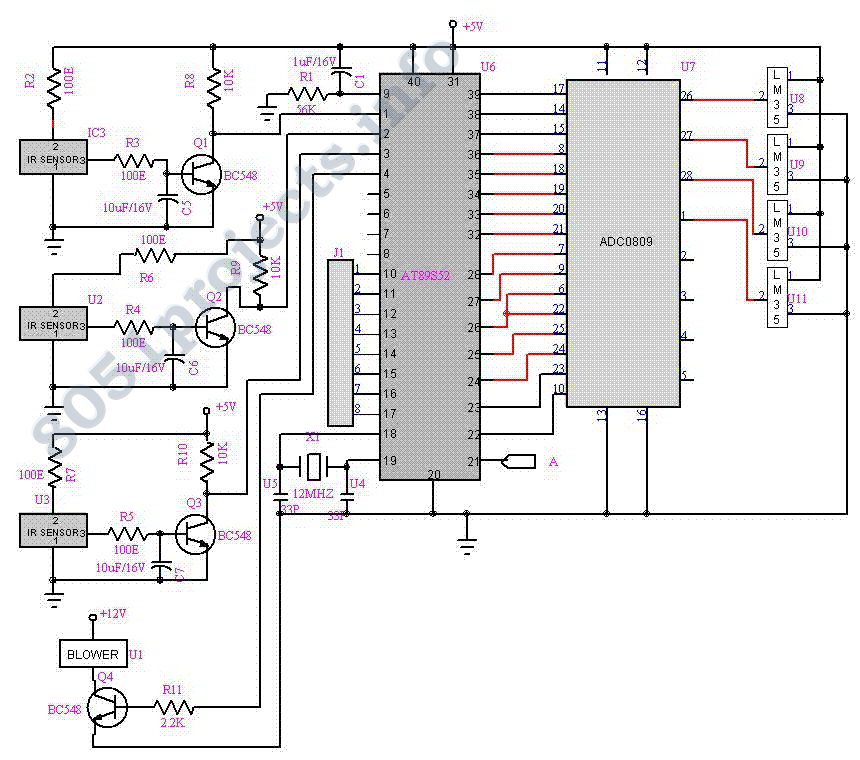
Fighting Robot circuit
The need for a device that can detect and extinguish a fire on its own is long past due. Many house fires originate when someone is either sleeping or not home. With the invention of such a device, people and...
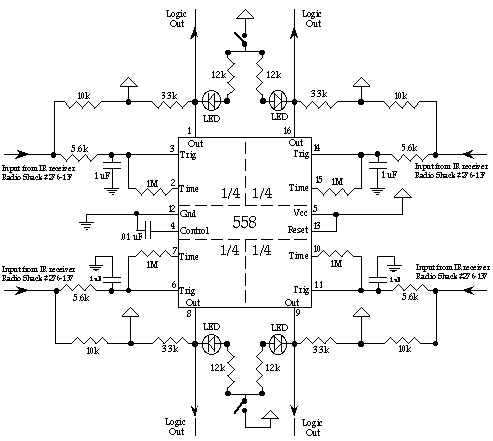
The Hoser Paper
A robot named "Wet Dream" was constructed to roam around, avoid collisions, locate people, and squirt them with an onboard motorized water gun. The robot was designed to maneuver in unstructured environments and react purposefully to various situations. "Wet Dream"...