
MCS08DZ60 Evaluation Board
#CAN transceiver
#RS232
#microcontroller
#debug
#GPIO
#evaluation board
#communication
#computer interface
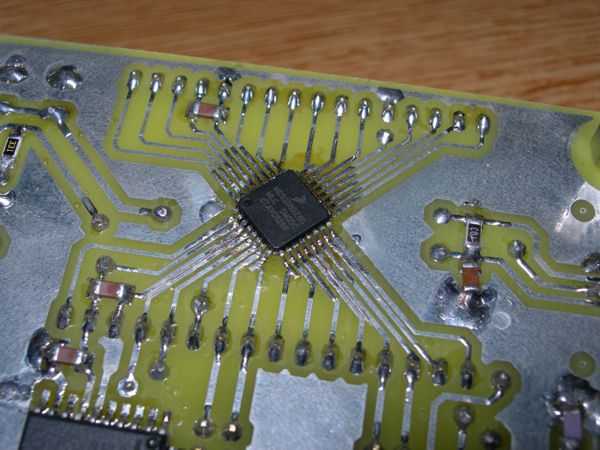
Description: The board has been initially developed to learn with CAN, so a CAN transceiver is available (IC4). The CAN transceiver comes from Maxim, but some other manufacturers provide some compatible CAN transceivers which can be used. An RS232 transceiver is also mounted on the board to get an RS232 interface, to connect the board to a computer. It could be used for debug purpose for example. Both transceivers are connected to the microcontroller through jumpers, so it is possible to disconnect the transceivers and use the pin of the microcontroller as classical GPIOs. The microcontroller used is the 68HCS08DZ60, from Freescale, and coming with an LQFP32 package. It is initially a microcontroller designed for automotive applications. It has some very interesting features:
- 60K of Flash memory;
The other parts of the schematic are not so special, we can find:
- The power supply, built around a DC/DC converter (IC1; a classical linear voltage regulator like 7805 can also be used without any modification of the PCB);
- A LED to indicate that the board is supplied (LED1);
- A switch connected on the RESET pin of the microcontroller (S1);
- The crystal (Q1). Note that the crystal is connected to the microcontroller through jumpers: the device can work with an internal clock and in this case, the pins are available as classical GPIOs.
- Finally, there are some decoupling capacitors for all integrated circuits.
The power of the board will be applied on K1. Any power supplied can be used if it provided between 8 to 12 Volts AC or DC. K2 will be used to connect the programming cable, and K3 gives access to all the pins of the microcontroller. K3 is built with two arrays of connectors to plug a module on the evaluation board (see photo #1).
- 4Ko of RAM;
- 2Ko of EEPROM;
- Integrated CAN bus controller;
- Integrated SCI controller with LIN capability;
- Integrated I2C controller;
- Integrated SPI controller;
- Analog inputs, with a resolution of 12bits;
- Timers which can generate PWM signals;
To program the microcontroller, a programming cable for Freescale HCS08 devices is required, along with CodeWarrior for Microcontrollers available from the Freescale website. This small evaluation board is easy to build and will enable numerous experimentations. Two boards can be made to create a small network through the CAN interface. This board is also suitable for developing applications around I²C, SPI, SCI, etc. The peripherals available on the 8-bit devices from Freescale are the same as those on the 16 and 32-bit devices, such as the Coldfire, making this board an excellent starting point for programming and learning with Freescale devices.
The evaluation board features a comprehensive layout designed for educational and prototyping purposes, emphasizing CAN communication. The CAN transceiver (IC4) enables the board to interface with other CAN devices, facilitating the development of automotive applications and networked systems. The RS232 transceiver provides a reliable means of connecting to computers for debugging and programming, enhancing the versatility of the board.
The microcontroller (68HCS08DZ60) is equipped with a robust set of features, including ample memory resources (60K Flash, 4K RAM, and 2K EEPROM) and various integrated communication protocols such as CAN, SCI, I²C, and SPI. These capabilities allow for a wide range of applications, from simple GPIO manipulation to more complex tasks involving data communication and control.
The power supply section of the board is designed to accommodate a variety of input voltages (8 to 12 Volts AC or DC), ensuring compatibility with different power sources. The use of a DC/DC converter (IC1) provides efficient voltage regulation, while the option to use a linear voltage regulator like the 7805 offers flexibility in power management.
Additional features, such as the onboard LED (LED1) for power indication, the reset switch (S1), and the crystal oscillator (Q1) with jumper options for clock configuration, contribute to the overall functionality and ease of use of the board. Decoupling capacitors are strategically placed to ensure stable operation of the integrated circuits, minimizing noise and potential interference.
The board's design facilitates easy access to the microcontroller's pins through K3, allowing for the connection of additional modules or components. This modular approach supports various experimentation scenarios, making the board a valuable tool for learning and development in embedded systems and microcontroller applications.The board has been initially developed to learn with CAN, so a CAN transceiver is available (IC4). The CAN transceiver comes from Maxim, but some other manufacturers provide some compatible CAN transceivers which can be used. An RS232 transceiver is also mounted on the board to get an RS232 interface, to connect the board to a computer.
It could be used for debug purpose for example. Both transceivers are connected to the microcontroller throw jumpers, so it is possible to disconnect the transceivers and use the pin of the microcontroller as classical GPIOs. The microcontroller used is the 68HCS08DZ60, from Freescale, and coming with an LQFP32 package. It is initially a microcontroller designed for automotive applications. It has some very interesting features: - 60K of Flash memory; The other parts of the schematic are not so special, we can found: - The power supply, build around a DC/DC converter (IC1 ; a classical linear voltage regulator like 7805 can also be used without any modification of the PCB); - A LED to indicate that the board is supplied (LED1); - A switch connected on the RESET pin of the microcontroller (S1); - The crystal (Q1). Note that the crystal is connected to the microcontroller throw jumpers: the device can work with an internal clock and in this case, the pins are available as classical GPIOs.
- Finally, there are some decoupling capacitors for all integrated circuits. The power of the board will be applied on K1. Any power supplied can be used if it provided between 8 to 12 Volts AC or DC. K2 will be used to connect the programming cable, and K3 gives an access to all the pins of the microcontroller. K3 is build with two arrays of connectors to plug a module on the evaluation board (see photo #1). - 4Ko of RAM; - 2Ko of EEPROM ; - Integrated CAN bus controller; - Integrated SCI controller with LIN capability; - Integrated I2C controller; - Integrated SPI controller; - Analog inputs, with a resolution of 12bits; - Timers which can generated PWM signals; To program the microcontroller, you will need a programming cable for Freescale HCS08 devices and you will have to download CodeWarrior for Microcontrollers from Freescale Web Site.
This small evaluation board is easy to build and will enable lots of experimentations. I have make two boards in order to create a small network throw the CAN interface. Of course this board is also interesting if you want to develop application around I²C, SPI, SCI... Remember that the peripherals available on the 8bits devices from Freescale are the same than on the 16 and 32bits devices, like the Coldfire for example. It is why this board is maybe the best way to start programming and learning with Freescale devices.
- 60K of Flash memory;
The other parts of the schematic are not so special, we can find:
- The power supply, built around a DC/DC converter (IC1; a classical linear voltage regulator like 7805 can also be used without any modification of the PCB);
- A LED to indicate that the board is supplied (LED1);
- A switch connected on the RESET pin of the microcontroller (S1);
- The crystal (Q1). Note that the crystal is connected to the microcontroller through jumpers: the device can work with an internal clock and in this case, the pins are available as classical GPIOs.
- Finally, there are some decoupling capacitors for all integrated circuits.
The power of the board will be applied on K1. Any power supplied can be used if it provided between 8 to 12 Volts AC or DC. K2 will be used to connect the programming cable, and K3 gives access to all the pins of the microcontroller. K3 is built with two arrays of connectors to plug a module on the evaluation board (see photo #1).
- 4Ko of RAM;
- 2Ko of EEPROM;
- Integrated CAN bus controller;
- Integrated SCI controller with LIN capability;
- Integrated I2C controller;
- Integrated SPI controller;
- Analog inputs, with a resolution of 12bits;
- Timers which can generate PWM signals;
To program the microcontroller, a programming cable for Freescale HCS08 devices is required, along with CodeWarrior for Microcontrollers available from the Freescale website. This small evaluation board is easy to build and will enable numerous experimentations. Two boards can be made to create a small network through the CAN interface. This board is also suitable for developing applications around I²C, SPI, SCI, etc. The peripherals available on the 8-bit devices from Freescale are the same as those on the 16 and 32-bit devices, such as the Coldfire, making this board an excellent starting point for programming and learning with Freescale devices.
The evaluation board features a comprehensive layout designed for educational and prototyping purposes, emphasizing CAN communication. The CAN transceiver (IC4) enables the board to interface with other CAN devices, facilitating the development of automotive applications and networked systems. The RS232 transceiver provides a reliable means of connecting to computers for debugging and programming, enhancing the versatility of the board.
The microcontroller (68HCS08DZ60) is equipped with a robust set of features, including ample memory resources (60K Flash, 4K RAM, and 2K EEPROM) and various integrated communication protocols such as CAN, SCI, I²C, and SPI. These capabilities allow for a wide range of applications, from simple GPIO manipulation to more complex tasks involving data communication and control.
The power supply section of the board is designed to accommodate a variety of input voltages (8 to 12 Volts AC or DC), ensuring compatibility with different power sources. The use of a DC/DC converter (IC1) provides efficient voltage regulation, while the option to use a linear voltage regulator like the 7805 offers flexibility in power management.
Additional features, such as the onboard LED (LED1) for power indication, the reset switch (S1), and the crystal oscillator (Q1) with jumper options for clock configuration, contribute to the overall functionality and ease of use of the board. Decoupling capacitors are strategically placed to ensure stable operation of the integrated circuits, minimizing noise and potential interference.
The board's design facilitates easy access to the microcontroller's pins through K3, allowing for the connection of additional modules or components. This modular approach supports various experimentation scenarios, making the board a valuable tool for learning and development in embedded systems and microcontroller applications.The board has been initially developed to learn with CAN, so a CAN transceiver is available (IC4). The CAN transceiver comes from Maxim, but some other manufacturers provide some compatible CAN transceivers which can be used. An RS232 transceiver is also mounted on the board to get an RS232 interface, to connect the board to a computer.
It could be used for debug purpose for example. Both transceivers are connected to the microcontroller throw jumpers, so it is possible to disconnect the transceivers and use the pin of the microcontroller as classical GPIOs. The microcontroller used is the 68HCS08DZ60, from Freescale, and coming with an LQFP32 package. It is initially a microcontroller designed for automotive applications. It has some very interesting features: - 60K of Flash memory; The other parts of the schematic are not so special, we can found: - The power supply, build around a DC/DC converter (IC1 ; a classical linear voltage regulator like 7805 can also be used without any modification of the PCB); - A LED to indicate that the board is supplied (LED1); - A switch connected on the RESET pin of the microcontroller (S1); - The crystal (Q1). Note that the crystal is connected to the microcontroller throw jumpers: the device can work with an internal clock and in this case, the pins are available as classical GPIOs.
- Finally, there are some decoupling capacitors for all integrated circuits. The power of the board will be applied on K1. Any power supplied can be used if it provided between 8 to 12 Volts AC or DC. K2 will be used to connect the programming cable, and K3 gives an access to all the pins of the microcontroller. K3 is build with two arrays of connectors to plug a module on the evaluation board (see photo #1). - 4Ko of RAM; - 2Ko of EEPROM ; - Integrated CAN bus controller; - Integrated SCI controller with LIN capability; - Integrated I2C controller; - Integrated SPI controller; - Analog inputs, with a resolution of 12bits; - Timers which can generated PWM signals; To program the microcontroller, you will need a programming cable for Freescale HCS08 devices and you will have to download CodeWarrior for Microcontrollers from Freescale Web Site.
This small evaluation board is easy to build and will enable lots of experimentations. I have make two boards in order to create a small network throw the CAN interface. Of course this board is also interesting if you want to develop application around I²C, SPI, SCI... Remember that the peripherals available on the 8bits devices from Freescale are the same than on the 16 and 32bits devices, like the Coldfire for example. It is why this board is maybe the best way to start programming and learning with Freescale devices.
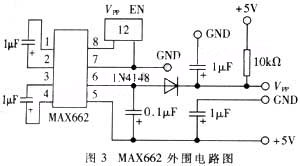
The embedded microcontroller MC68HC912B32 background debugs the mode to design
The widespread application of Flash technology in microprocessors has led to significant advancements in the development and utilization of one-chip computers. Designers have transitioned from traditional in-circuit emulators (ICE) and JTAG interfaces to more cost-effective and user-friendly development methods. While...
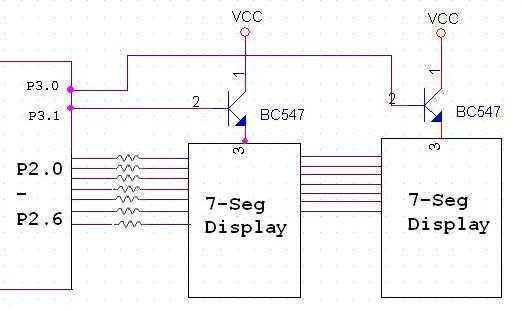
Interfacing seven segment to microcontroller
The Tutorial shows how to interface 7-segment display to a microcontroller. Also explains how do display more than one 7-segment on same data lines using scanning method. 7 Seg displays are are basically 7 LED's. It will be much easier...
Microcontroller
The gap between TTL (Transistor-Transistor Logic) devices and personal computers can be effectively bridged with modern microcontrollers. These microcontrollers not only incorporate a central processing unit (CPU) but also include program and data memory, EEPROM, input/output (I/O) ports, timers, and...
Simple RS 232 Level Converter
When connecting a microcontroller project to a COM port on a PC, an RS-232 converter is required. Various chips can accomplish this task, such as the MAX232 and DS275. However, for a simple and cost-effective RS-232 converter, the following circuit...
Miniature Real-time Controller
This is my long history the device that controls my home's night light, air-conditioner, etc. The device is a Miniature Real-time Controller. The circuit uses only three chips, a 89C2051, DS275 (or MAX232), and 74LS07 open collector driver. The scheduler...
DC motor driver for DCMP(AVR-008)
A microcontroller is used to control various types of DC motors, including permanent magnet DC motors, DC servo motors, and stepper motors. This project utilizes the AVR-008 microcontroller from Circuits-Home, which is frequently referred to as the 3-in-1 driver motor...
Multitasking Pins
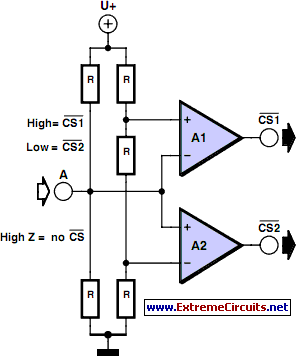
It is entirely logical that low-cost miniature microcontrollers have fewer pins than their larger counterparts, sometimes too few. Consideration has been given to how to economize on pins by making them perform multiple functions. One approach is to exploit the...
microcontroller led interfacing
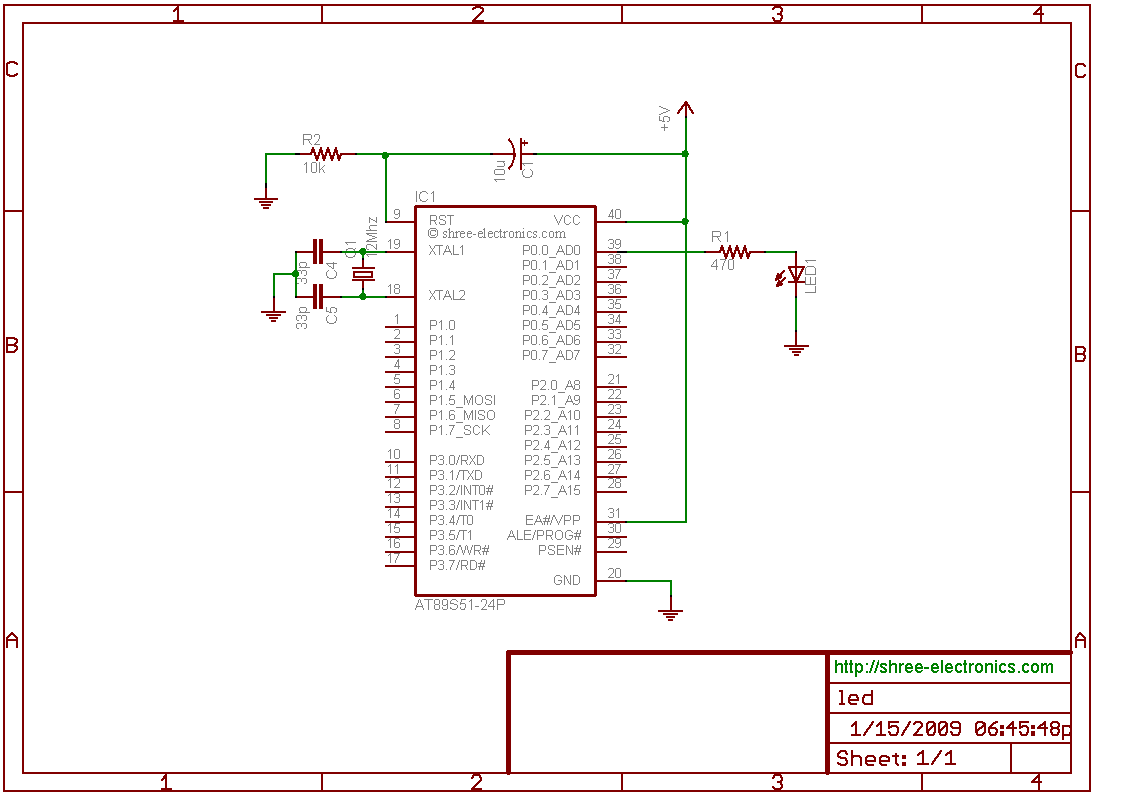
The initial step often taken when learning about any microcontroller or embedded system is to make an LED blink. The circuit presented below illustrates the setup for interfacing an LED. Note: Due to the large dimensions of the circuit diagram,...
RS232 Connections wiring up
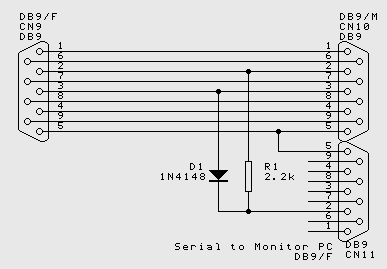
While the normal PC hardware might well run with just Tx, Rx and Ground connected, most driver software will wait forever for one of the handshaking lines to go to the correct level. Depending on the signal state it might...