
circuit explanation of stepper motor
#stepper motor
#Darlington transistor
#transistor driver
#coil drive
#hfe
#2SD1209K
#motor control
#high gain
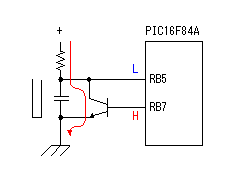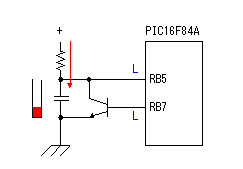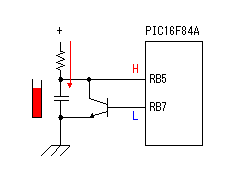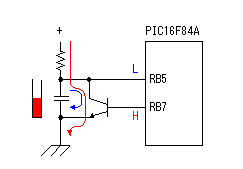
Description: A Darlington connection-type transistor is utilized for driving the coil. In this configuration, two stages of transistors are connected in series, resulting in a high current gain, where the "hfe" of the Darlington transistor is the product of the "hfe" values of the individual transistors. The 2SD1209K transistor used in this application has an hfe greater than 4000. This configuration allows for a significant increase in output current, enabling sharp rising and falling edges of the control signal. A diode is placed between the collector and the power supply for transistor protection. When the transistor switches from ON to OFF, the motor coil attempts to continue the current flow, generating a high voltage. The diode conducts this voltage, preventing high voltage damage to the transistor. TR1 is activated when RB7 reaches a high level. In this state, the charge from capacitor C1 flows through the transistor, causing the voltage across the capacitor to approach 0 V. When RB7 goes low, the transistor turns OFF, allowing current to flow through VR1 and R4 to charge capacitor C1. The voltage across the capacitor increases gradually during charging, as described in the "Integration circuit." The voltage on the capacitor is monitored by RB5. The PIC's software interrupts motor control until it verifies that RB5 has transitioned to high after RB7 goes low. Reducing the value of VR1 shortens the capacitor charging time, resulting in faster motor control, while increasing VR1 slows it down. The speed control range can be adjusted by varying the capacitor value. This circuit facilitates clockwise and counterclockwise motor rotation or stopping. A non-locking pushbutton switch is employed, with a pull-up resistor ensuring the port reads high when the switch is OFF. The RB port of the PIC16F84A features an internal pull-up capability; however, since RB5 is used for capacitor voltage detection, the internal pull-up is not utilized. If the RA port were used for voltage detection, the internal pull-up could be employed. The circuit includes an external pull-up resistor based on the design pattern. The stepper motor operates at approximately 5V, requiring a power supply voltage of +5V. Due to a voltage drop of about 1V across the regulator, the voltage supplied to the PIC is slightly below 5V. For the PIC16F84A, operation is still feasible down to about 3V, as its operating voltage range is from 2V to 5.5V, making it suitable for a 100-mA type application.
The Darlington transistor configuration is particularly advantageous in applications requiring high current gain and fast switching capabilities. The series connection of two transistors allows for the amplification of input signals, making it suitable for driving inductive loads such as coils in motors. The use of the 2SD1209K transistor with an hfe of over 4000 ensures that even small input currents can effectively drive larger output currents, which is essential for applications involving motor control.
In the described circuit, the integration of the capacitor C1 plays a crucial role in controlling the timing of the motor operation. The charging and discharging characteristics of the capacitor can be manipulated by adjusting the resistor values, specifically VR1. This flexibility allows for precise control over the motor's speed and responsiveness, which is vital in applications requiring accurate positioning or speed modulation.
The protection diode serves a critical function by safeguarding the transistor against back EMF generated by the motor coil during switching events. This back EMF can cause voltage spikes that may exceed the transistor's maximum ratings, potentially leading to failure. By ensuring that the diode conducts during these events, the circuit maintains reliability and longevity.
The choice of a non-locking pushbutton switch adds to the user-friendliness of the circuit, allowing for simple control of the motor's operation without the need for complex mechanical latching mechanisms. The inclusion of external pull-up resistors is a common practice in digital circuits to ensure that inputs are not left floating, which could lead to unpredictable behavior.
Overall, this circuit design exemplifies efficient motor control through the careful selection of components and configuration, allowing for versatile operation in various applications. The integration of a microcontroller such as the PIC16F84A enhances the circuit's capabilities by enabling programmable control, further expanding its potential uses in automated systems.Darlington connection-type transistor is used for the drive of the coil. As for the Darlington connection, 2 stages of transistors are connected inside in series. The "hfe" of this transistor is the multiplication of the "hfe" of each transistor inside. In case of 2SD1209K which was used this time, the hfe is over 4000. Because the ratio of the in put electric current and the output current is big, the rising edge and the falling edge of the control signal can be made sharp. The diode to be putting between the collector and the power is for the protection of the transistor. When the transistor becomes OFF from ON, the coil of the motor tries to continue to pass an electric current and generates high voltage.
An electric current by this voltage is applied to the diode and the high voltage which applies over the transistor is prevented. TR1 becomes ON condition when RB7 becomes H level. In this condition, the electric charge of capacitor C1 flows through the transistor and the voltage of the both edges of the capacitor becomes 0 V almost.
When RB7 becomes an L level, the transistor becomes OFF condition. In this condition, the electric current flows through VR1 and R4 into capacitor C1 and the charging to the capacitor begins. The voltage of the both edges of the capacitor becomes high gradually as charging is done. As for the change of this voltage, refer to "Integration circuit". The voltage of the capacitor is detected by RB5. The software of PIC interrupts the control of the motor until it checks RB5 after making RB7 an L level and RB5 becomes H level.
When making the value of VR1 small, the charging time of the capacitor is short and the control of the motor becomes quick. The control of the motor becomes slow when making VR1 big. The speed control range can be changed by changing the value of the capacitor. This is the circuit for the clockwise rotating, the counterclockwise rotating or stopping a motor. The baton switch of the non lock is used. Pull-up resistor is used for the port to become H level when the switch is OFF. The RB port of PIC16F84A has an internal pull up feature. However, because RB5 is used for the voltage detection of the capacitor at the circuit this time, an internal pull up feature isnt used.
If using RA port for the voltage detection of the capacitor, the RB internal pull up feature can be used. The circuit this time put an external pull-up resistor in the relation of the pattern. Because the operating voltage of the stepper motor to be using this time is about 5V, the power supply voltage is +5V.
In this case, the voltage which is applied to PIC becomes less than 5V because of the voltage drop (about 1V) of the regulator. In case of PIC16F84A, the operation is possible even if the power falls to about 3V because the operating voltage range is from 2V to 5.
5V. It is enough in the 100-mA type.
The Darlington transistor configuration is particularly advantageous in applications requiring high current gain and fast switching capabilities. The series connection of two transistors allows for the amplification of input signals, making it suitable for driving inductive loads such as coils in motors. The use of the 2SD1209K transistor with an hfe of over 4000 ensures that even small input currents can effectively drive larger output currents, which is essential for applications involving motor control.
In the described circuit, the integration of the capacitor C1 plays a crucial role in controlling the timing of the motor operation. The charging and discharging characteristics of the capacitor can be manipulated by adjusting the resistor values, specifically VR1. This flexibility allows for precise control over the motor's speed and responsiveness, which is vital in applications requiring accurate positioning or speed modulation.
The protection diode serves a critical function by safeguarding the transistor against back EMF generated by the motor coil during switching events. This back EMF can cause voltage spikes that may exceed the transistor's maximum ratings, potentially leading to failure. By ensuring that the diode conducts during these events, the circuit maintains reliability and longevity.
The choice of a non-locking pushbutton switch adds to the user-friendliness of the circuit, allowing for simple control of the motor's operation without the need for complex mechanical latching mechanisms. The inclusion of external pull-up resistors is a common practice in digital circuits to ensure that inputs are not left floating, which could lead to unpredictable behavior.
Overall, this circuit design exemplifies efficient motor control through the careful selection of components and configuration, allowing for versatile operation in various applications. The integration of a microcontroller such as the PIC16F84A enhances the circuit's capabilities by enabling programmable control, further expanding its potential uses in automated systems.Darlington connection-type transistor is used for the drive of the coil. As for the Darlington connection, 2 stages of transistors are connected inside in series. The "hfe" of this transistor is the multiplication of the "hfe" of each transistor inside. In case of 2SD1209K which was used this time, the hfe is over 4000. Because the ratio of the in put electric current and the output current is big, the rising edge and the falling edge of the control signal can be made sharp. The diode to be putting between the collector and the power is for the protection of the transistor. When the transistor becomes OFF from ON, the coil of the motor tries to continue to pass an electric current and generates high voltage.
An electric current by this voltage is applied to the diode and the high voltage which applies over the transistor is prevented. TR1 becomes ON condition when RB7 becomes H level. In this condition, the electric charge of capacitor C1 flows through the transistor and the voltage of the both edges of the capacitor becomes 0 V almost.
When RB7 becomes an L level, the transistor becomes OFF condition. In this condition, the electric current flows through VR1 and R4 into capacitor C1 and the charging to the capacitor begins. The voltage of the both edges of the capacitor becomes high gradually as charging is done. As for the change of this voltage, refer to "Integration circuit". The voltage of the capacitor is detected by RB5. The software of PIC interrupts the control of the motor until it checks RB5 after making RB7 an L level and RB5 becomes H level.
When making the value of VR1 small, the charging time of the capacitor is short and the control of the motor becomes quick. The control of the motor becomes slow when making VR1 big. The speed control range can be changed by changing the value of the capacitor. This is the circuit for the clockwise rotating, the counterclockwise rotating or stopping a motor. The baton switch of the non lock is used. Pull-up resistor is used for the port to become H level when the switch is OFF. The RB port of PIC16F84A has an internal pull up feature. However, because RB5 is used for the voltage detection of the capacitor at the circuit this time, an internal pull up feature isnt used.
If using RA port for the voltage detection of the capacitor, the RB internal pull up feature can be used. The circuit this time put an external pull-up resistor in the relation of the pattern. Because the operating voltage of the stepper motor to be using this time is about 5V, the power supply voltage is +5V.
In this case, the voltage which is applied to PIC becomes less than 5V because of the voltage drop (about 1V) of the regulator. In case of PIC16F84A, the operation is possible even if the power falls to about 3V because the operating voltage range is from 2V to 5.
5V. It is enough in the 100-mA type.
Stepper Motor Control Circuit
This circuit is not visually appealing nor easy to implement, requiring considerable effort. The stepper motor consists of two coils, necessitating the use of two LMD18245 chips to manage the current flow through these coils. It is noteworthy that motor...
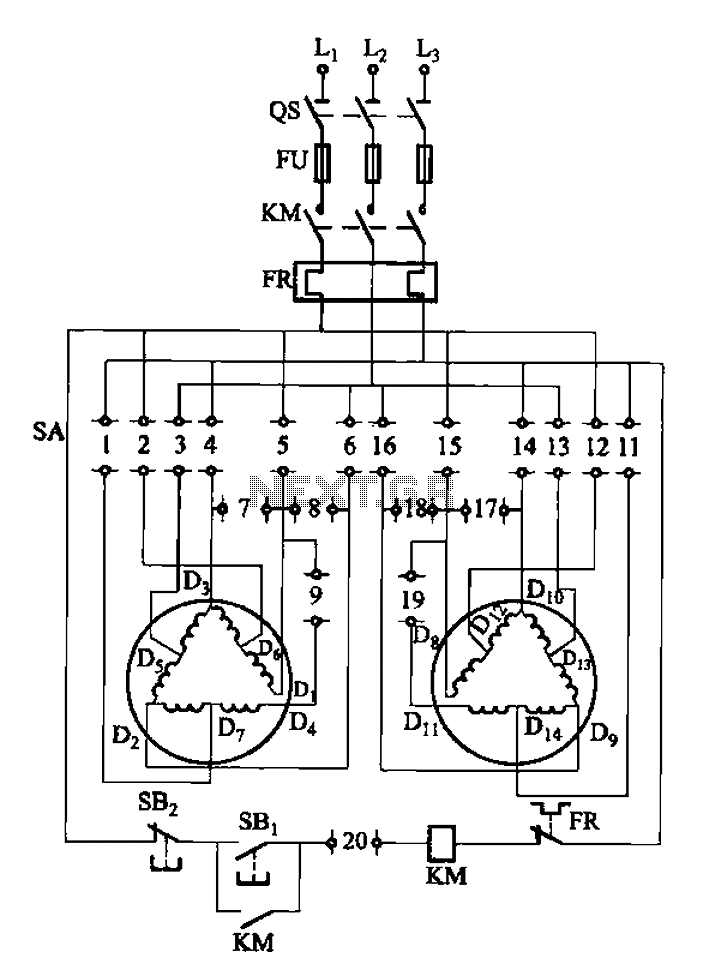
2Y-Y-2 - connection four-speed motor switch control circuit
The 3-119 circuit shown in the figure combines switch SA to realize the stator windings, specifically the 2, Y, and 2Y connections, which correspond to the motor speed n1.
The 3-119 circuit is designed to facilitate the control of motor speed...
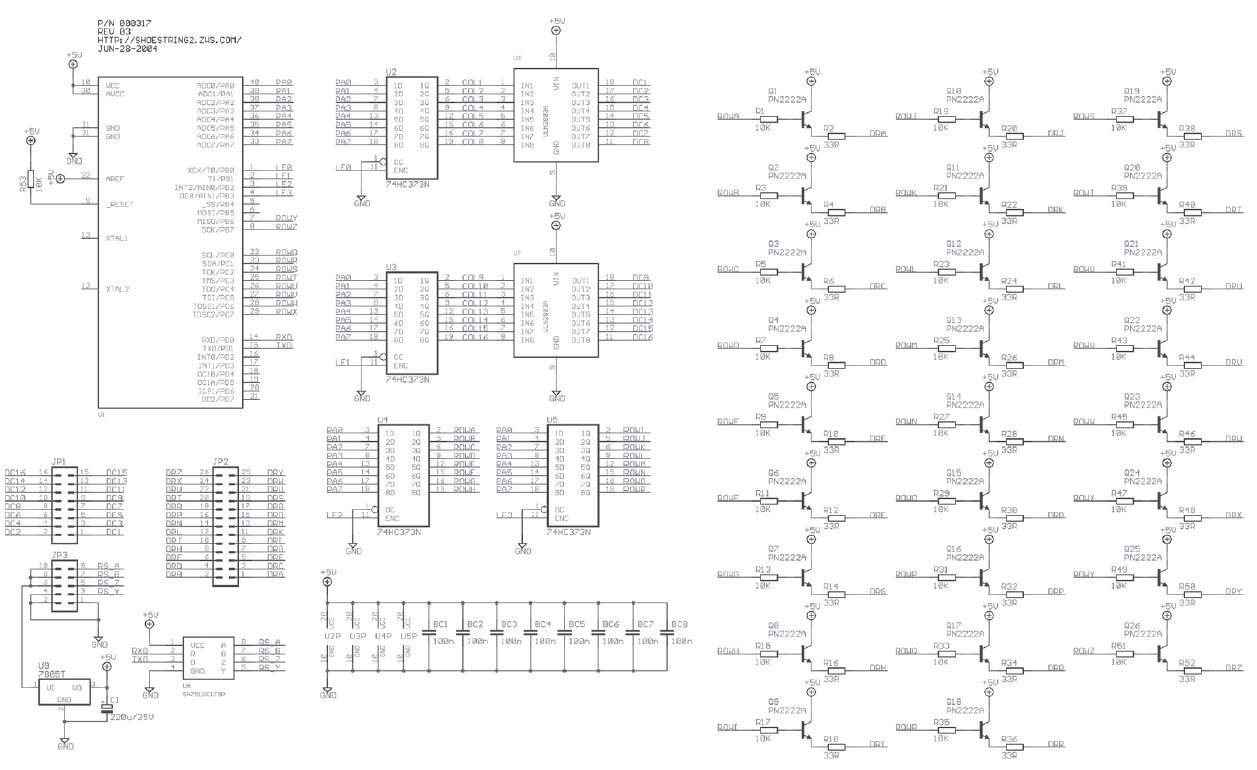
RS 422 Compatible Indicator
The design involves creating a circuit and programming for a stepper motor controller, developing a speed-controlled DC motor circuit for the propulsion system of the project, and designing a navigation system using a MEMS accelerometer circuit. This section deviates slightly...
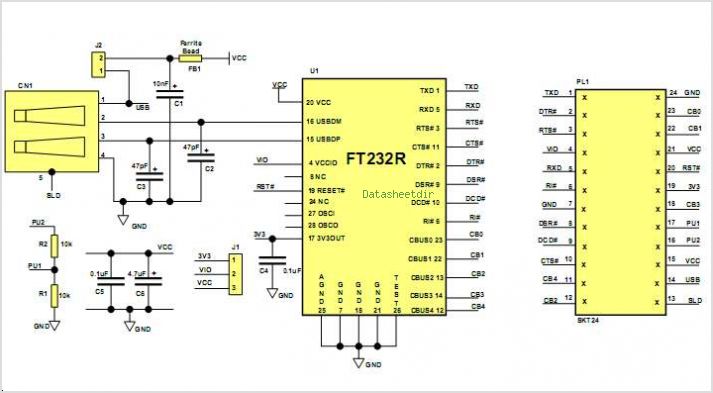
Um232r Usb- Serial Uart Development Module
Stepper motors with unipolar drives are commonly utilized in applications that demand high torque and rapid positioning. The unipolar operation facilitates stable motor control through relatively simple firmware compared to bipolar drives. This application note examines the use of a...
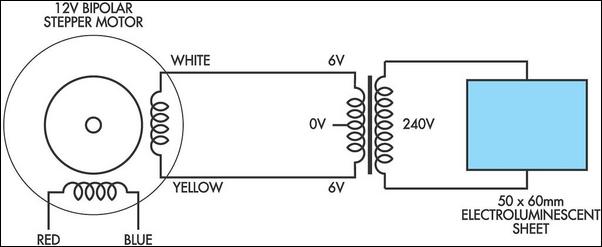
Luminescent Generator
When spun quickly between the fingers, a bipolar stepper motor generates approximately 10VAC. By utilizing a small transformer rated for 240V to 6-0-6V in reverse (with series-connected secondaries), a small bipolar stepper motor can effectively power a standard luminescent sheet...
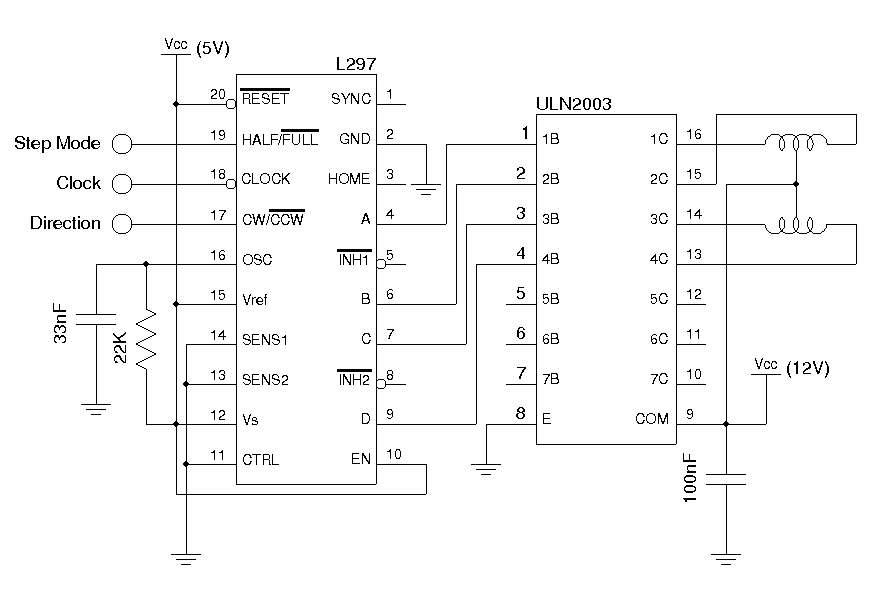
A Unipolar Stepper Motor Driver
The drive circuits for unipolar stepper motors are typically straightforward. In their simplest configuration, a transistor or MOSFET is employed to control each section of the windings. The control signal must be supplied programmatically to the four windings of the...
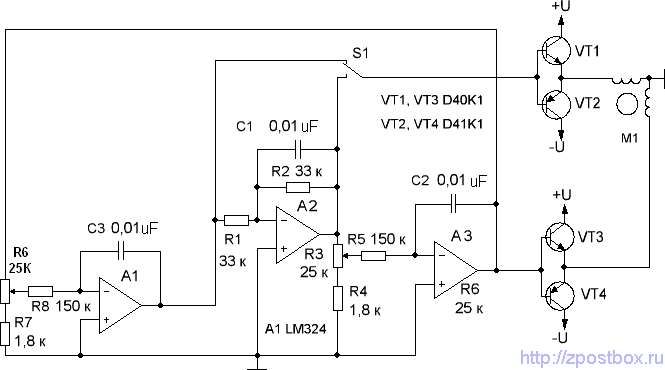
Bipolar stepper motor driver circuit diagram
This circuit generates the power required to operate a bipolar stepper motor. It allows for adjustments in both the rotation speed and direction of the motor. The design includes two integrator circuits (A1, A3) and an amplifier (A2) connected in...
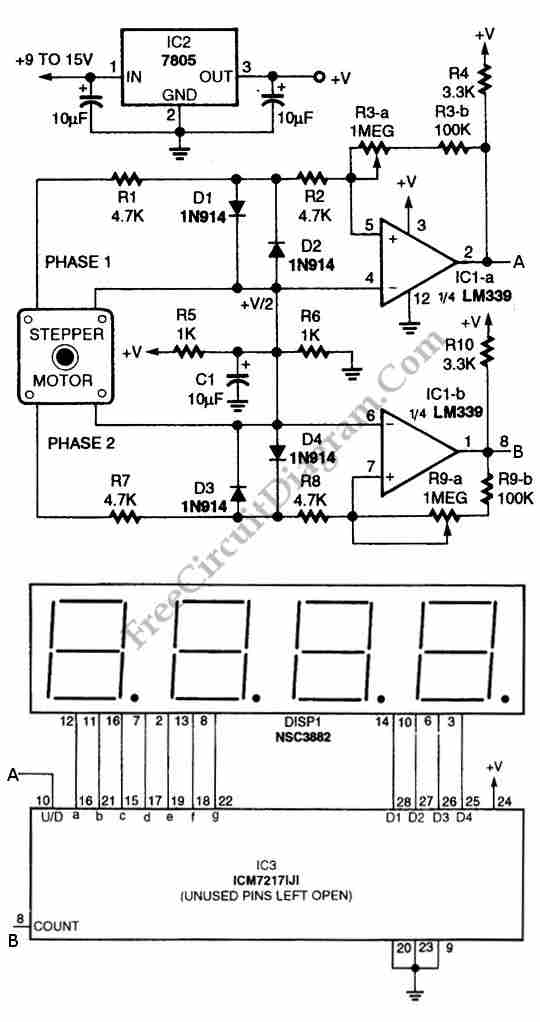
Digital Encoder Circuit Using Stepper Motor
The circuit illustrated in the schematic diagram below allows for the visualization of the direction and shaft rotation of a stepper motor on an LED display. Instead of employing a digital rotation encoder as an input, this circuit utilizes a...
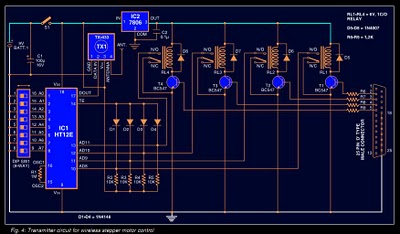
PC Based Wireless Stepper Motor control Circuit PCB
Stepper motors are widely used in applications such as process control, machine tools, and robotics. In particular, remote control of stepper motors is essential in robotics and process control. This document provides the circuit diagrams for both the transmitter and...