
Efficient-switching-controller
#switching controller
#servo motor
#transistor bridge
#dynamic braking
#low-power
#efficient
#heat dissipation
#reversing switch
#single-ended power supply
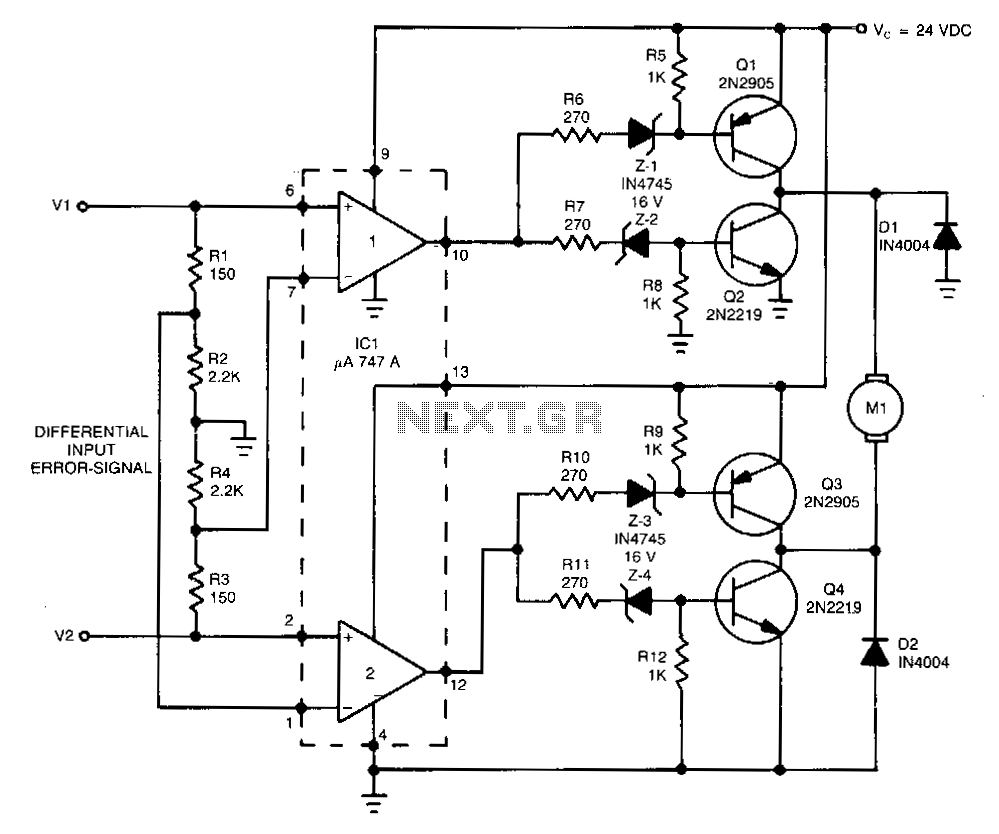
Description: This high-performance switching controller for a low-power DC servo motor utilizes a symmetrical complementary-transistor bridge. The bridge functions as a reversing switch between the motor and a single-ended power supply. Because the transistors operate in a fully on or fully off state, except for a very brief transition period, significantly less heat is dissipated compared to linear amplifier circuits. The circuit's inherent dynamic braking provides damping. Additionally, since either maximum or zero voltage is applied to the motor, the dynamic response is quicker than that of linear servo drives.
The switching controller is designed to enhance the efficiency and responsiveness of low-power DC servo motors. The symmetrical complementary-transistor bridge configuration consists of four transistors arranged in a manner that allows for bidirectional control of the motor. This arrangement enables the application of voltage in either direction, facilitating smooth acceleration and deceleration of the motor.
In operation, when a control signal is applied, the transistors switch between their on and off states, rapidly changing the voltage across the motor. This rapid switching minimizes the time the transistors spend in their transition state, thereby reducing heat generation and improving overall efficiency. The use of a single-ended power supply simplifies the design and reduces costs while still delivering adequate power to the motor.
The inherent dynamic braking feature is a critical aspect of this design. When the control signal is removed or reversed, the transistors quickly switch off, allowing the motor to decelerate rapidly due to the back EMF generated. This not only improves response times but also enhances the overall control of the motor, making it suitable for applications requiring precise positioning and speed control.
Moreover, the faster dynamic response achieved through this switching method is a significant advantage over traditional linear servo drives. By applying maximum or zero voltage directly to the motor, the controller can achieve rapid changes in speed and direction, making it ideal for applications in robotics, automation, and other precision control systems. This design approach ultimately leads to improved performance, reduced energy consumption, and increased longevity of the servo motor.This high-performance switching controller for a low-power de servo motor uses a symmetrical complementary- transistor bridge. The bridge acts as a reversing switch between the motor and a single-ended power supply. Since the transistors operate either fully on or completely off, except during a very short transition period, much less heat is dissipated than in linear-amplifier circuits.
Damping is provided by the circuit"s inherent dynamic braking. Since either maximum or zero voltage is applied to the motor, the dynamic response is faster than that of linear servo drives.
The switching controller is designed to enhance the efficiency and responsiveness of low-power DC servo motors. The symmetrical complementary-transistor bridge configuration consists of four transistors arranged in a manner that allows for bidirectional control of the motor. This arrangement enables the application of voltage in either direction, facilitating smooth acceleration and deceleration of the motor.
In operation, when a control signal is applied, the transistors switch between their on and off states, rapidly changing the voltage across the motor. This rapid switching minimizes the time the transistors spend in their transition state, thereby reducing heat generation and improving overall efficiency. The use of a single-ended power supply simplifies the design and reduces costs while still delivering adequate power to the motor.
The inherent dynamic braking feature is a critical aspect of this design. When the control signal is removed or reversed, the transistors quickly switch off, allowing the motor to decelerate rapidly due to the back EMF generated. This not only improves response times but also enhances the overall control of the motor, making it suitable for applications requiring precise positioning and speed control.
Moreover, the faster dynamic response achieved through this switching method is a significant advantage over traditional linear servo drives. By applying maximum or zero voltage directly to the motor, the controller can achieve rapid changes in speed and direction, making it ideal for applications in robotics, automation, and other precision control systems. This design approach ultimately leads to improved performance, reduced energy consumption, and increased longevity of the servo motor.This high-performance switching controller for a low-power de servo motor uses a symmetrical complementary- transistor bridge. The bridge acts as a reversing switch between the motor and a single-ended power supply. Since the transistors operate either fully on or completely off, except during a very short transition period, much less heat is dissipated than in linear-amplifier circuits.
Damping is provided by the circuit"s inherent dynamic braking. Since either maximum or zero voltage is applied to the motor, the dynamic response is faster than that of linear servo drives.
servo motor control through keypad
This tutorial explains how to read the content of a microcontroller's flash memory. The source microcontroller reads the memory content and displays it on the LEDs. The content consists of the program stored in the microcontroller's memory. This step is...
Servo controlling circuit
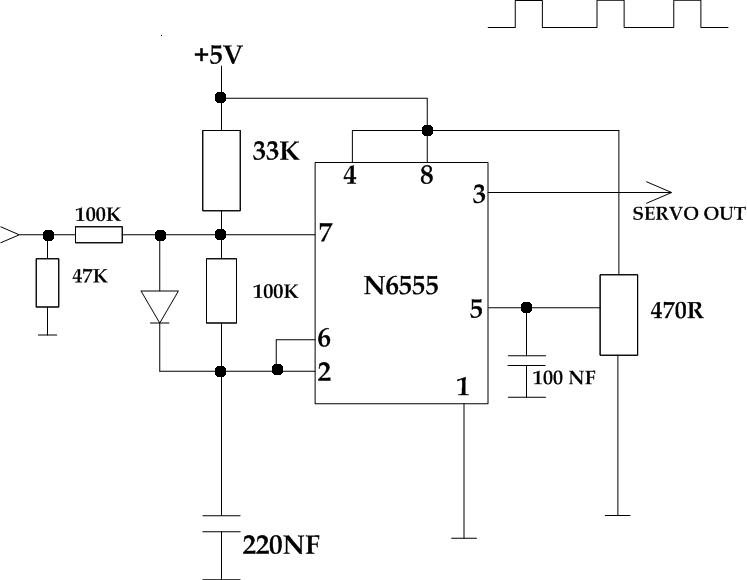
This circuit takes a standard 0-10V control voltage (for example, from an analog light control desk) and outputs a standard 1-2 ms control pulse for RC servo motors. The components used in this circuit include:
- 2 x 100 kΩ...
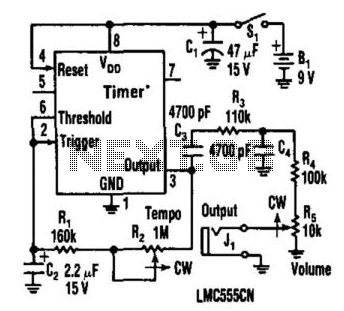
Low-Power Metronome
This metronome operates on a current of only 0.25 mA, making it suitable for battery-powered applications. It offers a tempo range from 34 to 246 beats per minute. The circuit can utilize a CMOS timer, such as the LM555 CN...
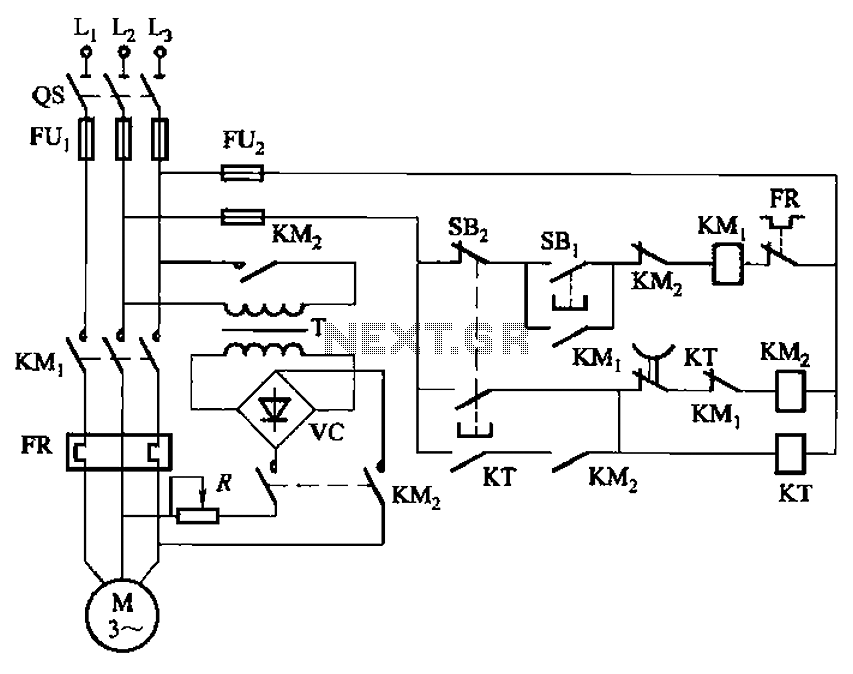
Three-way operation of the dynamic braking circuit
The circuit depicted in Figure 3-135 employs a time relay (KT) to determine the braking time.
The circuit utilizes a time relay, which is a crucial component for controlling the duration of the braking process. The time relay KT is designed...
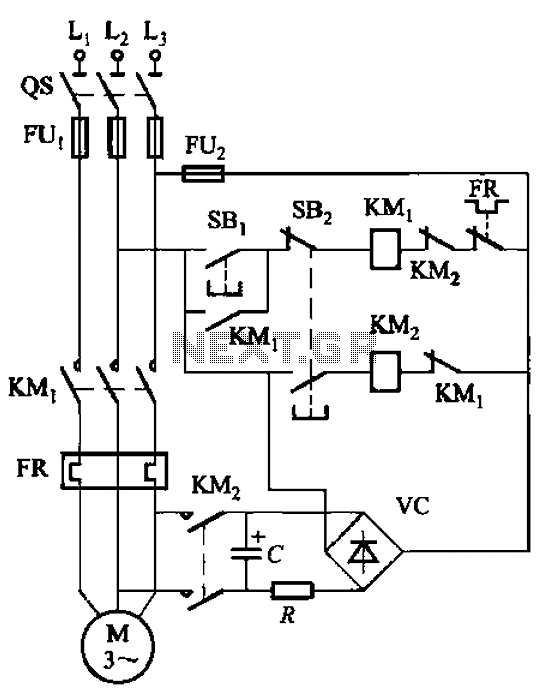
Six-way operation of the dynamic braking circuit
The circuit depicted in Figure 3-138 utilizes the principle of energy storage through capacitor discharge to achieve braking. The capacitance (C) and resistance (R) parameters are determined based on the size of the motor power. The capacitance (C) is typically...
Tupperware Turret Airsoft Gun Circuit
The Tupperware Turret circuit is designed to be straightforward while ensuring full functionality. The primary components in the schematic include the PIC 18F4520 microcontroller, servo motors, an infrared (IR) receiver, and a TIP120 transistor. This project is powered by four...
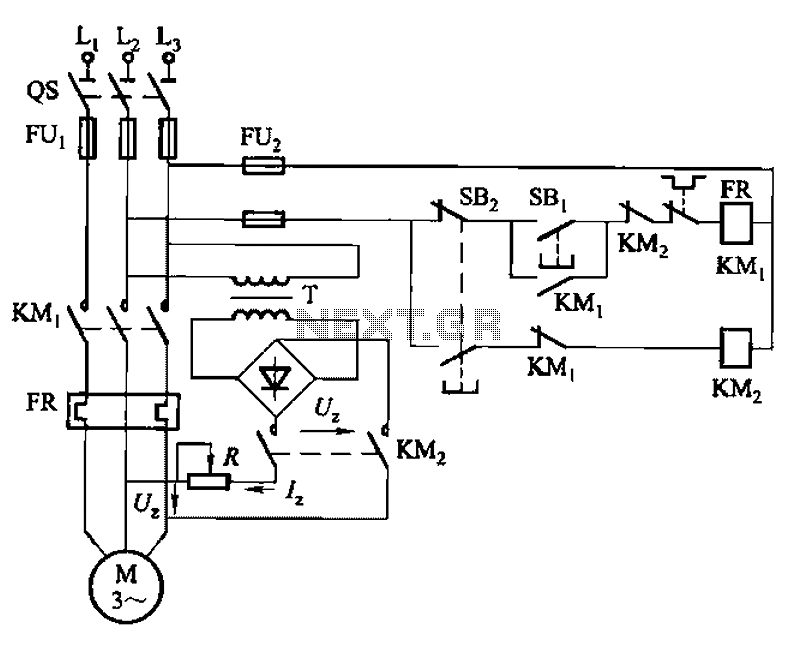
One-way operation of a dynamic braking circuit
The 3133 circuit is illustrated in Figure 3-133. It features dynamic braking controlled manually via buttons in three separate lines. In part (a) of the figure, the dynamic braking DC power supply is depicted with a step-down transformer and a...
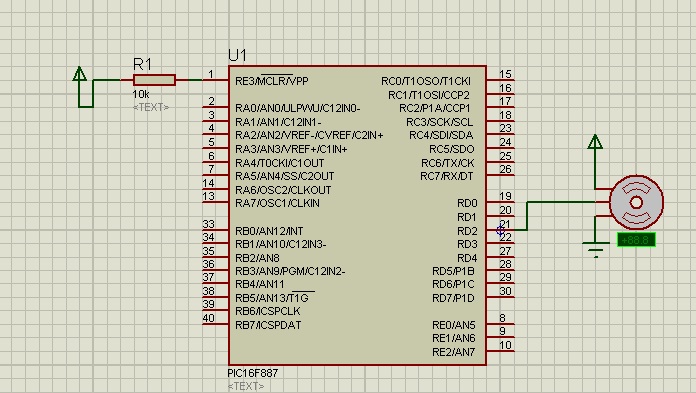
servo motor control with microcontroller
The shaft can be positioned at specific angular positions by sending a coded signal to the servo. As long as the coded signal is present on the input line, the servo will maintain the angular position of the shaft. Changes...
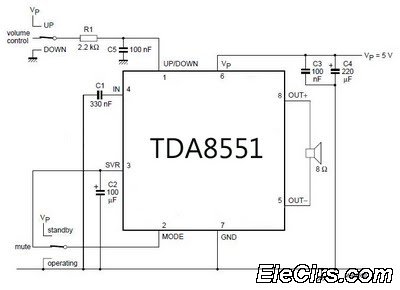
Low-Power Amplifier with digital volume control
An amplifier with digital volume control can be designed predictably due to the simplicity of the circuit, which utilizes a single chip, the TDA8551. This series of mini amplifiers with digital volume control operates as a BTL (Bridge-Tied Load) amplifier...