
Bubba oscillator with TLV2474
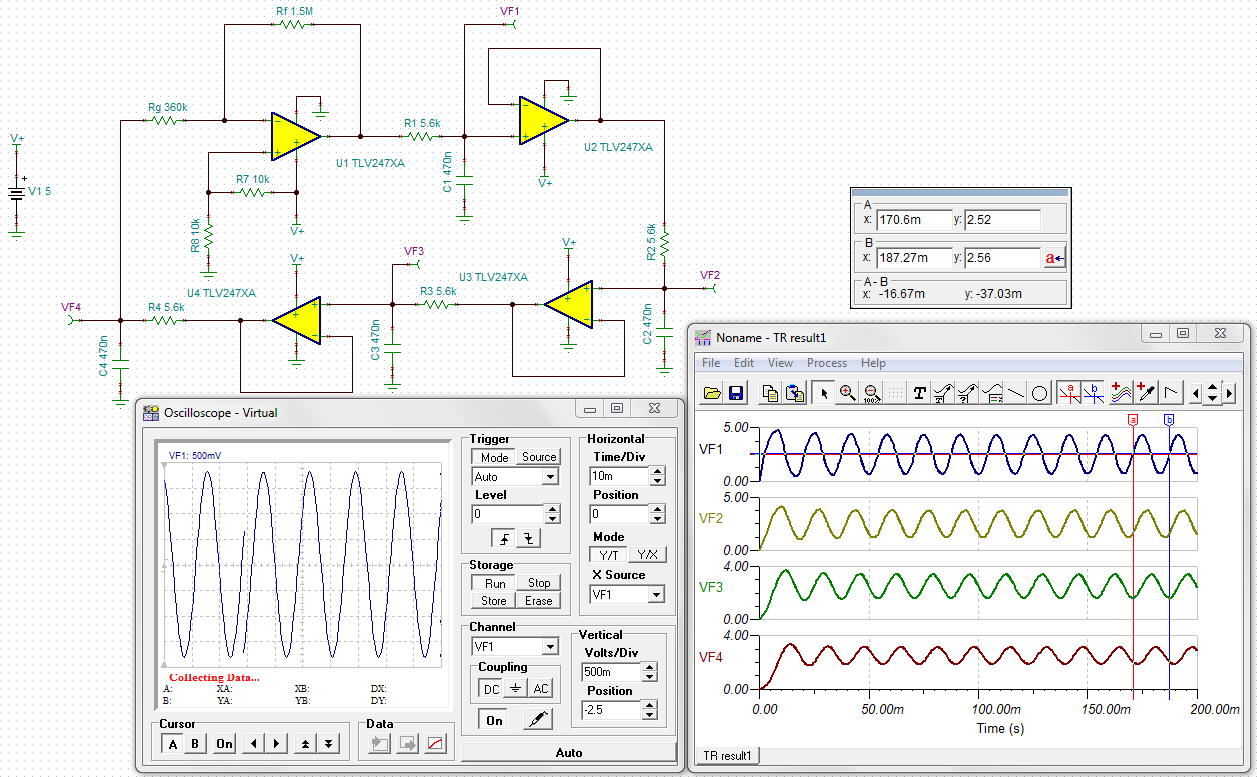
Description: Understanding the function and sizing of the resistors Rg and Rf for the Bubba oscillator circuit described in the application report SLOA060 - March 2011, page 17, figure 18. The purpose of the oscillator is to develop a current inverter through the H-bridge topology, oscillating at a frequency of 60Hz. The RC filter calculated from the equation f = (1/(2πRCs)) to achieve this frequency can be constructed using either a 26.5 kOhm resistor and a 100nF capacitor or a 3.9 kOhm resistor and a 680nF capacitor for all four RC filters. The operational amplifier used for this circuit is the TLV2474, as presented in the application note. The circuit's ability to fulfill its intended task is in question. Starting an oscillator in a PSpice simulator can be challenging as it may require specific startup conditions. TINA-TI is generally more accommodating in this regard. To initiate the Bubba oscillator in TINA-TI, select the Analysis tab and choose Transient. When the Transient Analysis window appears, switch the selection from "Calculate operating point" to either "Use initial conditions" or "Zero initial values." After completing the simulation, the transient analysis should show oscillation at designated measurement points. The point of oscillation in the Bubba occurs when the phase shift of each of the four stages is -45 degrees. The unadjusted gain at this phase shift is -3 dB, or 0.707 V/V. If each stage has a gain of 0.707 V/V, the overall gain would be (0.707)^4 or 0.25 V/V. Therefore, to achieve oscillation, a gain of at least 4 V/V must be applied within the loop to attain an overall gain of 1 V/V. With one stage operating as an inverter, the total phase shift between the input and output becomes 0 degrees (positive feedback). Thus, with a gain of 1 V/V or slightly more and a phase shift around the loop of 0 degrees, the Barkhausen criterion for sustained oscillation is satisfied. Adjustments to the RC filter values were made to bring the frequency as close as possible to 60Hz. With 5.6 kOhm resistors (1% tolerance) and 0.47uF capacitors (5% tolerance), the cycle time is 16.67 ms, resulting in a frequency of approximately 59.988Hz. Although the circuit has been made to oscillate with Rg and Rf values of 360 kOhm and 1.5 MOhm, respectively, the relationship between these components and the gain and amplitude of the circuit remains unclear. The information provided is sufficient for circuit functionality, but further elaboration on the role of these resistors in the oscillator circuit would be beneficial. A gain of at least 4 V/V is necessary to overcome the 0.707 V/V voltage gain of each stage at the -45 degree phase frequency. The overall gain, being the product of each of the four stages (0.707)^4 or 0.25 V/V, indicates that incorporating a gain stage with a gain of 4 V/V results in an overall gain of 1 V/V around the loop. A gain slightly larger than 1 V/V helps ensure oscillation. The 1.5 Meg feedback resistor (Rf) and the 360 k input resistor (Rg) connected to U1 set the TLV2474 amplifier stage to operate with a gain of approximately -4.17 V/V (the negative sign indicates inversion). This gain is sufficiently high to ensure the circuit will oscillate.
The Bubba oscillator circuit is a specialized configuration that utilizes multiple stages of operational amplifiers to achieve sustained oscillation. The design typically includes four stages, each contributing to the overall gain required for oscillation. Resistors Rg and Rf play a crucial role in determining the gain of the operational amplifier stage, which is essential for meeting the Barkhausen criterion for oscillation.
In this circuit, Rg is the resistor connected to the input of the operational amplifier, while Rf is the feedback resistor connected from the output back to the inverting input. The gain of the amplifier stage can be calculated using the formula:
Gain = -Rf / Rg
This relationship indicates that the feedback resistor Rf directly influences the gain, while Rg serves to set the input impedance and also affects the overall gain of the stage. For the given values (Rf = 1.5 MOhm and Rg = 360 kOhm), the calculated gain is approximately -4.17 V/V, which is sufficient to ensure that the circuit meets the conditions necessary for sustained oscillation.
The phase shift introduced by each stage is critical; each stage ideally contributes a -45 degree phase shift at the oscillation frequency. This phase shift, combined with the necessary gain, creates a feedback loop that allows the oscillator to maintain oscillation. If the gain is less than what is required, the circuit will not sustain oscillation, whereas too much gain can lead to instability.
In summary, the careful selection of Rg and Rf values not only determines the gain of the operational amplifier stage but also plays a pivotal role in ensuring that the Bubba oscillator circuit operates effectively at the desired frequency. Adjusting these resistors allows for fine-tuning of the circuit to achieve optimal performance, ensuring that the oscillator can function as intended within the specified parameters.understanding of the function and sizing of the resistors Rg and Rf for the bubba oscillator circuit described on the application report SLOA060 - march 2011, page 17 figure 18. The oscillator porpuse is to develope a current inverter thru the H-bridge topology, oscillating on a frequency of 60Hz.
The RC filter i`ve calculated from the equation `f=(1/(2*pi*R*Cs)` in order to oscillate on this particular frequency is built up by either a 26, 5kOhm resistor and 100nF capacitor or a 3, 9kOhm resistor and 680nF capacitor, for all four RC filters. The op amp i am going to use for this circuit is the same presented by the application note, TLV2474.
I`d apreciate very much if you could help me with this and even tell me if this circuit is able to fulfill the task. Thank you very much in advance! Getting an oscillator to start up in a PSpice simulator can sometimes be a little tricky because the simulation circuitsometimes need a bit of pushortheright start-up conditions to get it going.
However, TINA-TI is usually pretty good about doing so - at least from my experience. The way to get the Bubba oscillatorstartedfor this case is to selectthe Analysis tab, andTransient. Then, when the Transient Analysis window appears, move the bullet selection from Calculate operating point, to either Use initial conditions, or Zero initial values. Once the simulation is completed the transient analysis should display the oscillation at the designated measurement points.
You can see the results I obtained: The point of oscillation in the Bubba occurs when the phase shift of each of the four stages is -45 degrees. The unadjusted gainat -45 degrees phase shift is -3 dB, or 0. 707 V/V. If each stage has a gain of 0. 707 V/V, then the overall gain would be (0. 707)4 or 0. 25 V/V. Therefore, for oscillation to occur again of >= 4 V/V must be appliedwithin the loop toattain an overall gainof 1 V/V.
Since 4 x(-45 degrees) only accounts for-180 degrees having one stage operating asan inverter results in 0 degrees of total phase shift betweenthe input and output (positive feedback). Thus, with a gain of 1 V/V (or slightly more) and a phase shift around the loop of 0 degrees the Barkhausen criterion for sustained oscillation is satisfied.
See en. wikipedia. org/wiki/Barkhausen_stability_criterion Thank you very much for your support, it was very helpful! As you can see on the picture, i changed the values of the RC filters in order to adjust the frequency to the closest possible of 60hz. With 5, 6kOhm resitors of 1% tolerance and 0. 47uF capacitors of 5% tolerance, the cycle time is 16, 67ms, and the frequency is then 59, 988Hz. Although i has been able to make the circuit oscillate with the same resistor values for Rg and Rf (360kOhm and 1.
5MOhm, respectively), i still dont understand the relationship these two components have with the gain and amplitude of the circuit. The information you have provided me is enough for making the circuit to function, but it would be quite a great help if you could elaborate on the role these resistors have on this oscillator circuit.
I mentioned in my previous response thata gainof at least 4 V/Vhad to be included in the circuit to over come0. 707 V/V voltage gain of each stage at the -45 degree phase frequency. Thegain of the overall circuit would be the product of each of the 4 stages, (0. 707)4 or 0. 25 V/V. Including a gain stage with a gain of 4 V/V results in an overallgain of 1 V/V around the loop. A gain slightly larger than 1 V/V helps assure oscillation. The 1. 5 Meg feedback resistor (Rf) and 360 k input resistor (Rg) connected toU1 set up that TLV2474 amplifier stage to operate with a gain of approximately -4.
17 V/V (minus sign indicates inversion). A Gain of 4. 17 V/V is high enough to assure the circuit will oscillate,
The Bubba oscillator circuit is a specialized configuration that utilizes multiple stages of operational amplifiers to achieve sustained oscillation. The design typically includes four stages, each contributing to the overall gain required for oscillation. Resistors Rg and Rf play a crucial role in determining the gain of the operational amplifier stage, which is essential for meeting the Barkhausen criterion for oscillation.
In this circuit, Rg is the resistor connected to the input of the operational amplifier, while Rf is the feedback resistor connected from the output back to the inverting input. The gain of the amplifier stage can be calculated using the formula:
Gain = -Rf / Rg
This relationship indicates that the feedback resistor Rf directly influences the gain, while Rg serves to set the input impedance and also affects the overall gain of the stage. For the given values (Rf = 1.5 MOhm and Rg = 360 kOhm), the calculated gain is approximately -4.17 V/V, which is sufficient to ensure that the circuit meets the conditions necessary for sustained oscillation.
The phase shift introduced by each stage is critical; each stage ideally contributes a -45 degree phase shift at the oscillation frequency. This phase shift, combined with the necessary gain, creates a feedback loop that allows the oscillator to maintain oscillation. If the gain is less than what is required, the circuit will not sustain oscillation, whereas too much gain can lead to instability.
In summary, the careful selection of Rg and Rf values not only determines the gain of the operational amplifier stage but also plays a pivotal role in ensuring that the Bubba oscillator circuit operates effectively at the desired frequency. Adjusting these resistors allows for fine-tuning of the circuit to achieve optimal performance, ensuring that the oscillator can function as intended within the specified parameters.understanding of the function and sizing of the resistors Rg and Rf for the bubba oscillator circuit described on the application report SLOA060 - march 2011, page 17 figure 18. The oscillator porpuse is to develope a current inverter thru the H-bridge topology, oscillating on a frequency of 60Hz.
The RC filter i`ve calculated from the equation `f=(1/(2*pi*R*Cs)` in order to oscillate on this particular frequency is built up by either a 26, 5kOhm resistor and 100nF capacitor or a 3, 9kOhm resistor and 680nF capacitor, for all four RC filters. The op amp i am going to use for this circuit is the same presented by the application note, TLV2474.
I`d apreciate very much if you could help me with this and even tell me if this circuit is able to fulfill the task. Thank you very much in advance! Getting an oscillator to start up in a PSpice simulator can sometimes be a little tricky because the simulation circuitsometimes need a bit of pushortheright start-up conditions to get it going.
However, TINA-TI is usually pretty good about doing so - at least from my experience. The way to get the Bubba oscillatorstartedfor this case is to selectthe Analysis tab, andTransient. Then, when the Transient Analysis window appears, move the bullet selection from Calculate operating point, to either Use initial conditions, or Zero initial values. Once the simulation is completed the transient analysis should display the oscillation at the designated measurement points.
You can see the results I obtained: The point of oscillation in the Bubba occurs when the phase shift of each of the four stages is -45 degrees. The unadjusted gainat -45 degrees phase shift is -3 dB, or 0. 707 V/V. If each stage has a gain of 0. 707 V/V, then the overall gain would be (0. 707)4 or 0. 25 V/V. Therefore, for oscillation to occur again of >= 4 V/V must be appliedwithin the loop toattain an overall gainof 1 V/V.
Since 4 x(-45 degrees) only accounts for-180 degrees having one stage operating asan inverter results in 0 degrees of total phase shift betweenthe input and output (positive feedback). Thus, with a gain of 1 V/V (or slightly more) and a phase shift around the loop of 0 degrees the Barkhausen criterion for sustained oscillation is satisfied.
See en. wikipedia. org/wiki/Barkhausen_stability_criterion Thank you very much for your support, it was very helpful! As you can see on the picture, i changed the values of the RC filters in order to adjust the frequency to the closest possible of 60hz. With 5, 6kOhm resitors of 1% tolerance and 0. 47uF capacitors of 5% tolerance, the cycle time is 16, 67ms, and the frequency is then 59, 988Hz. Although i has been able to make the circuit oscillate with the same resistor values for Rg and Rf (360kOhm and 1.
5MOhm, respectively), i still dont understand the relationship these two components have with the gain and amplitude of the circuit. The information you have provided me is enough for making the circuit to function, but it would be quite a great help if you could elaborate on the role these resistors have on this oscillator circuit.
I mentioned in my previous response thata gainof at least 4 V/Vhad to be included in the circuit to over come0. 707 V/V voltage gain of each stage at the -45 degree phase frequency. Thegain of the overall circuit would be the product of each of the 4 stages, (0. 707)4 or 0. 25 V/V. Including a gain stage with a gain of 4 V/V results in an overallgain of 1 V/V around the loop. A gain slightly larger than 1 V/V helps assure oscillation. The 1. 5 Meg feedback resistor (Rf) and 360 k input resistor (Rg) connected toU1 set up that TLV2474 amplifier stage to operate with a gain of approximately -4.
17 V/V (minus sign indicates inversion). A Gain of 4. 17 V/V is high enough to assure the circuit will oscillate,
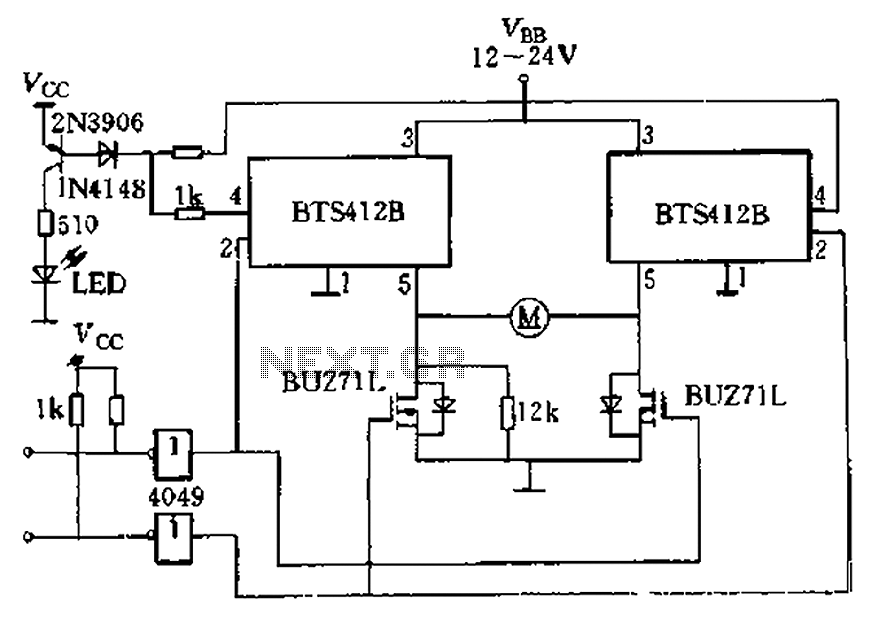
H-bridge driver circuit composed by the Smart SIPMOS
The BTS412B functions as two high-side power MOSFET switches, while two BU271L (50V, Zhang 1n) serve as low-side switches, forming a bi-directional H-bridge DC motor drive circuit. This configuration is designed for electrical automatic door systems, capable of handling continuous...
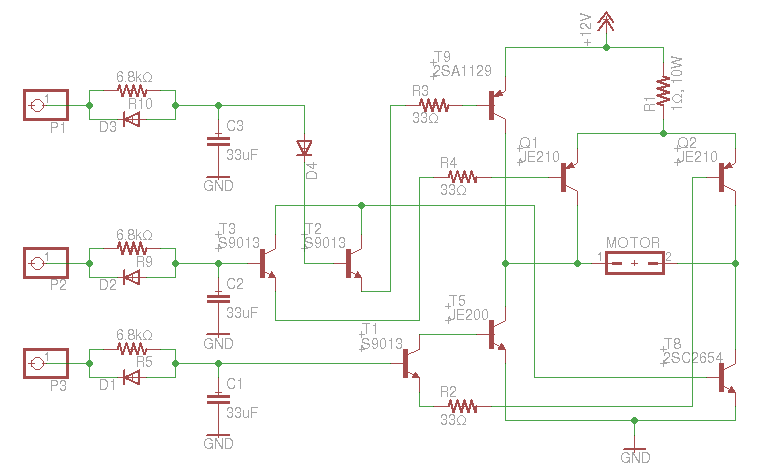
transistors Can someone help me understand this H-Bridge
An old RC car is available, but it lacks the transmitter. A custom receiver/transmitter has been built using a microcontroller and a 2.4 GHz transceiver. However, there is uncertainty regarding the functionality of the car's original H-Bridge circuit.
The H-Bridge is...
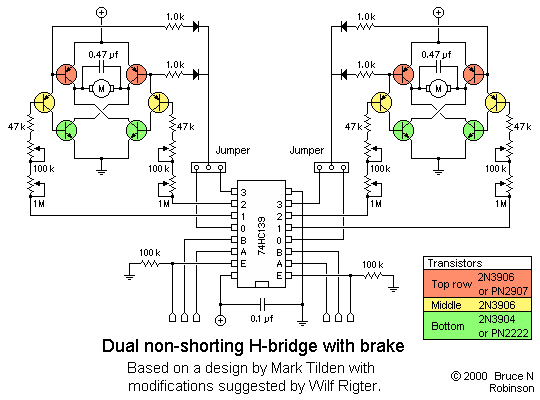
H-bridge
It was previously assumed that dynamic braking would be most effective at higher speeds. However, tests conducted with a Faulhaber (Micro Mo) gear motor demonstrated that the brake could hold the motor almost stationary. These gear motors are constructed so...
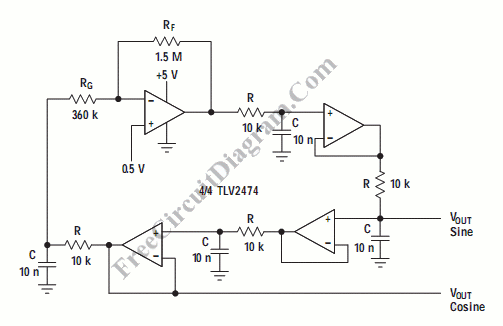
Bubba Oscillator
The Bubba oscillator is another example of a phase shift oscillator. It utilizes a quad op-amp package to achieve a 45-degree phase shift.
The Bubba oscillator is a type of phase shift oscillator that employs a configuration of operational amplifiers (op-amps)...
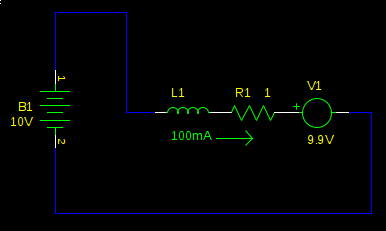
h bridge How can I implement regenerative braking of a DC motor
Many electric vehicles can convert the momentum of the car into stored energy in batteries, instead of dissipating it as heat in the brake pads. This process is known as regenerative braking. It can be implemented using a motor controlled...
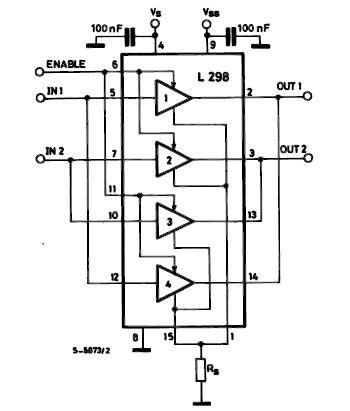
dc motor driver with h bridge ic l293d
The L298 IC H-Bridge DC motor driver features two H-Bridge circuits, allowing it to control two DC motors simultaneously. Each H-Bridge can deliver currents up to 2A, but when used in parallel, the L298 can provide a total current of...
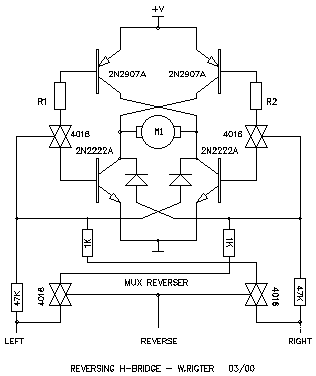
Wilf Rigter`s reversing H-bridge
This H-bridge variant was one of the first in which the reversing circuitry is built into the driver, rather than (as is more-commonly done) into the control circuitry upstream of the driver. This is a handy circuit, though, for 2-motor...
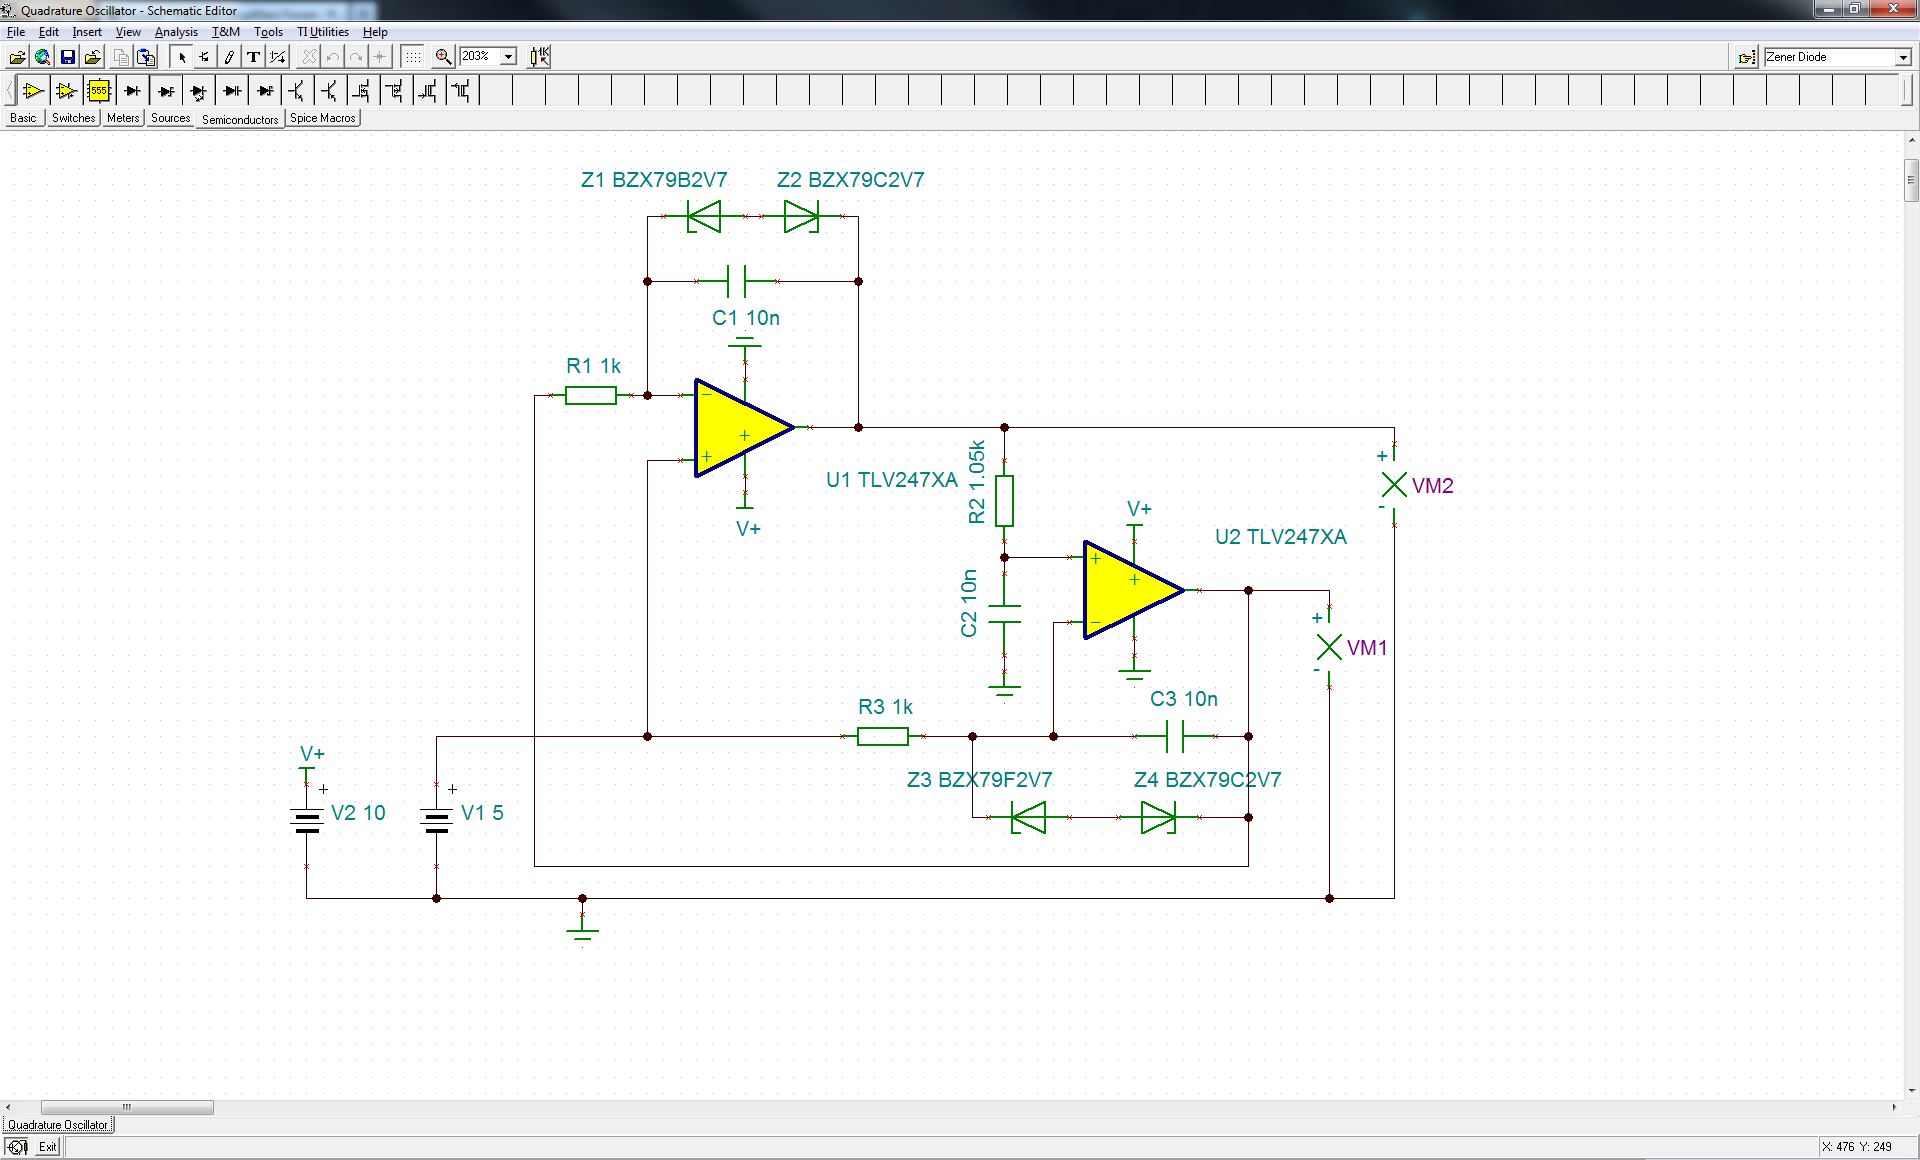
Quadrature Oscillator with TLV2474
The circuit is close to sustaining oscillation. Changing resistor R2 to 10.5k will enable it to sustain oscillation. The original authors of the referenced note are no longer available for consultation. Oscillators of this type can be complex, as there...
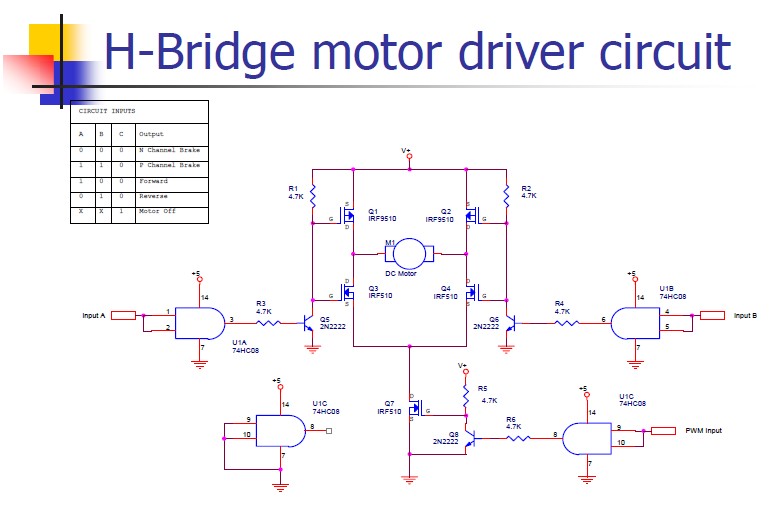
robot tutorial dc motor control system
An H-bridge motor driver circuit is designed to control a DC motor. By using a low signal, such as a 5-volt signal, the circuit enables the program to manage the motor, which operates on a higher power supply.
The H-bridge motor...