
Which only uses the 5V power supply connection circuit
#5V
#PWM
#power supply
#voltage regulation
#signal output
#error processing
#differential position
#MC signal
#circuit design
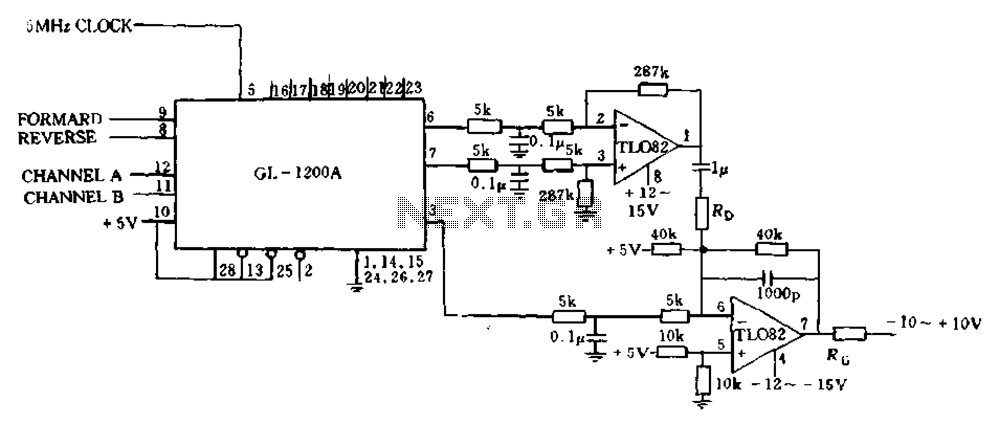
Description: The error processing segment is converted into a pulse width modulated (PWM) signal output from 3 feet (MC signal). Additionally, the differential position error is calculated, which represents the small velocity, from 6 to 7 feet, selected as a system with damping. The system features a speed that is proportional to one positive signal and another negative signal, corresponding to the speed. Two signals are directed into an analog channel in an external operational amplifier, with damping represented by a specific number. Another operational amplifier is used for damping, and the position error signal can be synthesized into an analog signal for controlling the final stage power amplifier, which drives a DC motor. Gain and damping are adjusted using two resistors, RD and R, resulting in excellent system performance.
The circuit operates by converting the error signal into a PWM output, which modulates the width of the pulses to control the power delivered to the load—in this case, a DC motor. The input error signal is derived from the differential position error, calculated based on the system's position feedback from the sensors located at 6 and 7 feet. This feedback is essential for maintaining the desired position of the motor.
The PWM signal is generated by comparing the error signal against a reference signal within a comparator circuit. The output of this comparator drives a power amplifier, which is responsible for supplying the necessary current to the motor. The operational amplifiers in the circuit play a critical role in signal conditioning and ensuring that the error signals are appropriately scaled and filtered. The first operational amplifier processes the error signal and applies damping to reduce oscillations and improve stability.
The gain and damping of the system are set using resistors RD and R, which form part of the feedback network in the operational amplifiers. By adjusting these resistors, the performance of the motor control system can be fine-tuned to achieve desired response characteristics, such as settling time and overshoot. This adjustment is crucial for applications requiring precise control over the motor's position and speed.
Overall, this circuit design emphasizes the importance of feedback control in motor applications, utilizing PWM for efficient power management and operational amplifiers for effective signal processing, ensuring robust performance in dynamic environments.Error processing segment is converted to a pulse width modulated (PWM) signal output from 3 feet (MC signal). Also calculate the differential position error, which represents t he small velocity, from 6 and 7 feet elected as a system with damping. A speed proportional to their positive and the other negative is proportional to the speed. Two signal into an analog channel in an external operational amplifier damping in number. With another damping operational amplifier and the position error signal as a synthesis may be an analog signal for controlling the power amplifier final stage, driving a DC motor. (See Fig. 13-17). Gain and damping by two resistors RD and R. systems to adjust, Tsui excellent performance of the system.
The circuit operates by converting the error signal into a PWM output, which modulates the width of the pulses to control the power delivered to the load—in this case, a DC motor. The input error signal is derived from the differential position error, calculated based on the system's position feedback from the sensors located at 6 and 7 feet. This feedback is essential for maintaining the desired position of the motor.
The PWM signal is generated by comparing the error signal against a reference signal within a comparator circuit. The output of this comparator drives a power amplifier, which is responsible for supplying the necessary current to the motor. The operational amplifiers in the circuit play a critical role in signal conditioning and ensuring that the error signals are appropriately scaled and filtered. The first operational amplifier processes the error signal and applies damping to reduce oscillations and improve stability.
The gain and damping of the system are set using resistors RD and R, which form part of the feedback network in the operational amplifiers. By adjusting these resistors, the performance of the motor control system can be fine-tuned to achieve desired response characteristics, such as settling time and overshoot. This adjustment is crucial for applications requiring precise control over the motor's position and speed.
Overall, this circuit design emphasizes the importance of feedback control in motor applications, utilizing PWM for efficient power management and operational amplifiers for effective signal processing, ensuring robust performance in dynamic environments.Error processing segment is converted to a pulse width modulated (PWM) signal output from 3 feet (MC signal). Also calculate the differential position error, which represents t he small velocity, from 6 and 7 feet elected as a system with damping. A speed proportional to their positive and the other negative is proportional to the speed. Two signal into an analog channel in an external operational amplifier damping in number. With another damping operational amplifier and the position error signal as a synthesis may be an analog signal for controlling the power amplifier final stage, driving a DC motor. (See Fig. 13-17). Gain and damping by two resistors RD and R. systems to adjust, Tsui excellent performance of the system.
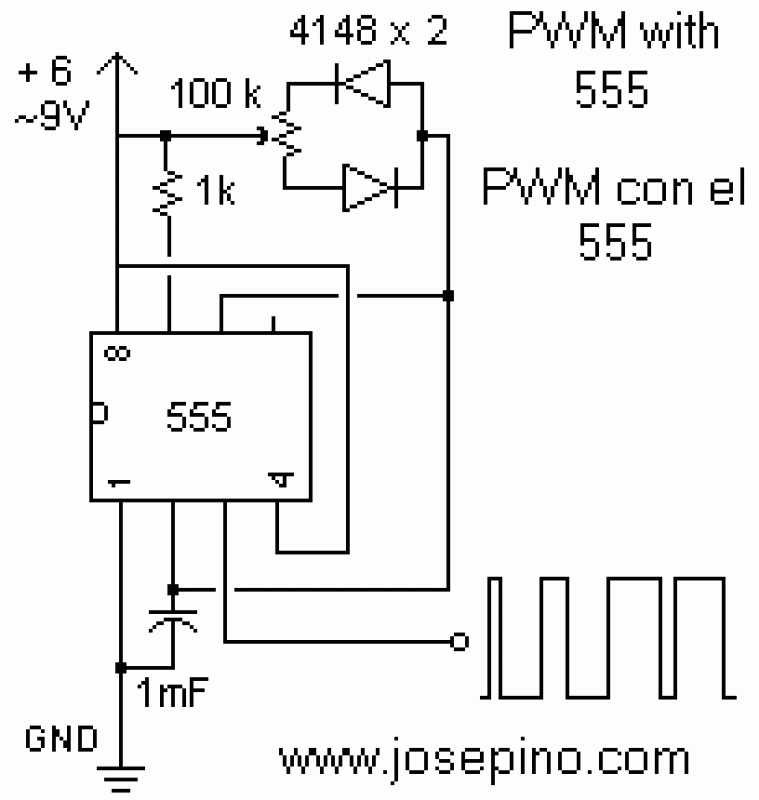
Motor speed controller with timer 555
Pulse width modulation (PWM) is a technique to control analog circuits with a digital output. PWM is used in many applications, especially to control light intensity and speed on motors. A PWM circuit makes a square wave with a variable...
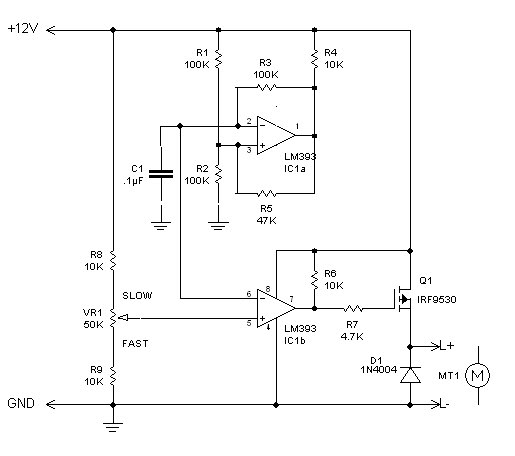
PWM circuit
The inquiry pertains to identifying the component within the circuit that regulates the minimum RPM achievable. The current operational range of the motor is between 1400 and 3700 RPM, and there is an interest in modifying the circuit to lower...
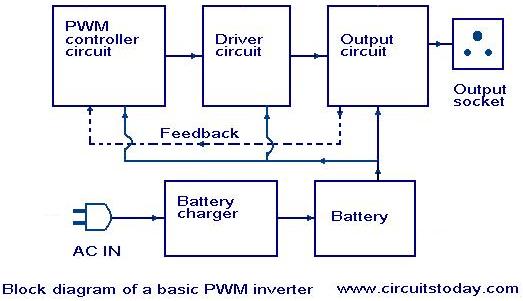
Introduction to PWM Inverters
Nowadays, most inverters available in the market utilize Pulse Width Modulation (PWM) technology. Inverters based on PWM technology exhibit superior performance in several aspects compared to those designed using conventional methods. These PWM inverters typically employ MOSFETs in the output...
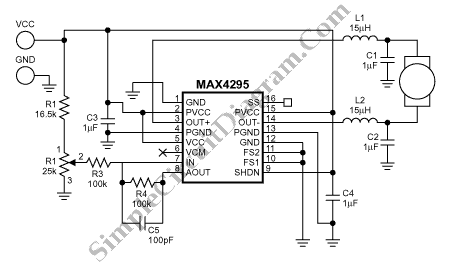
PWM Motor Speed Control Using Class D Audio Amplifier
This is a Class D audio amplifier circuit used to control the PWM motor speed. This circuit has two advantages for battery-powered portable devices. First, it provides high efficiency, which extends battery life.
The Class D audio amplifier operates by modulating...
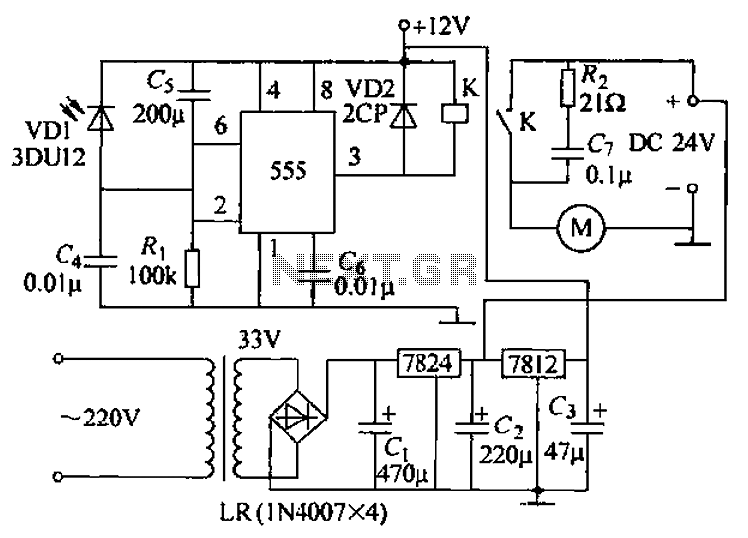
Remote tracking circuit schematics
The circuit consists of two main components: (1) a power supply circuit featuring a transformer (T) that steps down AC 220V to 33V, followed by a full-wave rectifier, a filter, and a three-terminal regulator that outputs +24V. This circuit also...
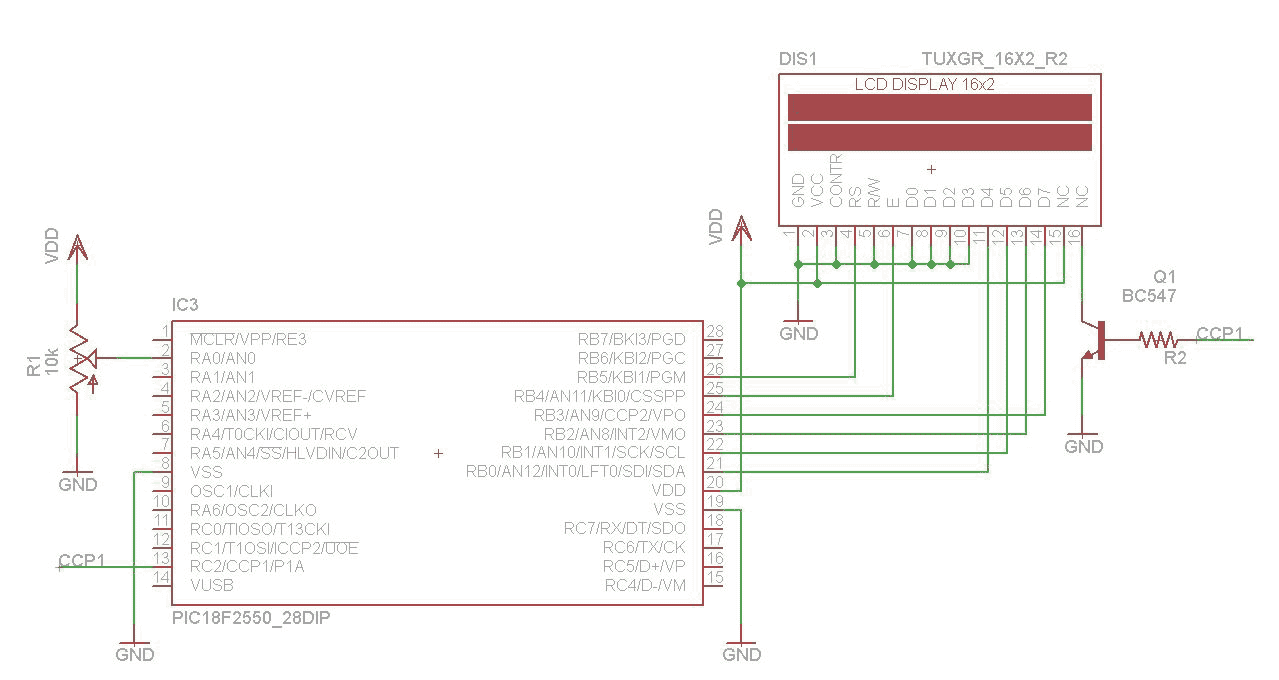
PWM controller with PIC18f2455
The use of pulse width modulation (PWM) is common for the use of controlling power to a particular electrical device. Motor speed control, LED contrast control, power supplies are some of the example usage of PWM. 18 series PIC always...
250 to 5000 watts PWM DC/AC 220V Power Inverter
The schematic circuit design is for a 250-watt output inverter. To increase the power of the circuit, additional Q7 and Q8 transistors can be added in parallel; each pair contributes an additional 250 watts. For instance, to achieve 750 watts,...
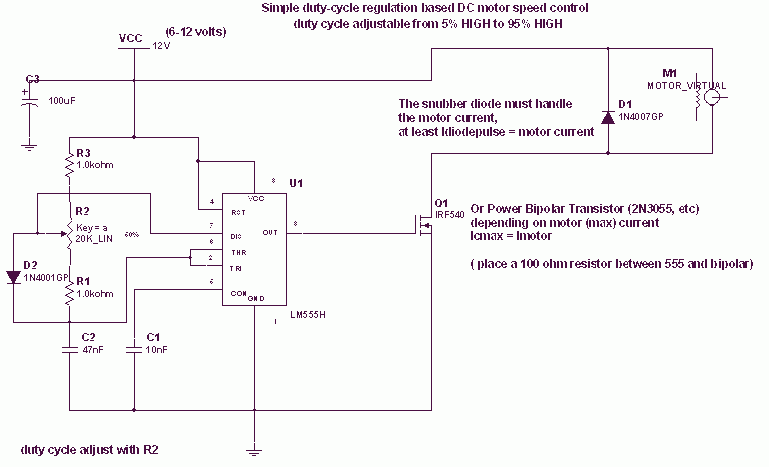
DC motor PWM speed control
The 555 IC is wired as an astable and the frequency is constant and independent of the duty cycle, as the total resistance (R charge + R discharge, notice the diode) is constant and equal to 22Kohm (giving a frequency...
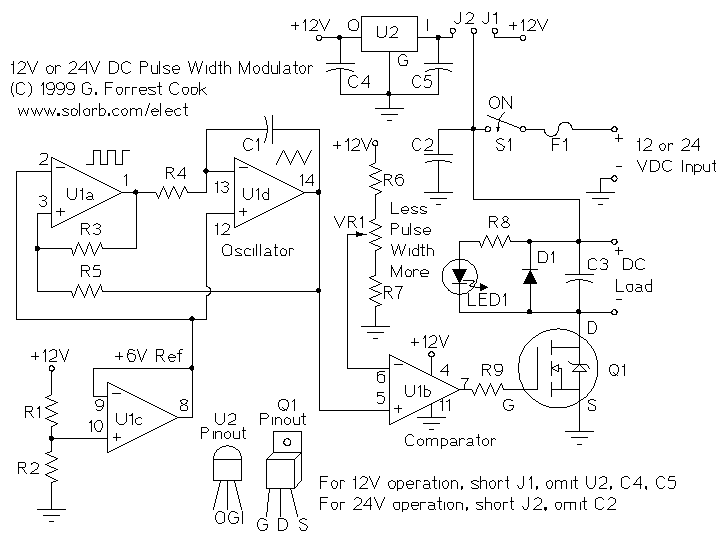
LM324N PWM Motor Speed Controller
PWM is a device that can be utilized as an efficient light dimmer or DC motor speed controller. Function: for a general-purpose device that can...
PWM (Pulse Width Modulation) is a versatile technique widely employed in various electronic applications, particularly for...