
Robot control circuit composed of transistor and NE555
#transistor
#NE555
#robot control
#object detection
#motor control
#sensor
#automation
#obstacle avoidance
#circuit design
#electronics
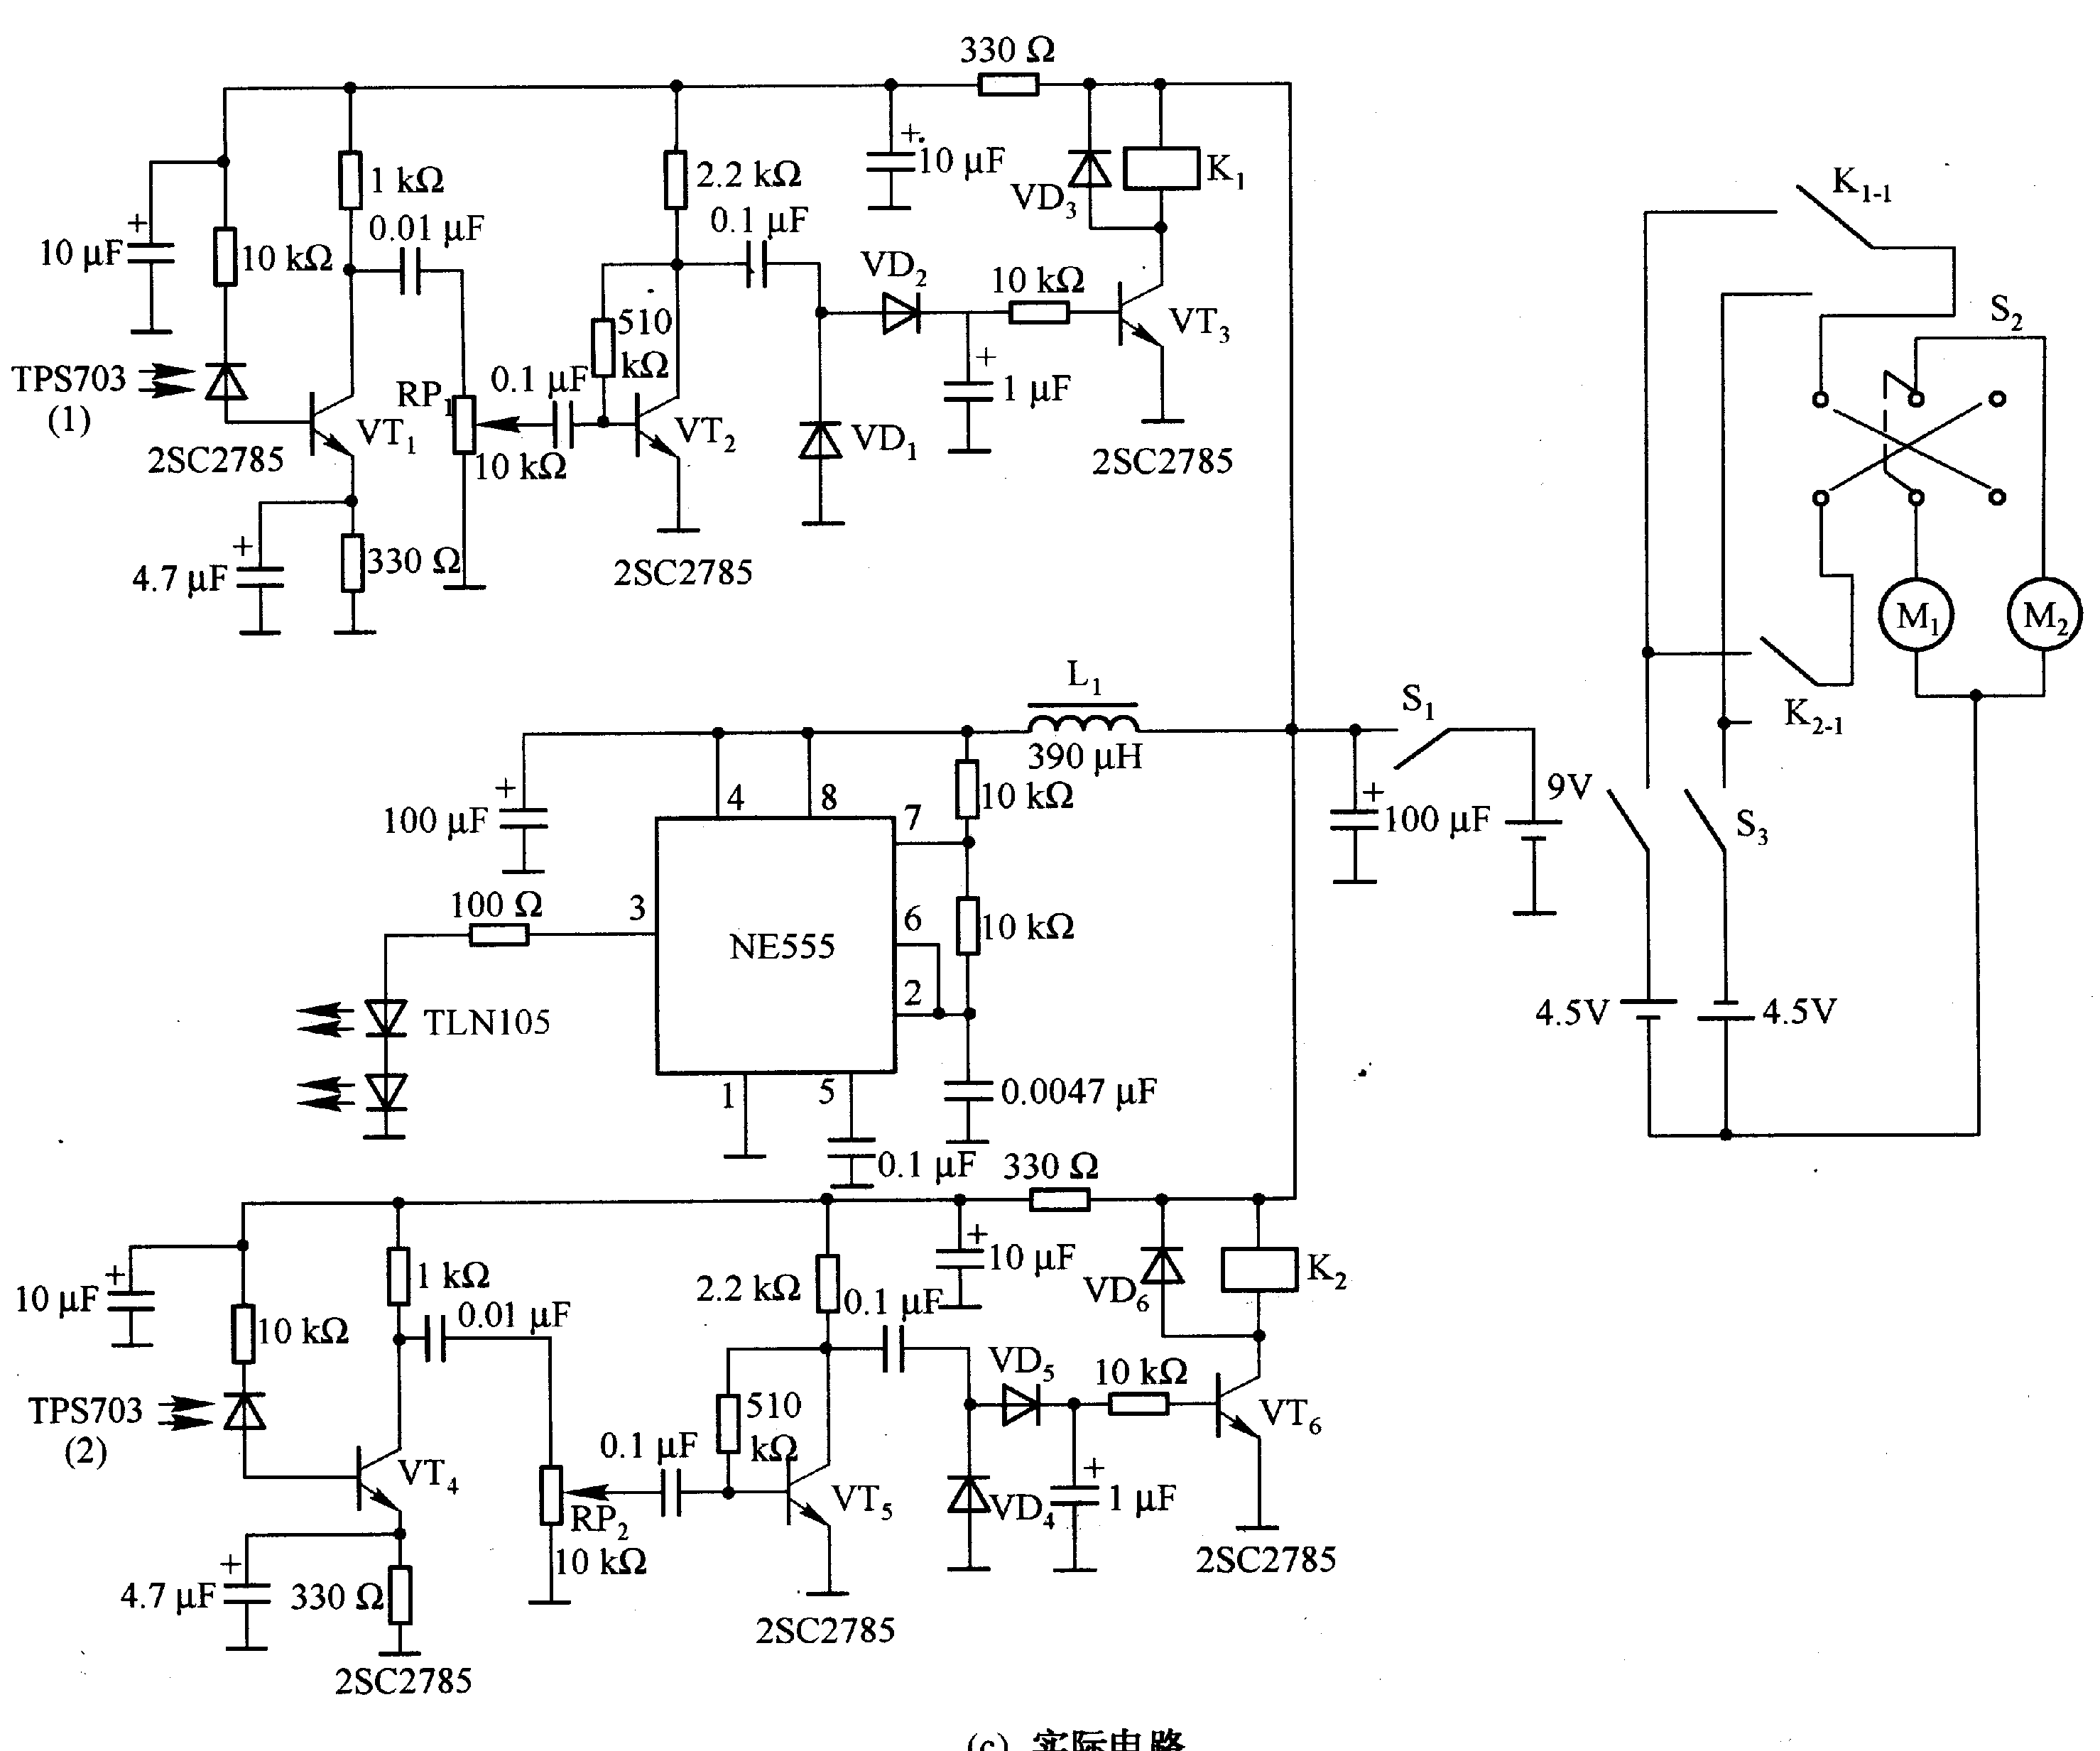
Description: Figure 2-33 (a) illustrates the schematic diagram of a robot approaching an object. When no objects are detected in front of the robot, it moves forward in a straight line. If an object is detected on the left or right side, the robot will turn in the corresponding direction to approach the object. Figure 2-33 (b) presents the block diagram that facilitates this action. Figure 2-33 (c)...
The schematic diagram depicted in Figure 2-33 (a) outlines the operational mechanism of a robot designed for object detection and navigation. The primary function of this robot is to maintain forward motion until an obstacle is detected. The robot is equipped with sensors, typically ultrasonic or infrared, positioned at the front and sides to detect the presence of objects within its path.
When the sensors at the front of the robot do not detect any objects, the control system maintains a command for the motors to drive the robot forward. This movement is achieved through a differential drive mechanism, where two independent motors control the left and right wheels, allowing for precise movement and turning capabilities.
In scenarios where an object is detected on either side, the control system processes the sensor data to determine the appropriate response. If an object is detected on the left, the robot will initiate a right turn, and conversely, if an object is detected on the right, the robot will turn left. The turning action is executed by adjusting the speed of the motors; the motor on the side opposite to the detected object will slow down or stop, while the motor on the side of the detected object will continue to propel the robot forward, facilitating a smooth turn towards the object.
Figure 2-33 (b) provides a block diagram that outlines the control logic and signal flow within the robot's navigation system. This block diagram typically includes components such as the sensor inputs, microcontroller, motor drivers, and feedback loops that ensure the robot reacts appropriately to its environment. The microcontroller processes the input signals from the sensors, executes the control algorithms, and sends commands to the motor drivers to adjust the robot's movement accordingly.
Overall, the described system allows for efficient navigation and object interaction, enabling the robot to adapt its path based on real-time environmental feedback.Figure 2-33 (a) is the action schematic diagram of the robot closing to the object. When there is no objects in front of the robot, it will go forward in the straight line; when there is an object in left or right side of the robot,it will turn left or right to close to the object. Figure 2-33 (b) is the block diagram to achieve this action. Figure 2-33 (c)..
The schematic diagram depicted in Figure 2-33 (a) outlines the operational mechanism of a robot designed for object detection and navigation. The primary function of this robot is to maintain forward motion until an obstacle is detected. The robot is equipped with sensors, typically ultrasonic or infrared, positioned at the front and sides to detect the presence of objects within its path.
When the sensors at the front of the robot do not detect any objects, the control system maintains a command for the motors to drive the robot forward. This movement is achieved through a differential drive mechanism, where two independent motors control the left and right wheels, allowing for precise movement and turning capabilities.
In scenarios where an object is detected on either side, the control system processes the sensor data to determine the appropriate response. If an object is detected on the left, the robot will initiate a right turn, and conversely, if an object is detected on the right, the robot will turn left. The turning action is executed by adjusting the speed of the motors; the motor on the side opposite to the detected object will slow down or stop, while the motor on the side of the detected object will continue to propel the robot forward, facilitating a smooth turn towards the object.
Figure 2-33 (b) provides a block diagram that outlines the control logic and signal flow within the robot's navigation system. This block diagram typically includes components such as the sensor inputs, microcontroller, motor drivers, and feedback loops that ensure the robot reacts appropriately to its environment. The microcontroller processes the input signals from the sensors, executes the control algorithms, and sends commands to the motor drivers to adjust the robot's movement accordingly.
Overall, the described system allows for efficient navigation and object interaction, enabling the robot to adapt its path based on real-time environmental feedback.Figure 2-33 (a) is the action schematic diagram of the robot closing to the object. When there is no objects in front of the robot, it will go forward in the straight line; when there is an object in left or right side of the robot,it will turn left or right to close to the object. Figure 2-33 (b) is the block diagram to achieve this action. Figure 2-33 (c)..
water activated alarm
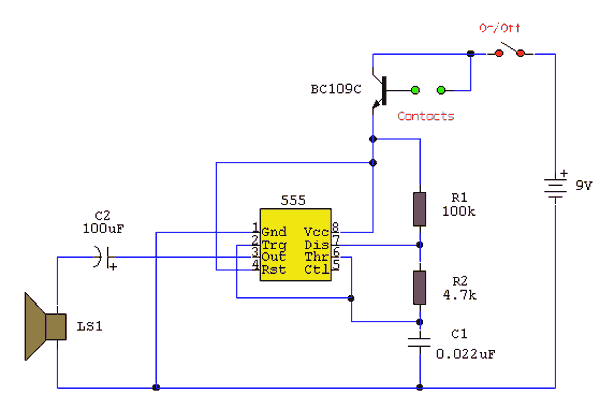
Under dry conditions, the transistor will not have any bias current and will be completely off. However, when the probes become wet, the transistor will conduct, triggering the alarm. An On/Off switch is included, and it is important to use...
The inverter circuit diagram composed of NE555
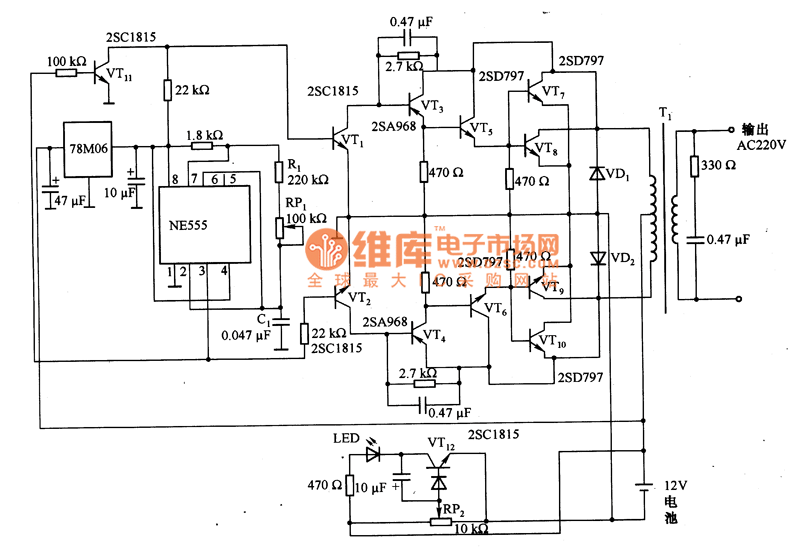
The inverter circuit diagram utilizing the NE555 timer is illustrated, designed to convert a +12V DC battery voltage into a 220V AC output voltage. In this circuit, the NE555 functions as an oscillator, with the oscillation frequency determined by resistors...
Noise making circuits
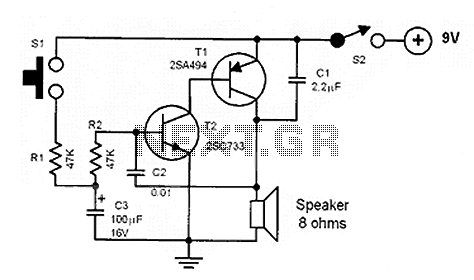
The core of the circuit is a two-transistor flasher with frequency modulation applied to the base of the first transistor. When the pushbutton is pressed, the oscillation frequency increases to a peak, and upon release, the frequency decreases due to...
Seven blinker circuits
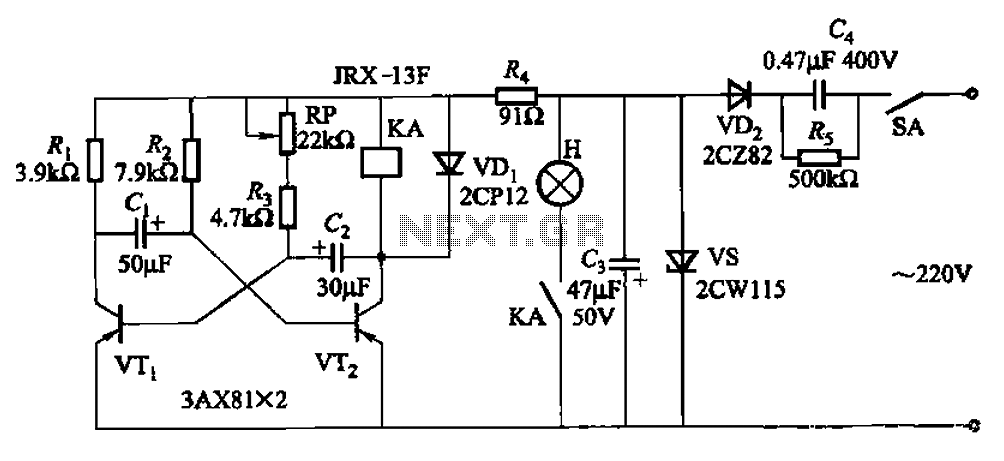
The circuit features a self-excited multivibrator composed of transistors VTi and VTZ. It includes an adjustment potentiometer RP and two RC networks that influence the transistors' parameters, specifically the timing for light activation and deactivation.
The described multivibrator circuit utilizes two...
Common emitter amplifier circuit resistance and capacitance coupled basic
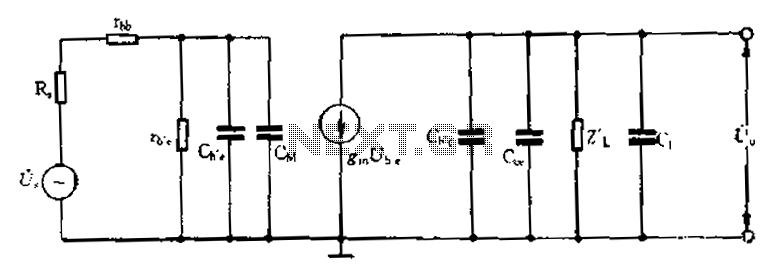
Common emitter amplifier circuit with resistance and capacitance coupling.
The common emitter amplifier circuit is a fundamental configuration in analog electronics, widely utilized for its ability to amplify voltage signals. This circuit employs a bipolar junction transistor (BJT) as the active...
NE555 Timer
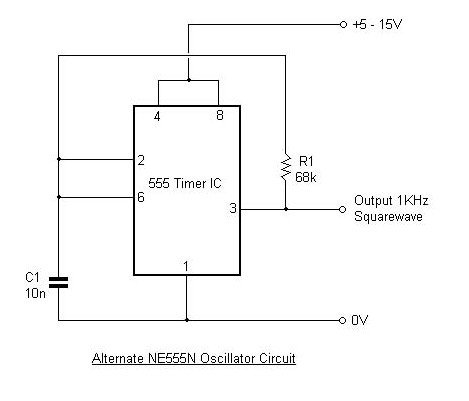
This article outlines the design and applications of the NE555 timer. The content is straightforward and informative, providing valuable insights into various components associated with the NE555. Readers can find and purchase these components through the article. It discusses several...
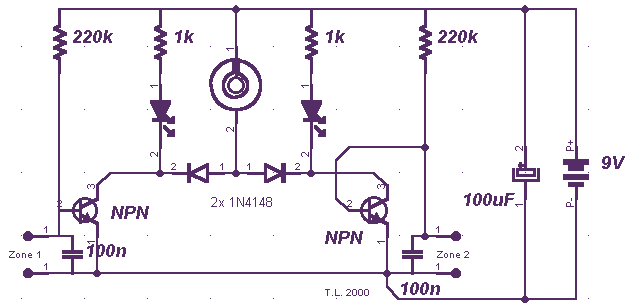
Miniature Loop Alarm
Simple construction, reliable operation, very small power consumption, and, most of all, small size. I started with CMOS logic gates, but was soon forced to abandon the concept after a few unsuccessful (and far too complicated) attempts. Then I suddenly...
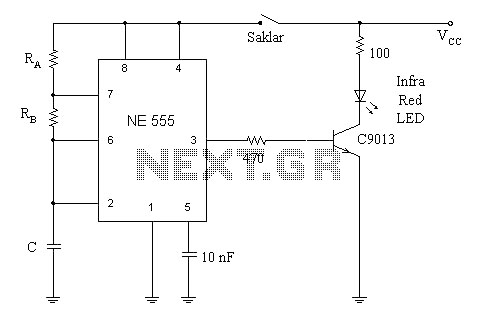
remote control using the ne 555 and lm 567
A simple circuit diagram illustrates a schematic for a remote control system, which consists of two components: a transmitter and a receiver. The transmitter circuit is controlled by the NE555 integrated circuit (IC). This system operates by detecting the emitted...
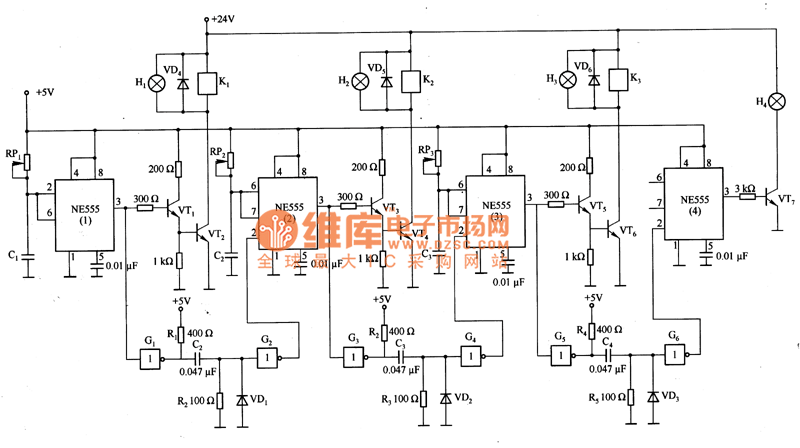
Sequence timer diagram composed by NE555
This is a sequence timer diagram composed of an NE555 timer. The timer can be set to any duration when the power is connected, allowing it to control an external system. In the circuit, K1-K3 are relays used to activate...